One supported sweep.
The body turns over planted feet, carrying the shoulders into one clear sweep. Compare the original reference, the previous rig, and the new body-and-arm performance.
Native rig candidate · owner adoption pendingLinked playback aligns time for inspection. The front reference guides the action; it is not a recovered 3D skeleton. Reference and middle comparison stay in front view. The optional central-reference test keeps the same local arm and head action as the new rig, changing only the body reference point.
Body carried by the feet
The trunk turns as a common frame. Smooth lower sections connect that movement to two fixed paw contacts, without the previous large chest-versus-pelvis twist.
A complete arm-and-tool action
The shoulder swings the original arm inward at unchanged length. The actual hand holds the broom while its floor contact is solved through the sweep and return.
A calmer head and return
The rigid head attends to the work and gently levels itself. A gradual work-end recovery keeps the active gesture moving before it settles.
Seven event poses · four views
Top: central-reference test. Bottom: chosen contact-reference rig. Open each sheet at full size.
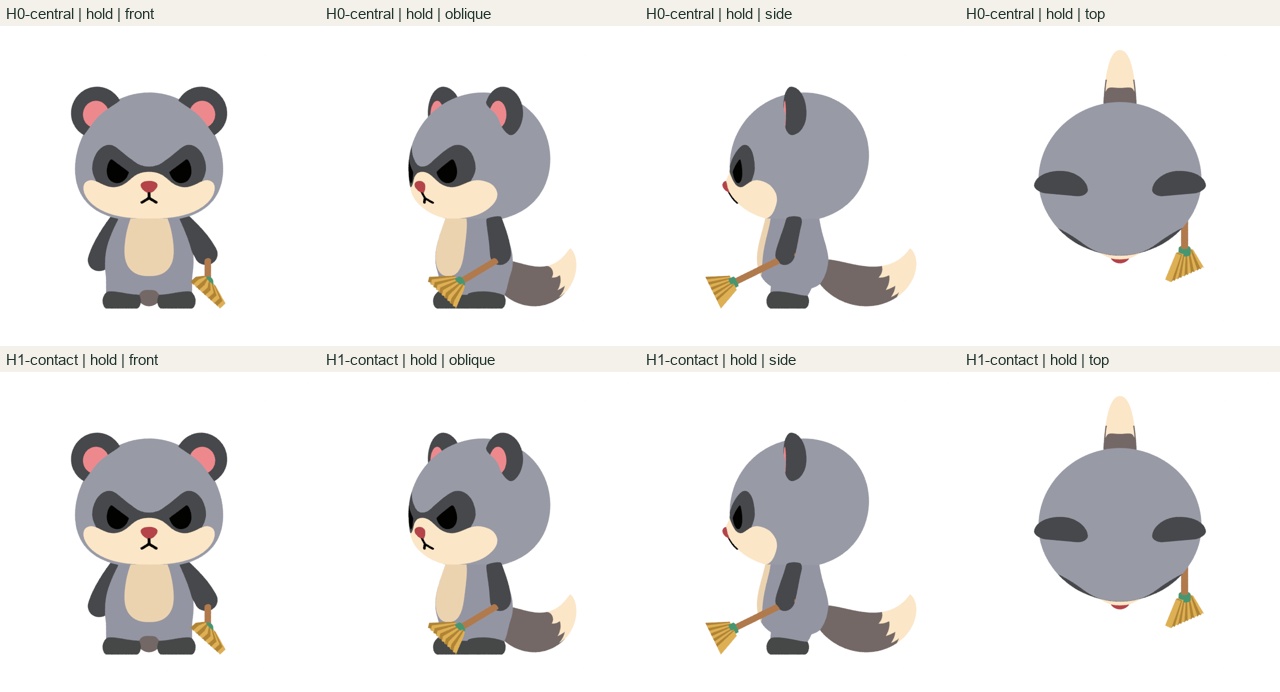 Central/contact · hold
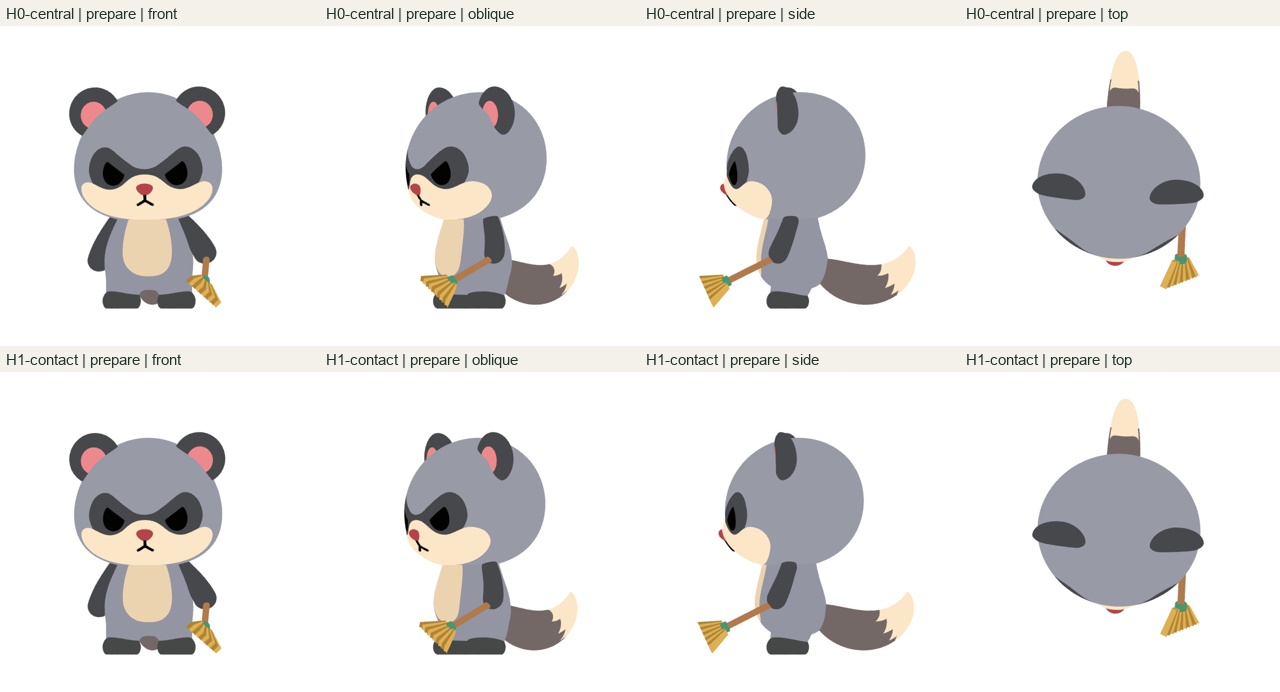 Central/contact · prepare
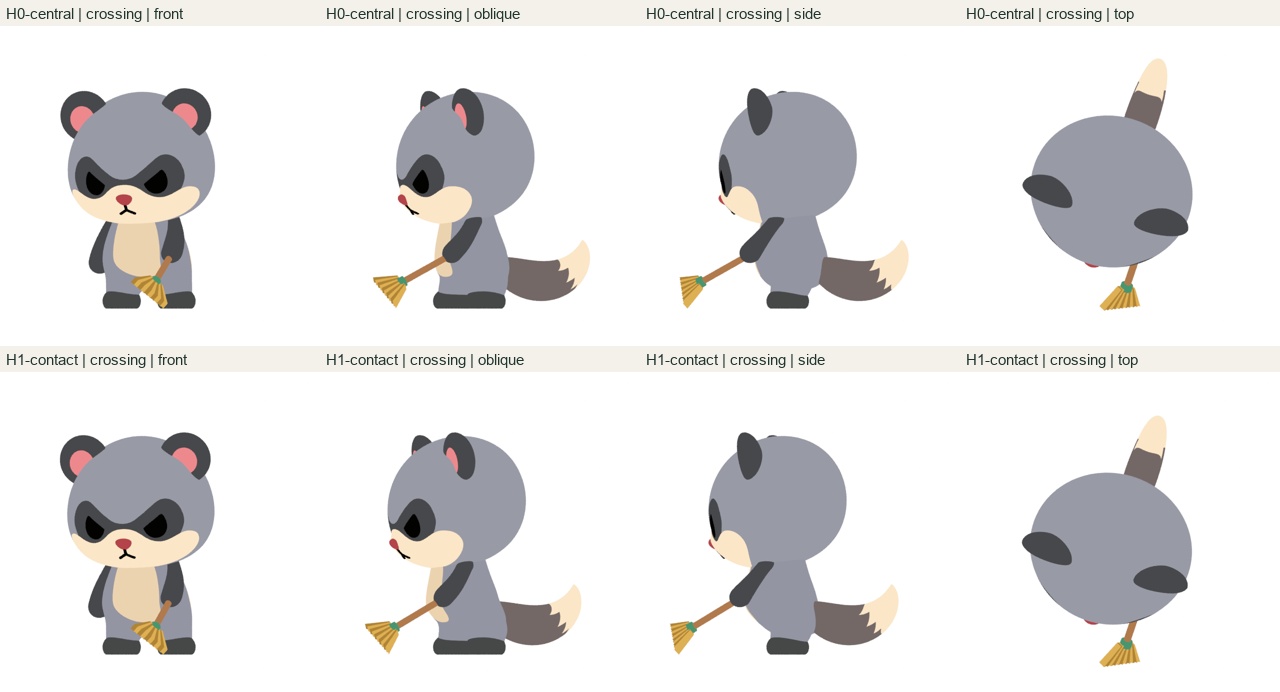 Central/contact · crossing
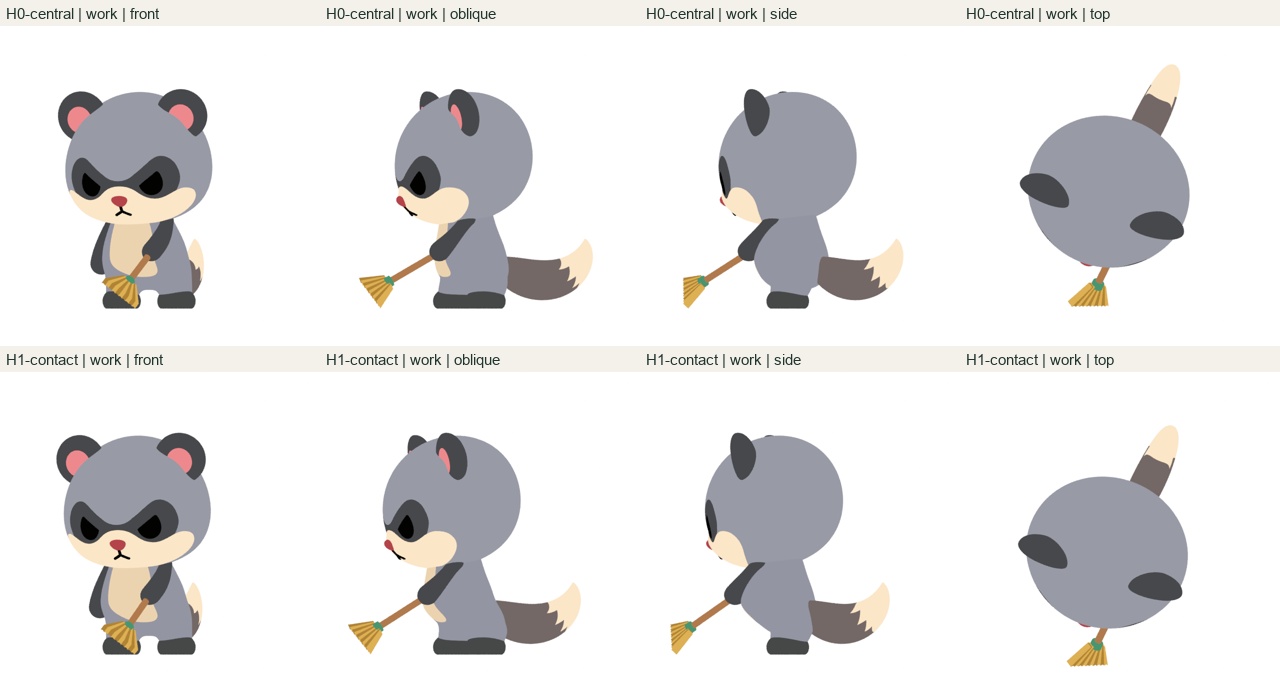 Central/contact · work
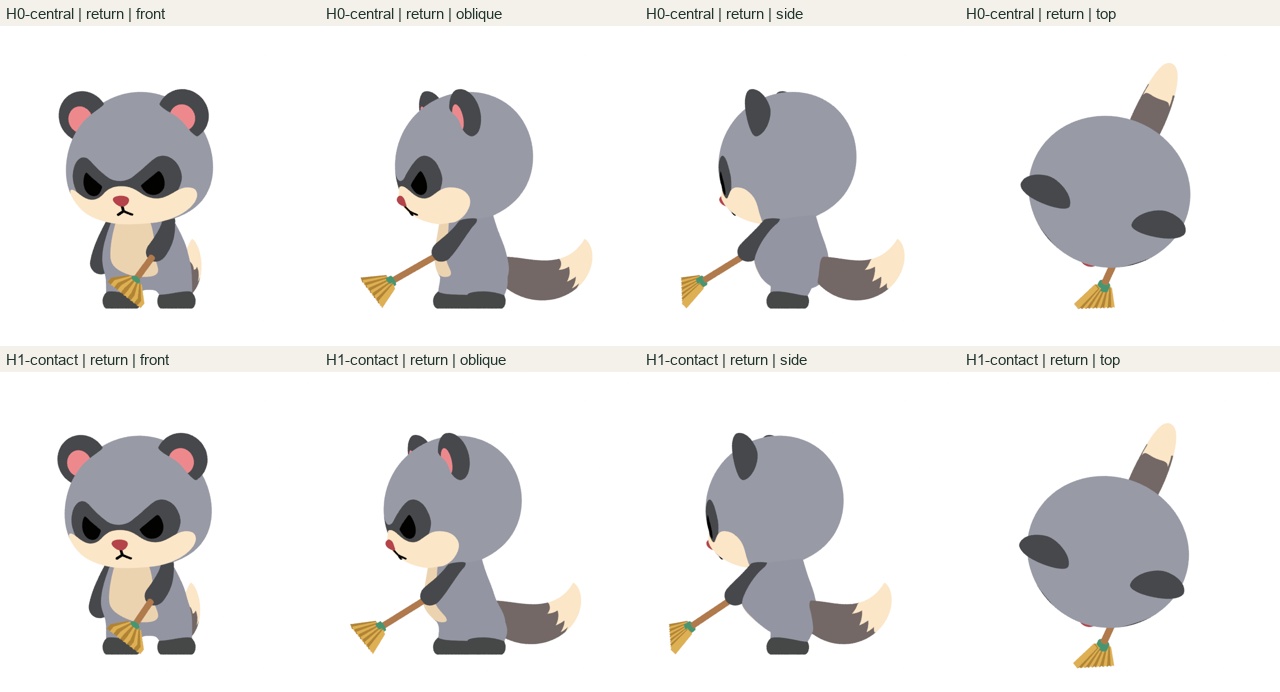 Central/contact · return
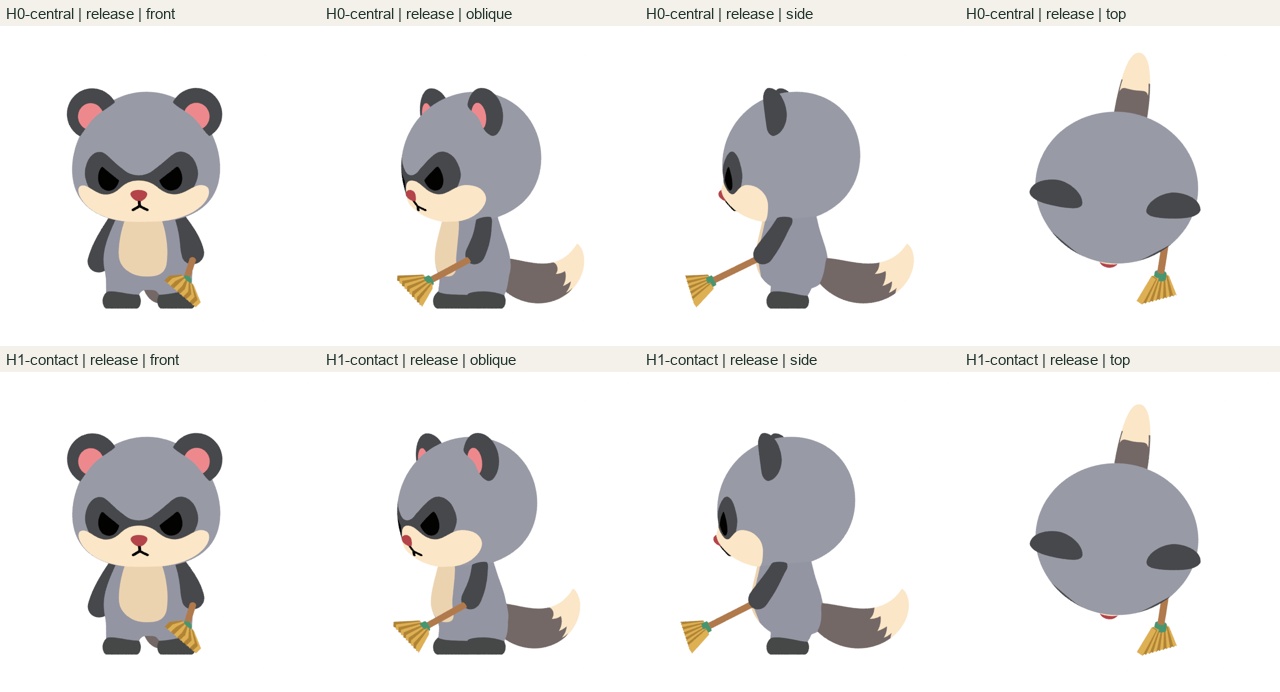 Central/contact · release
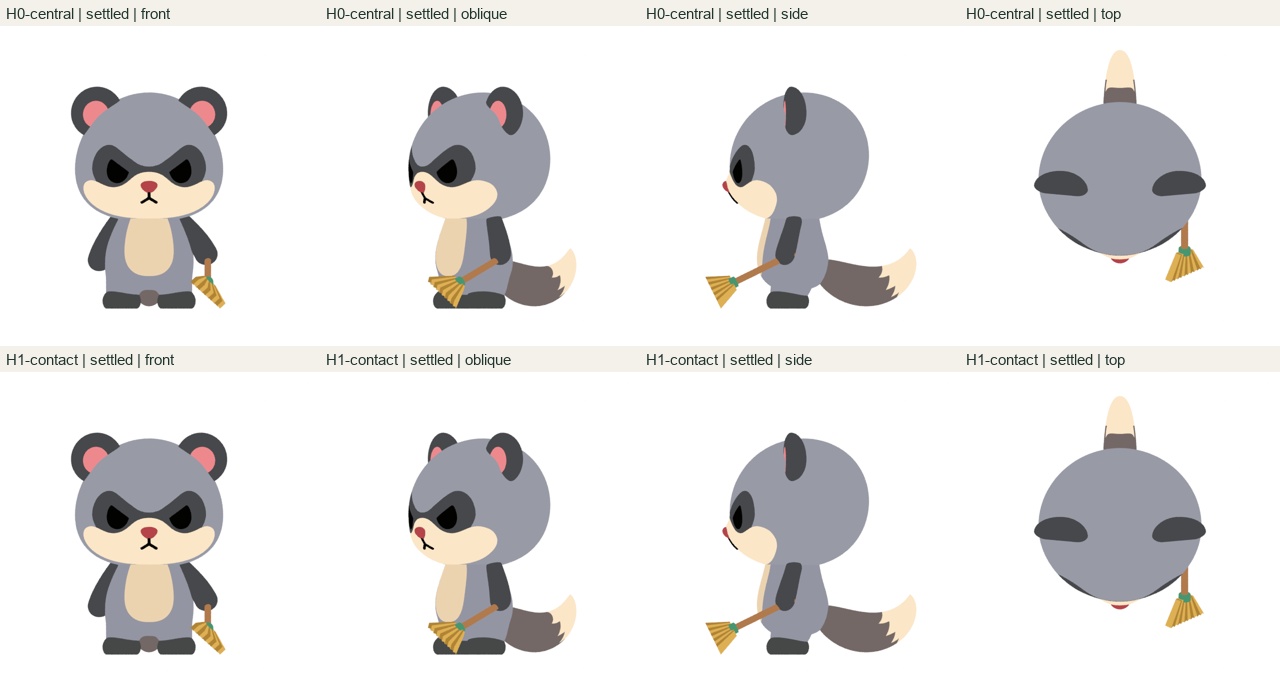 Central/contact · settled
Supported body surfaces
Both reference-point cases at the work pose. These shaded views reveal the body, hips and ankle overlap hidden by the head and arms.
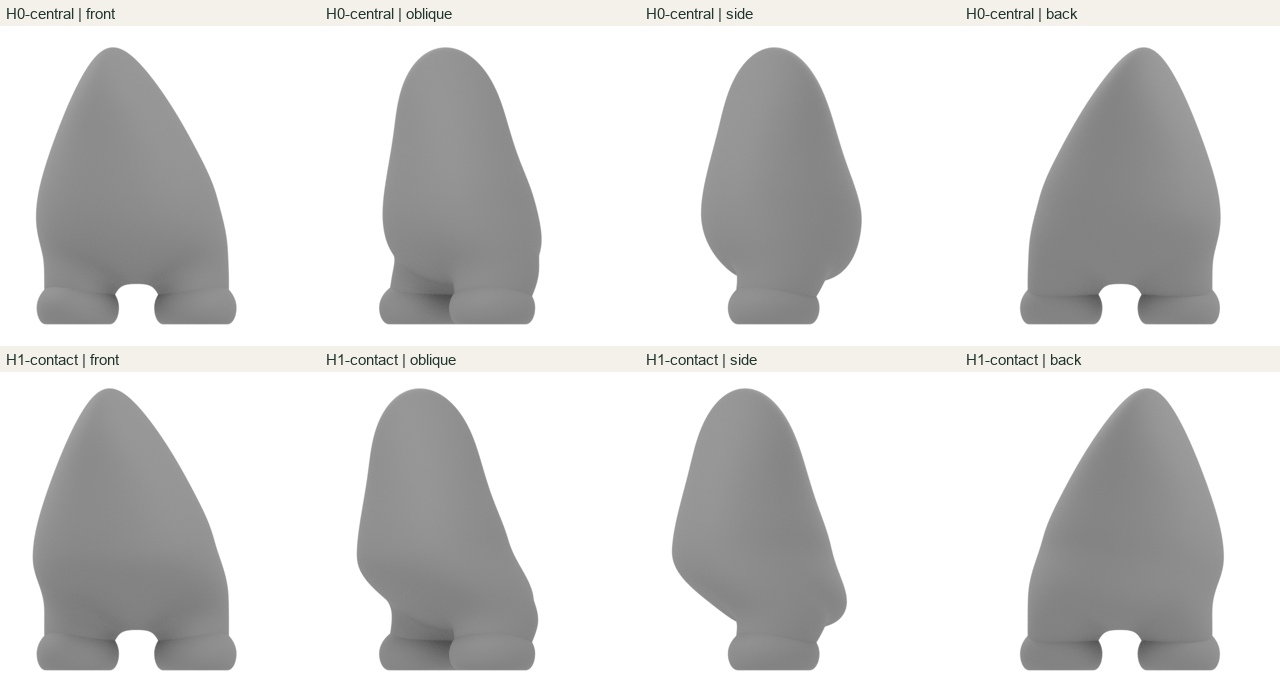 Common-frame support surfaces · four views
The corrected pilot removes the initial local rear-leg bulge. Existing smooth attachment overlap remains. These views describe the authored gesture, not physical contact forces or every possible control setting.
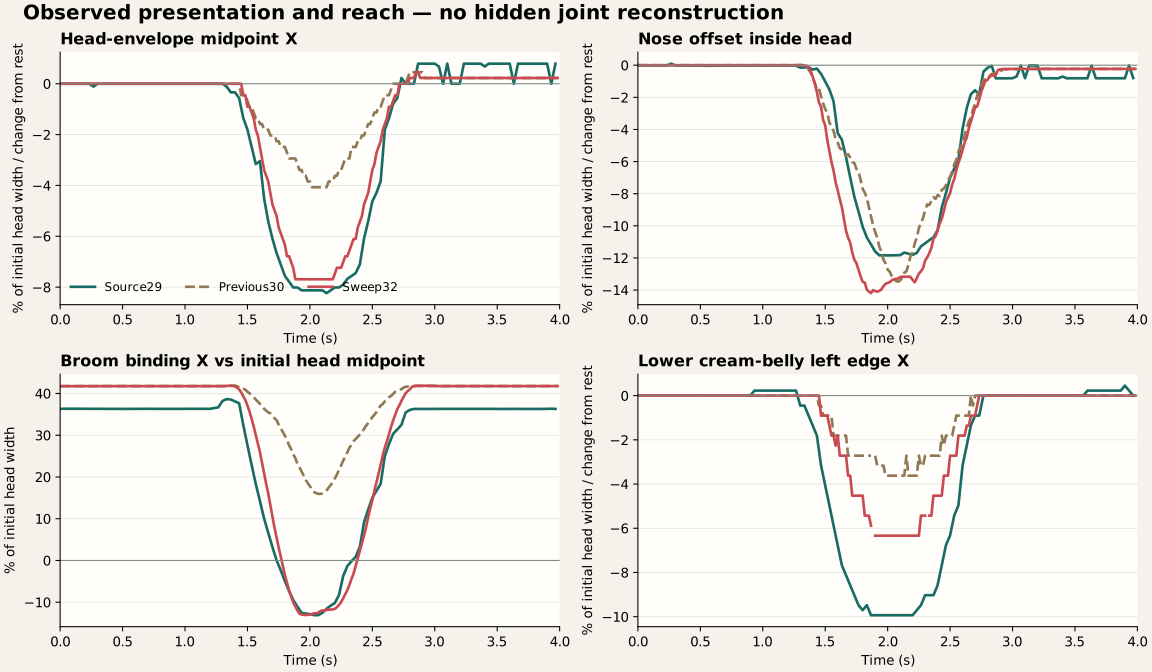
Observed reach and body presentation
Normalized image features compare excursion and timing. They are not recovered joint angles or forces.
Every rendered frame · complete sequence sheets
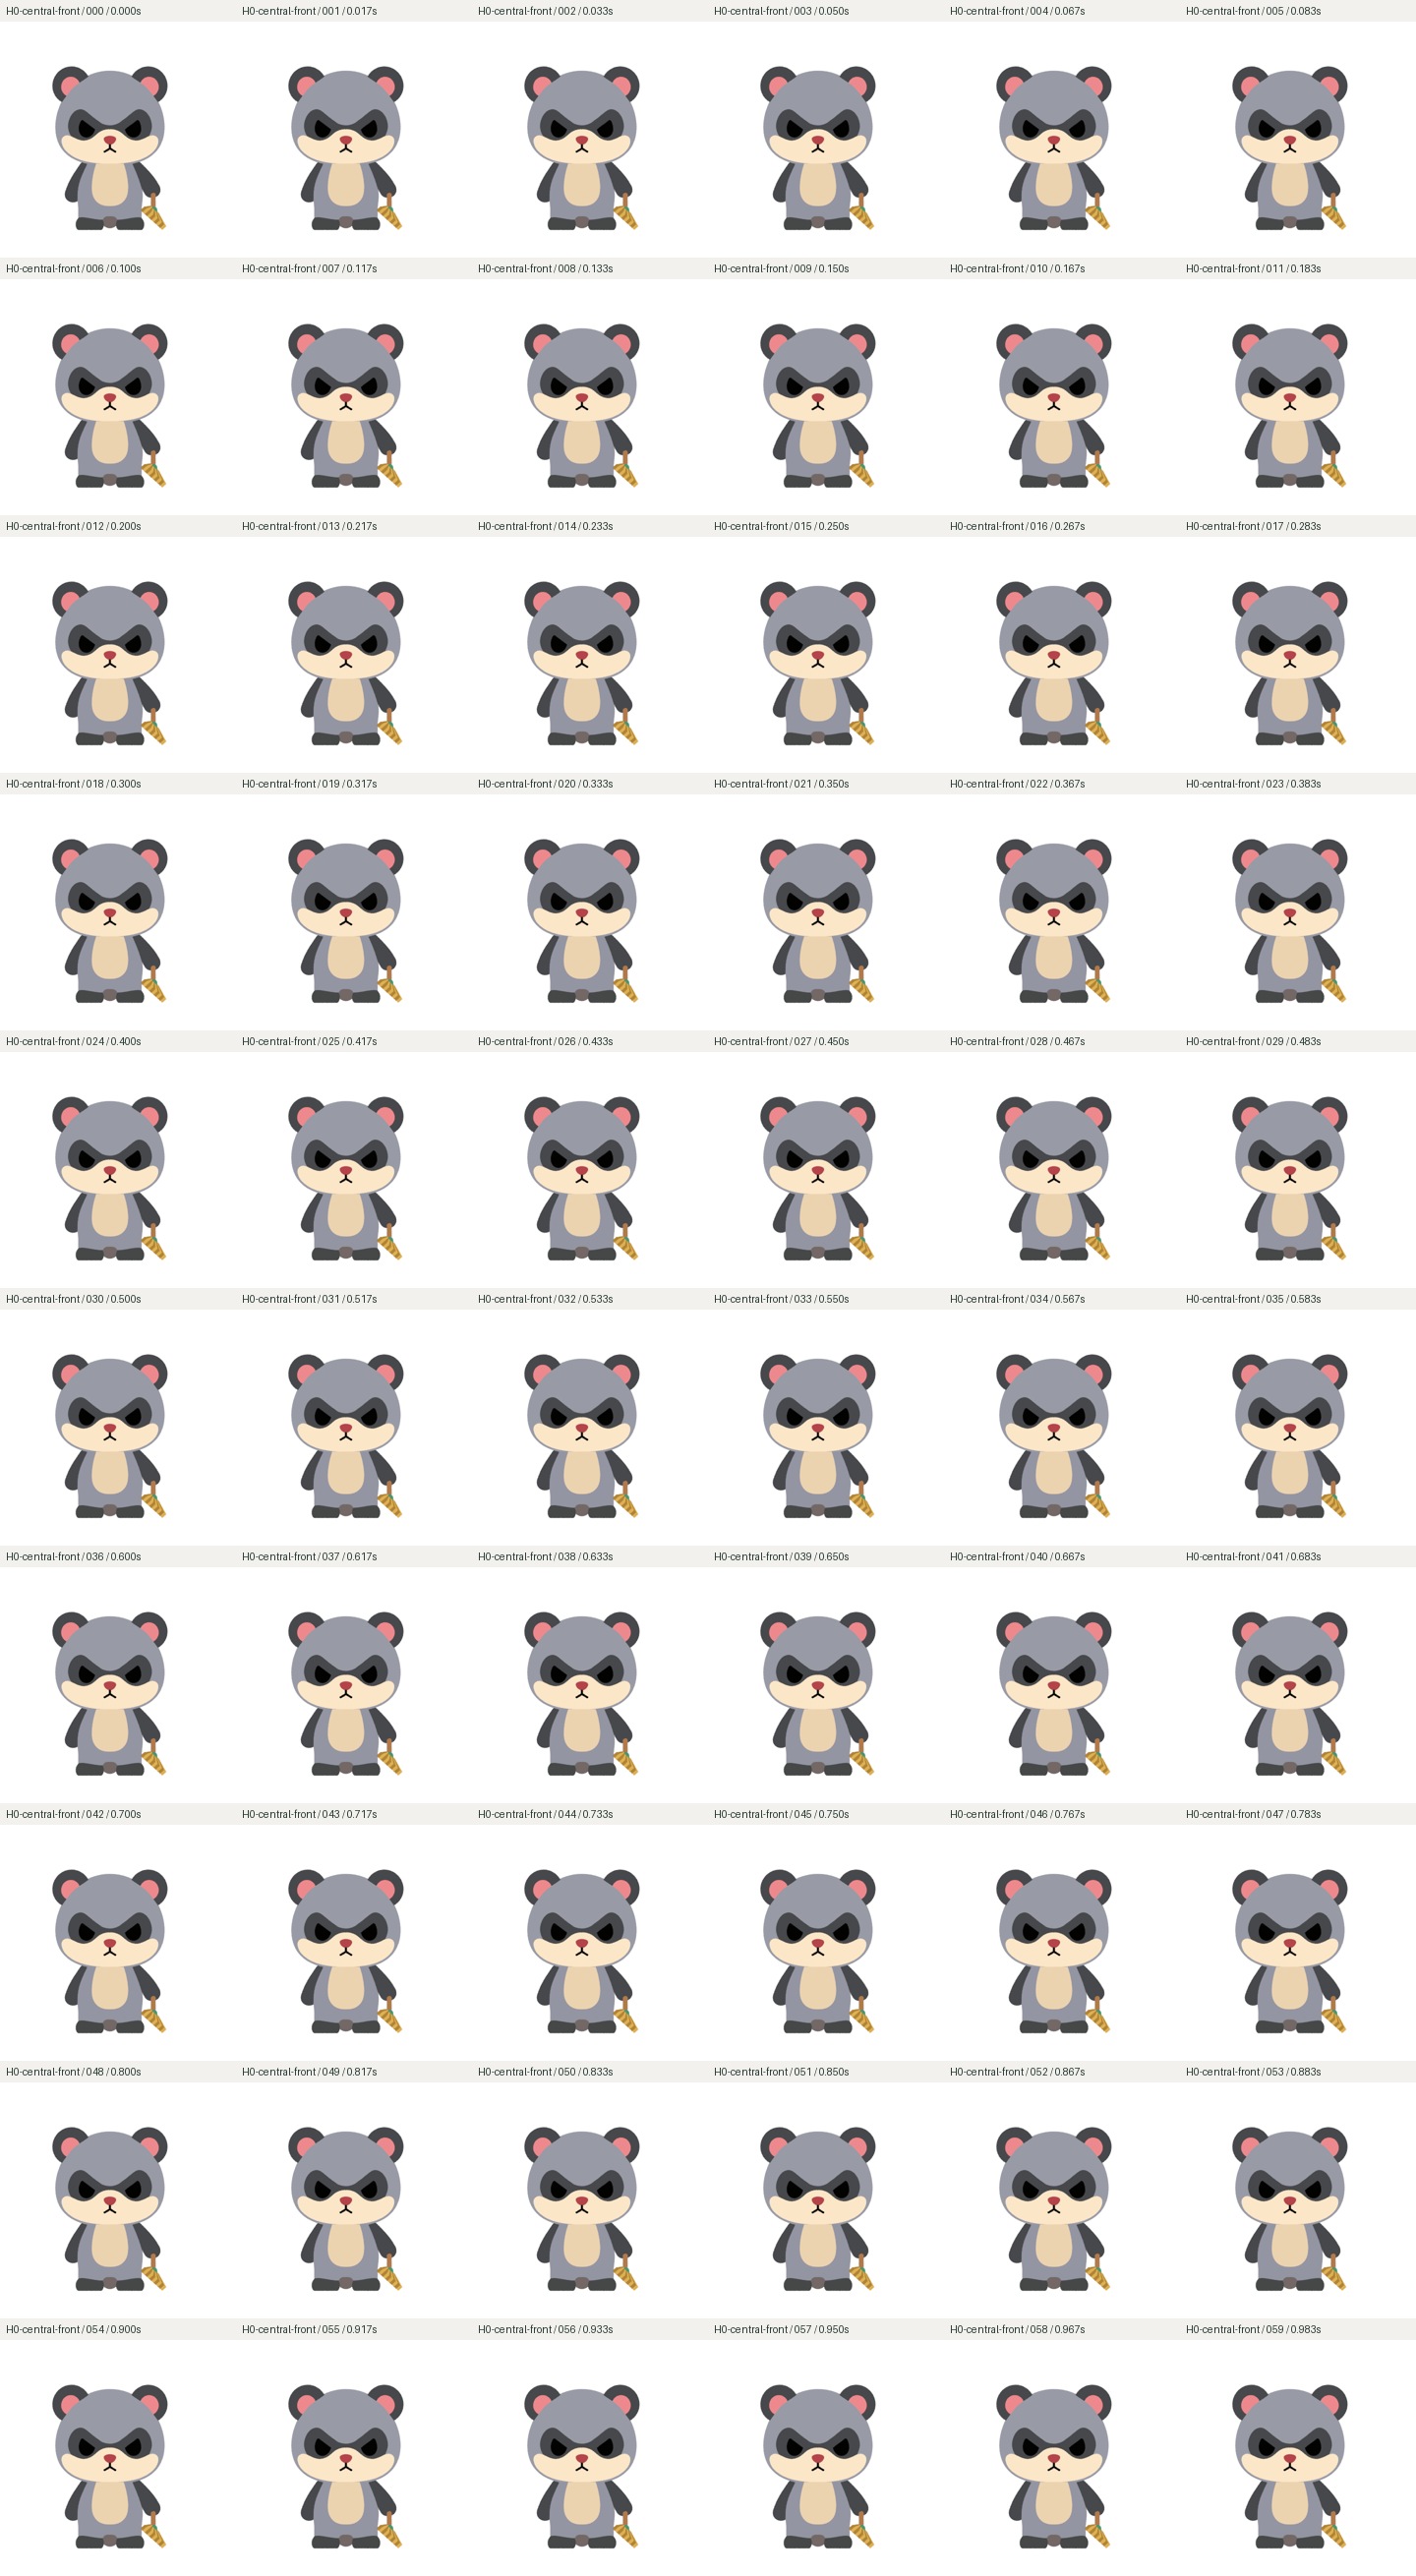 H0-central · front · frames0–59
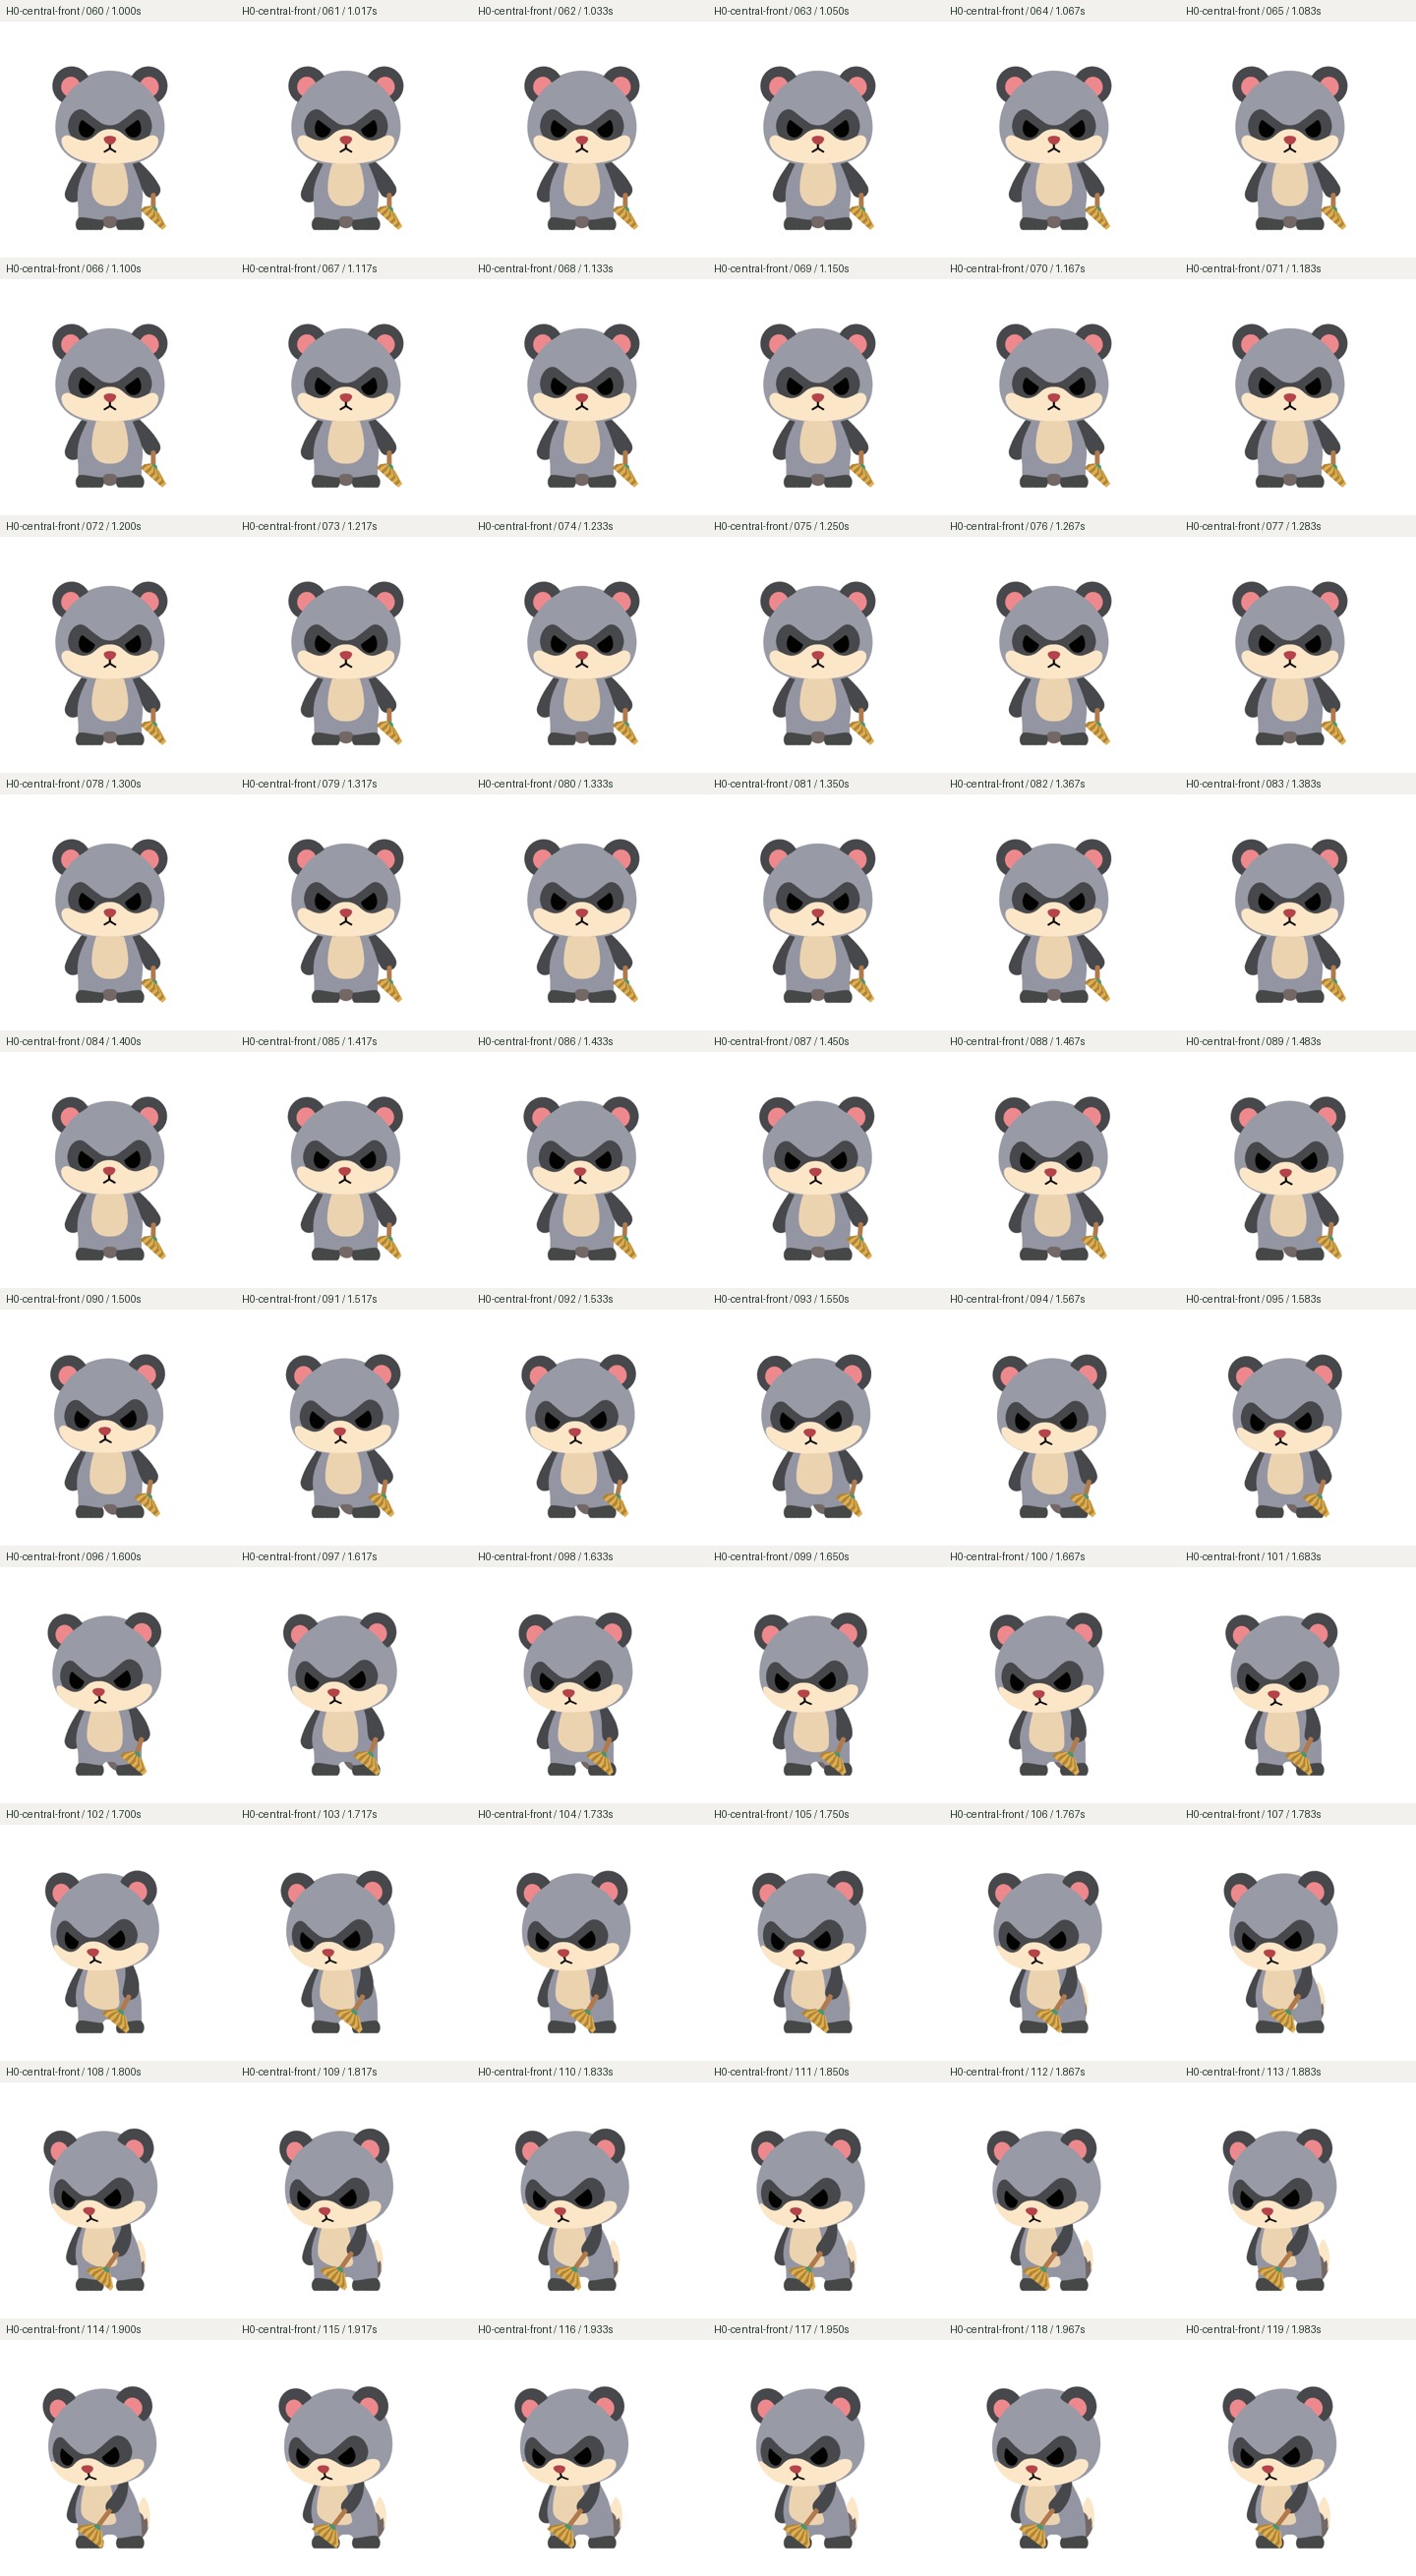 H0-central · front · frames60–119
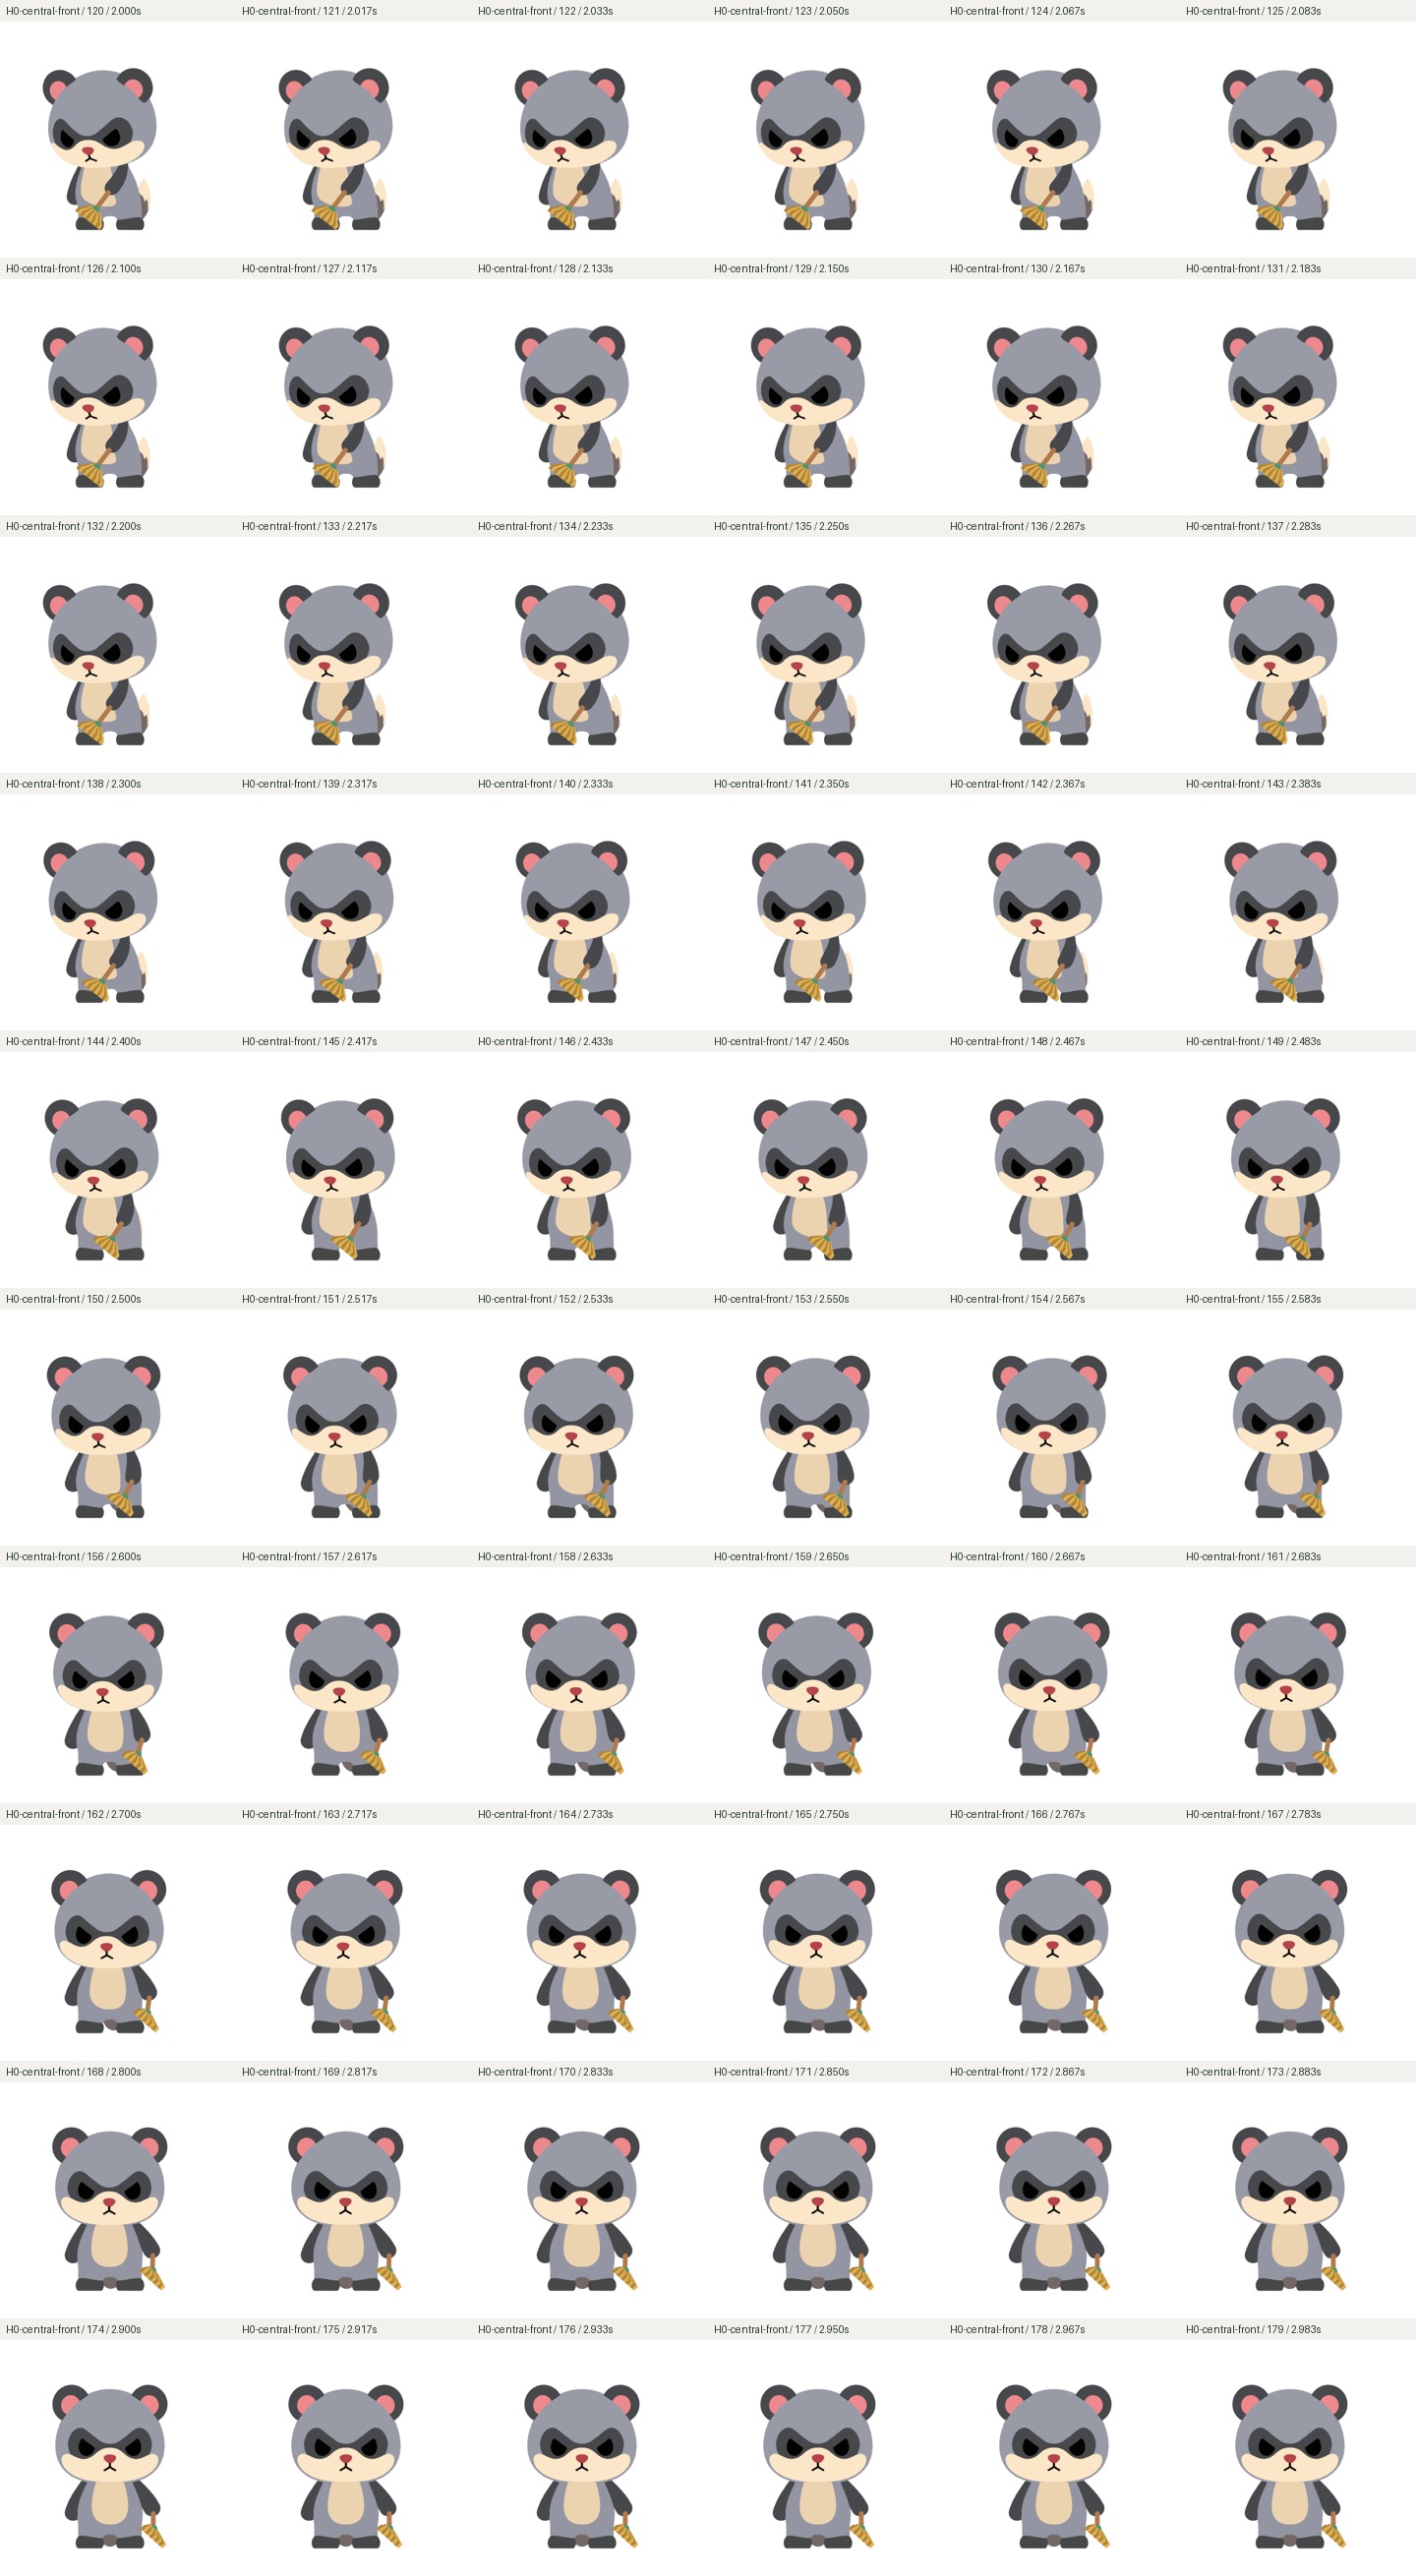 H0-central · front · frames120–179
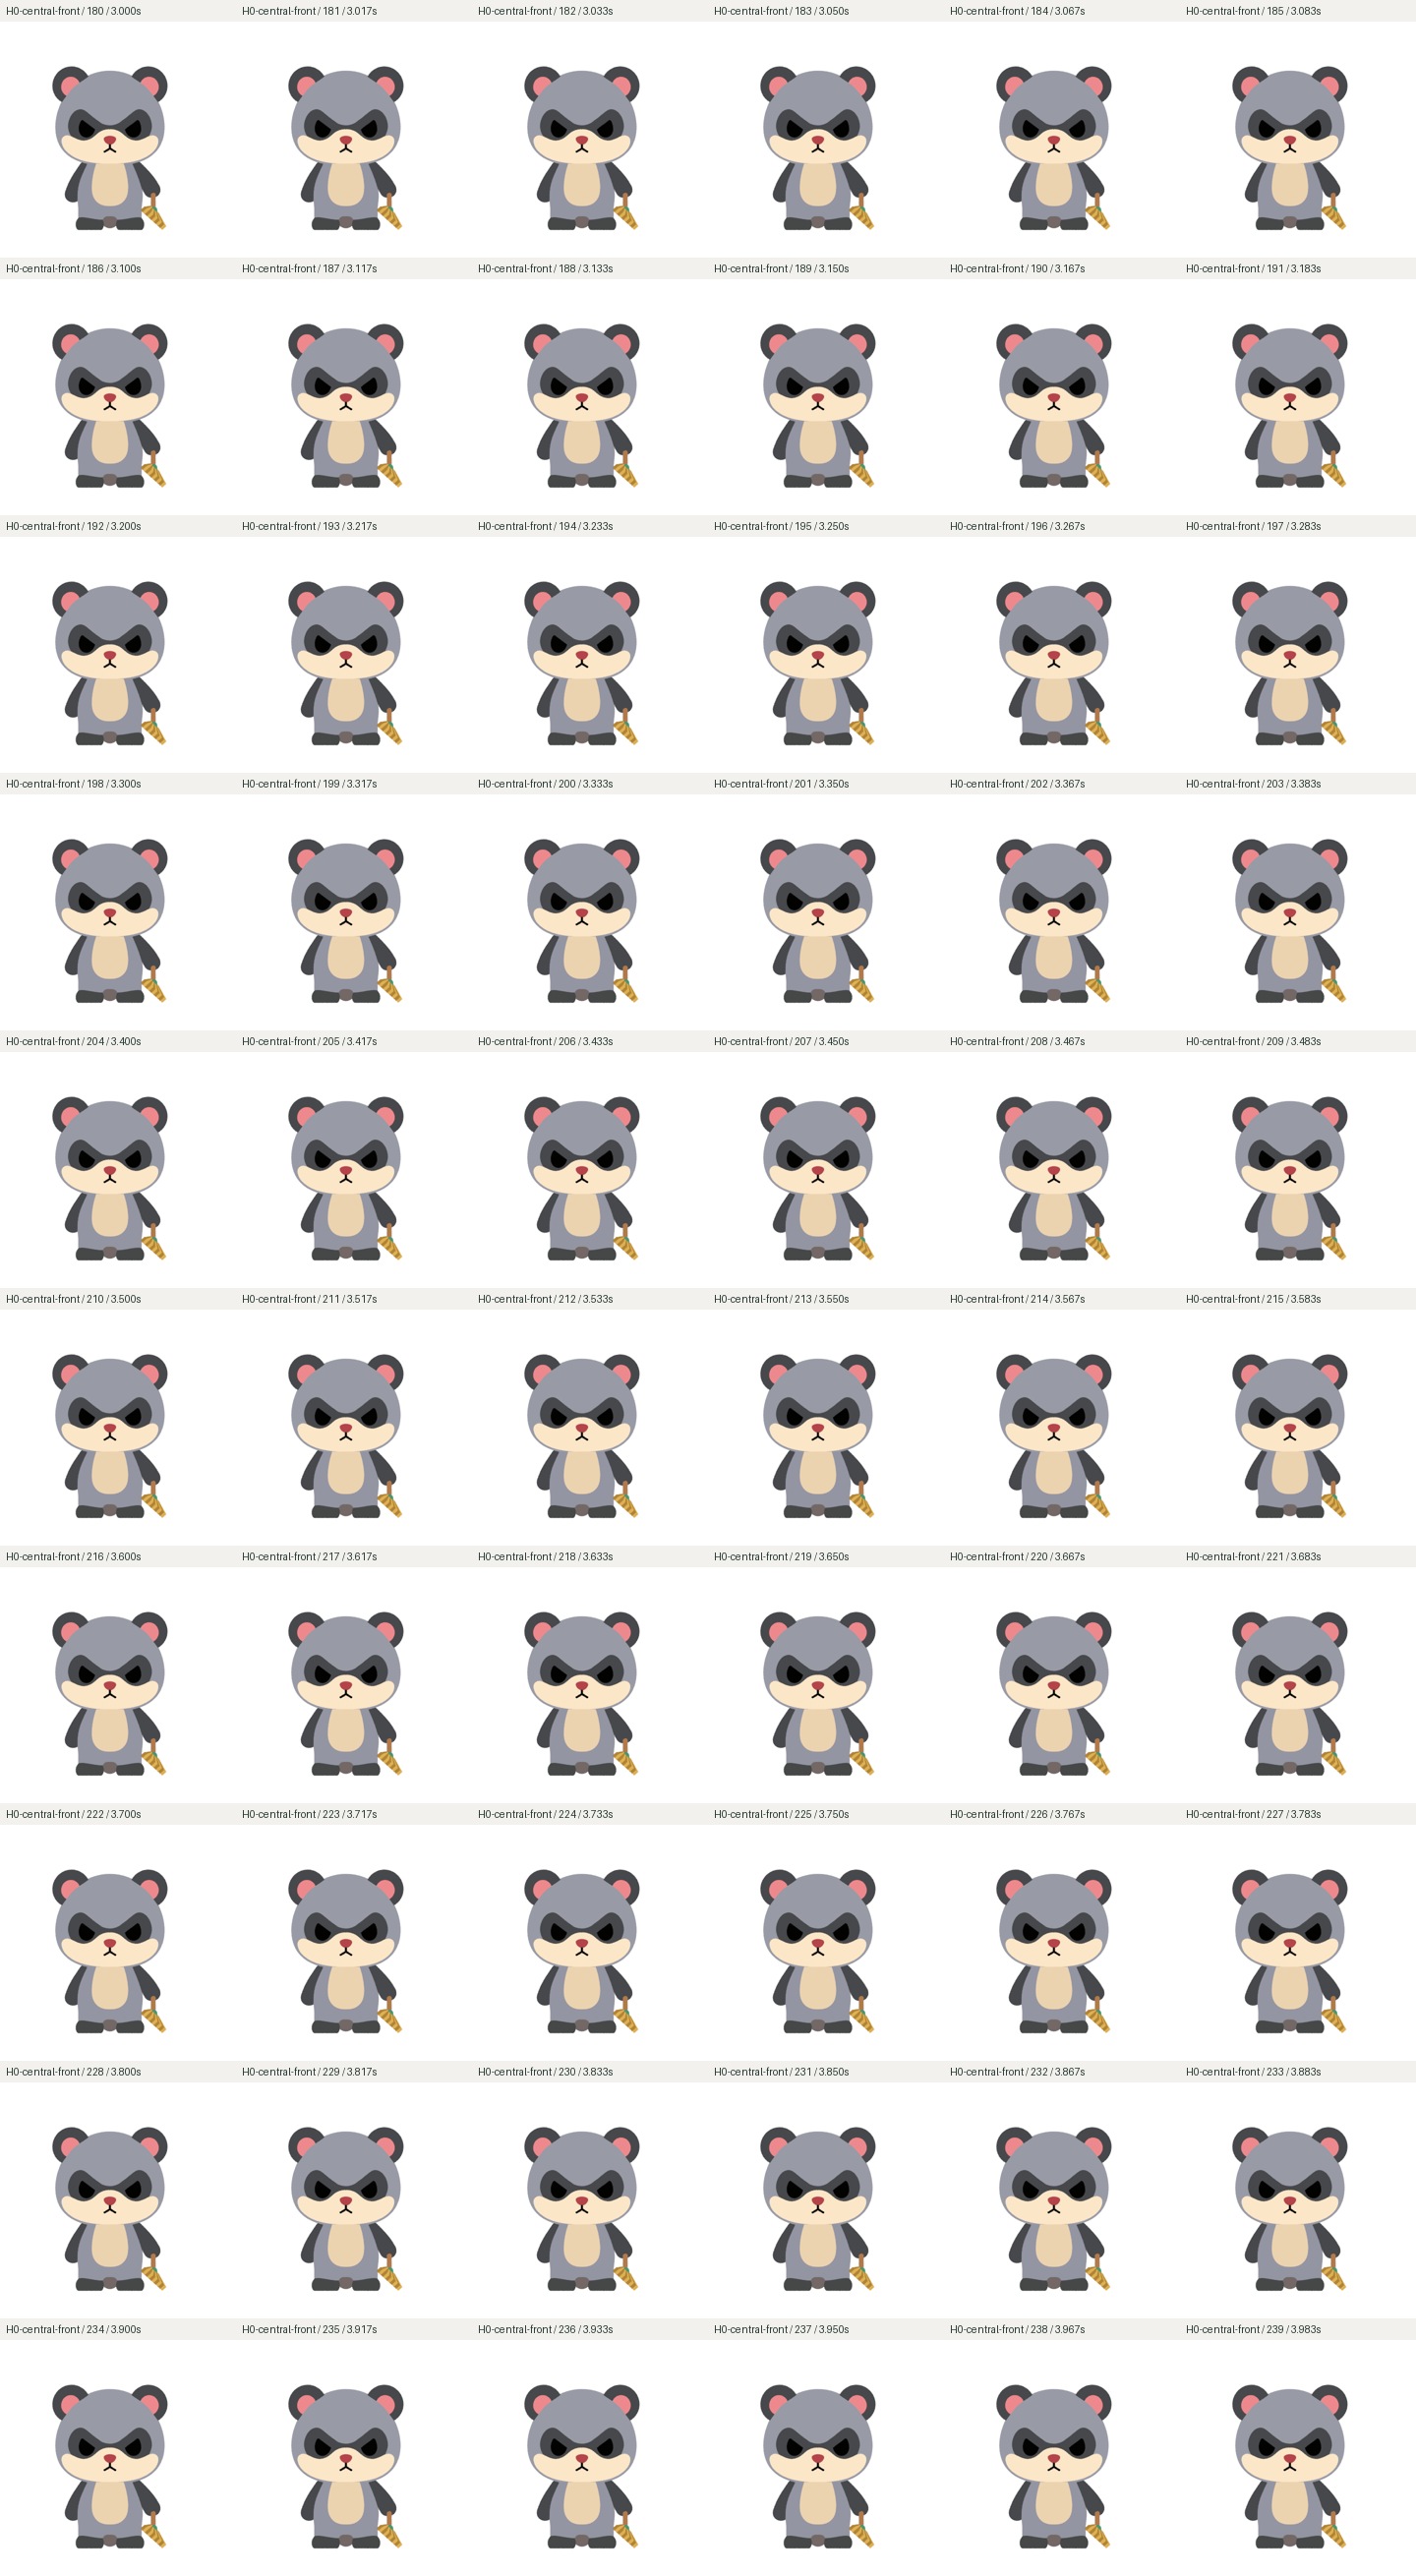 H0-central · front · frames180–239
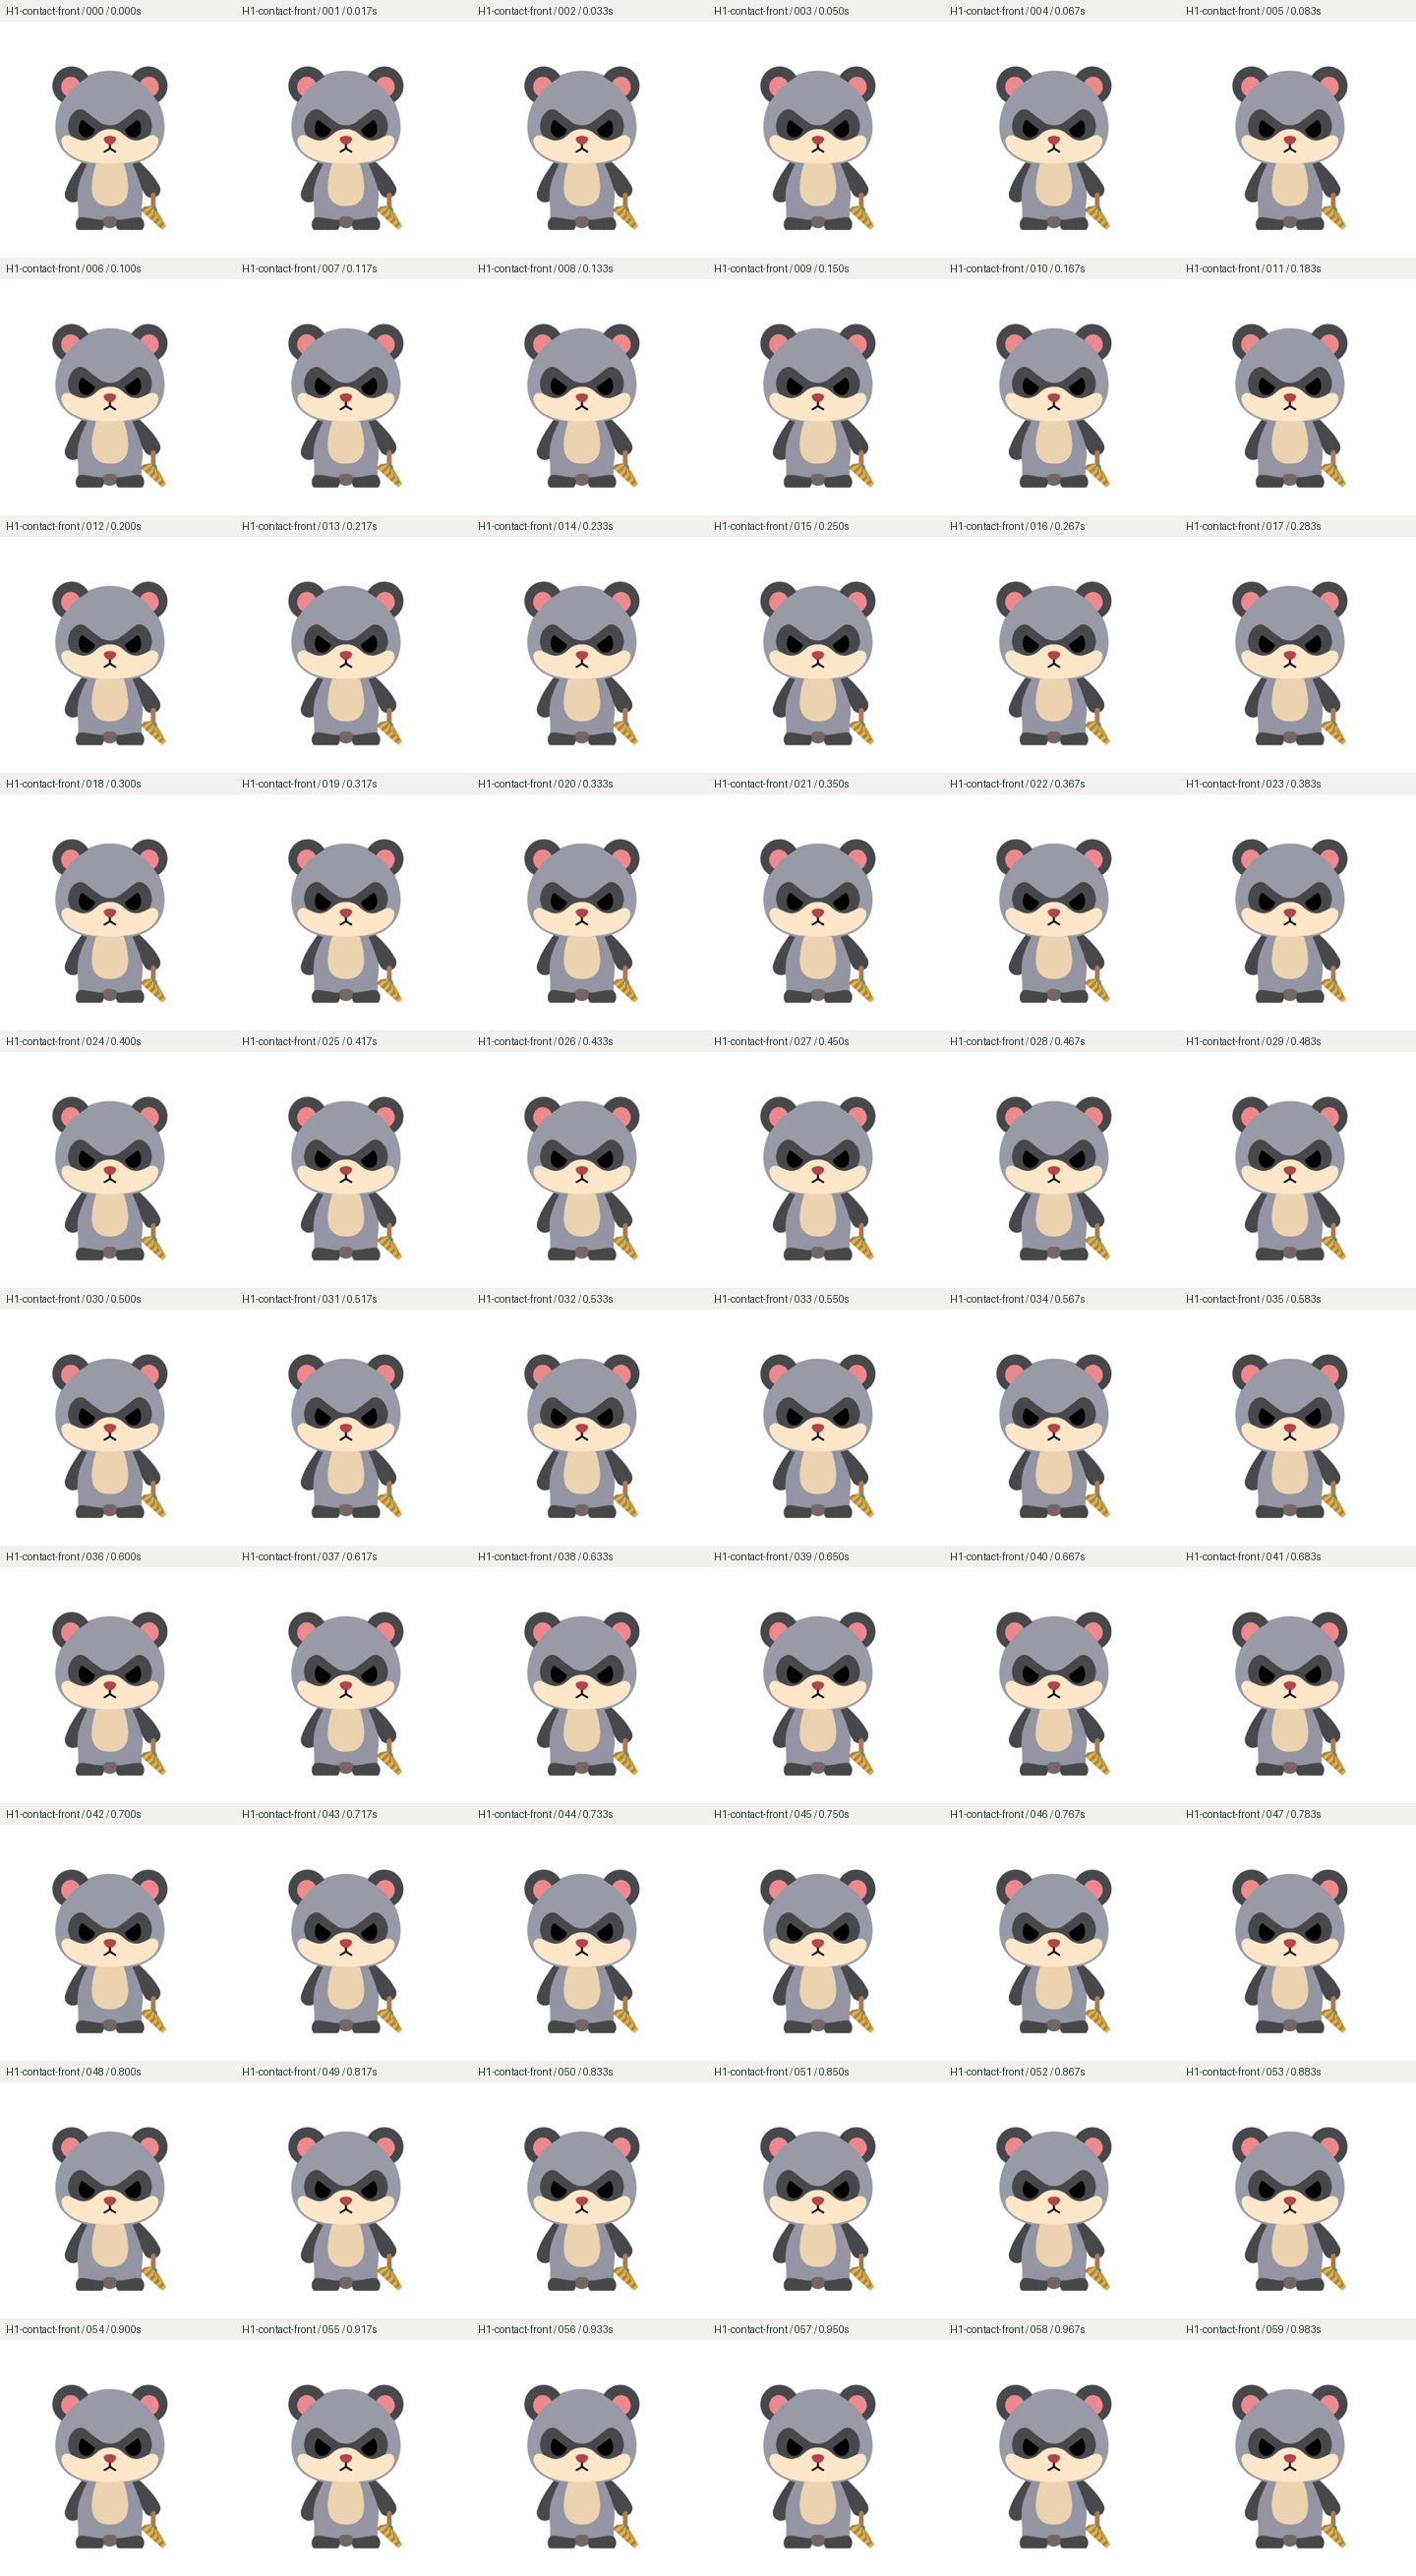 H1-contact · front · frames0–59
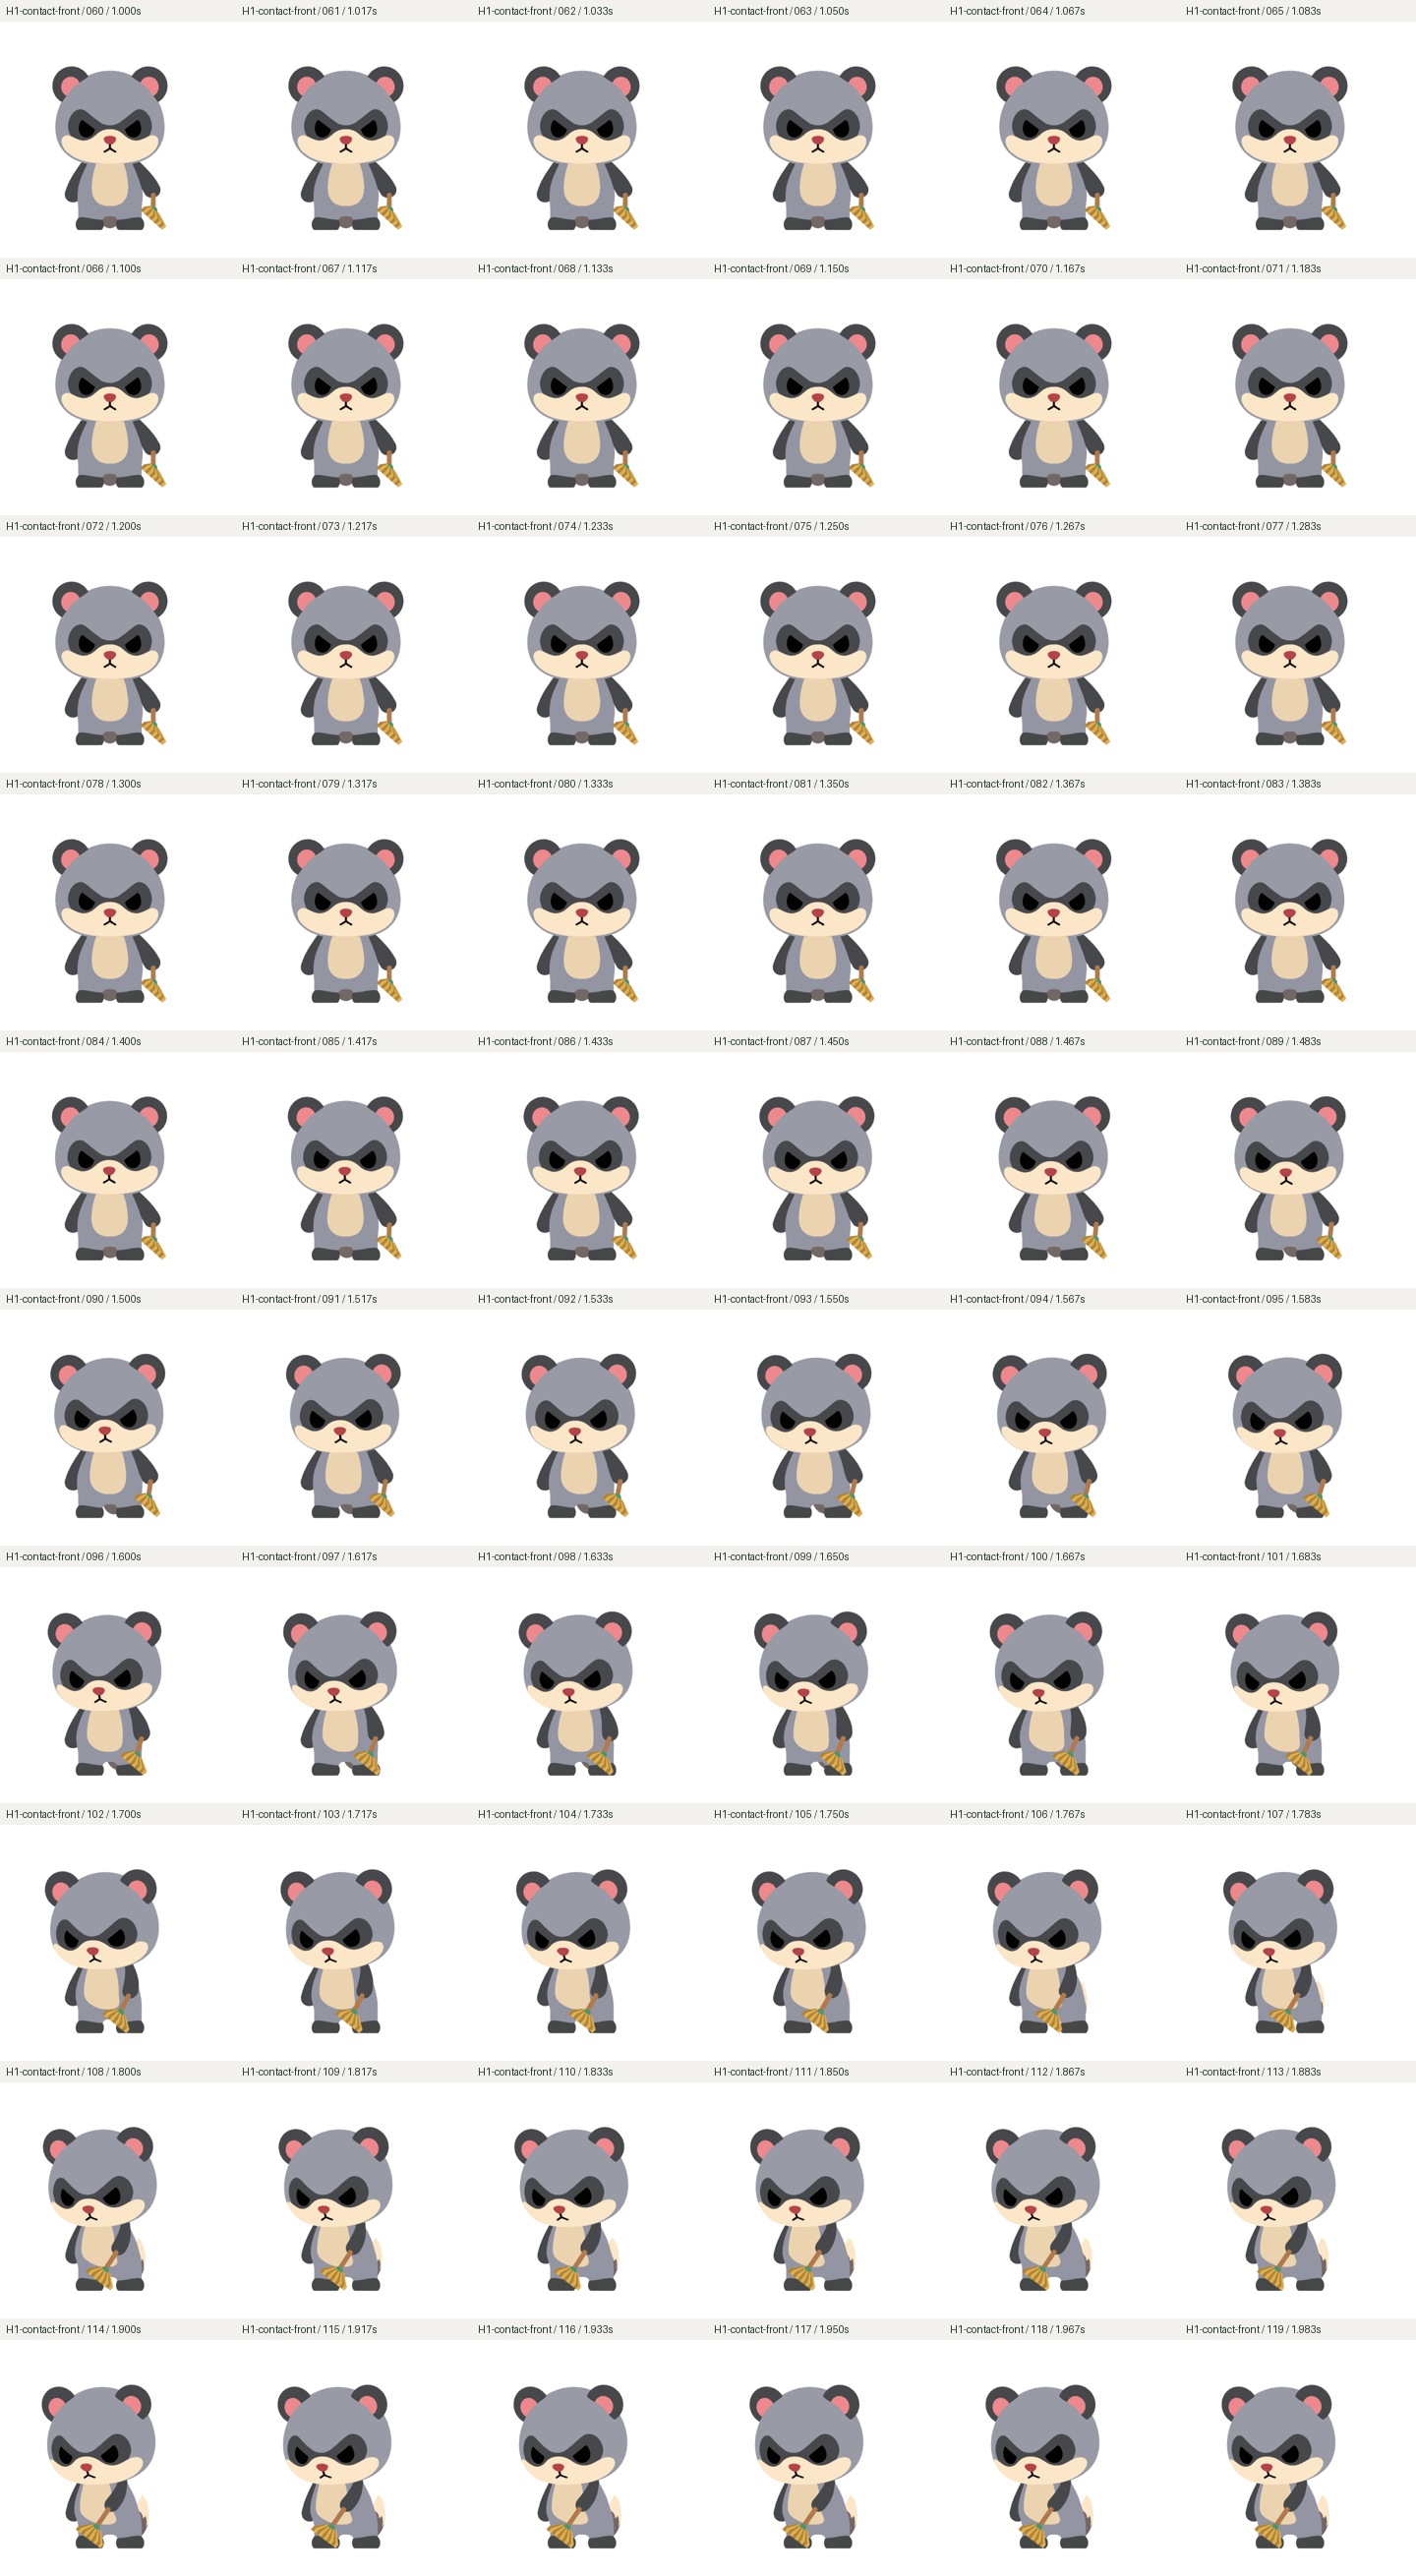 H1-contact · front · frames60–119
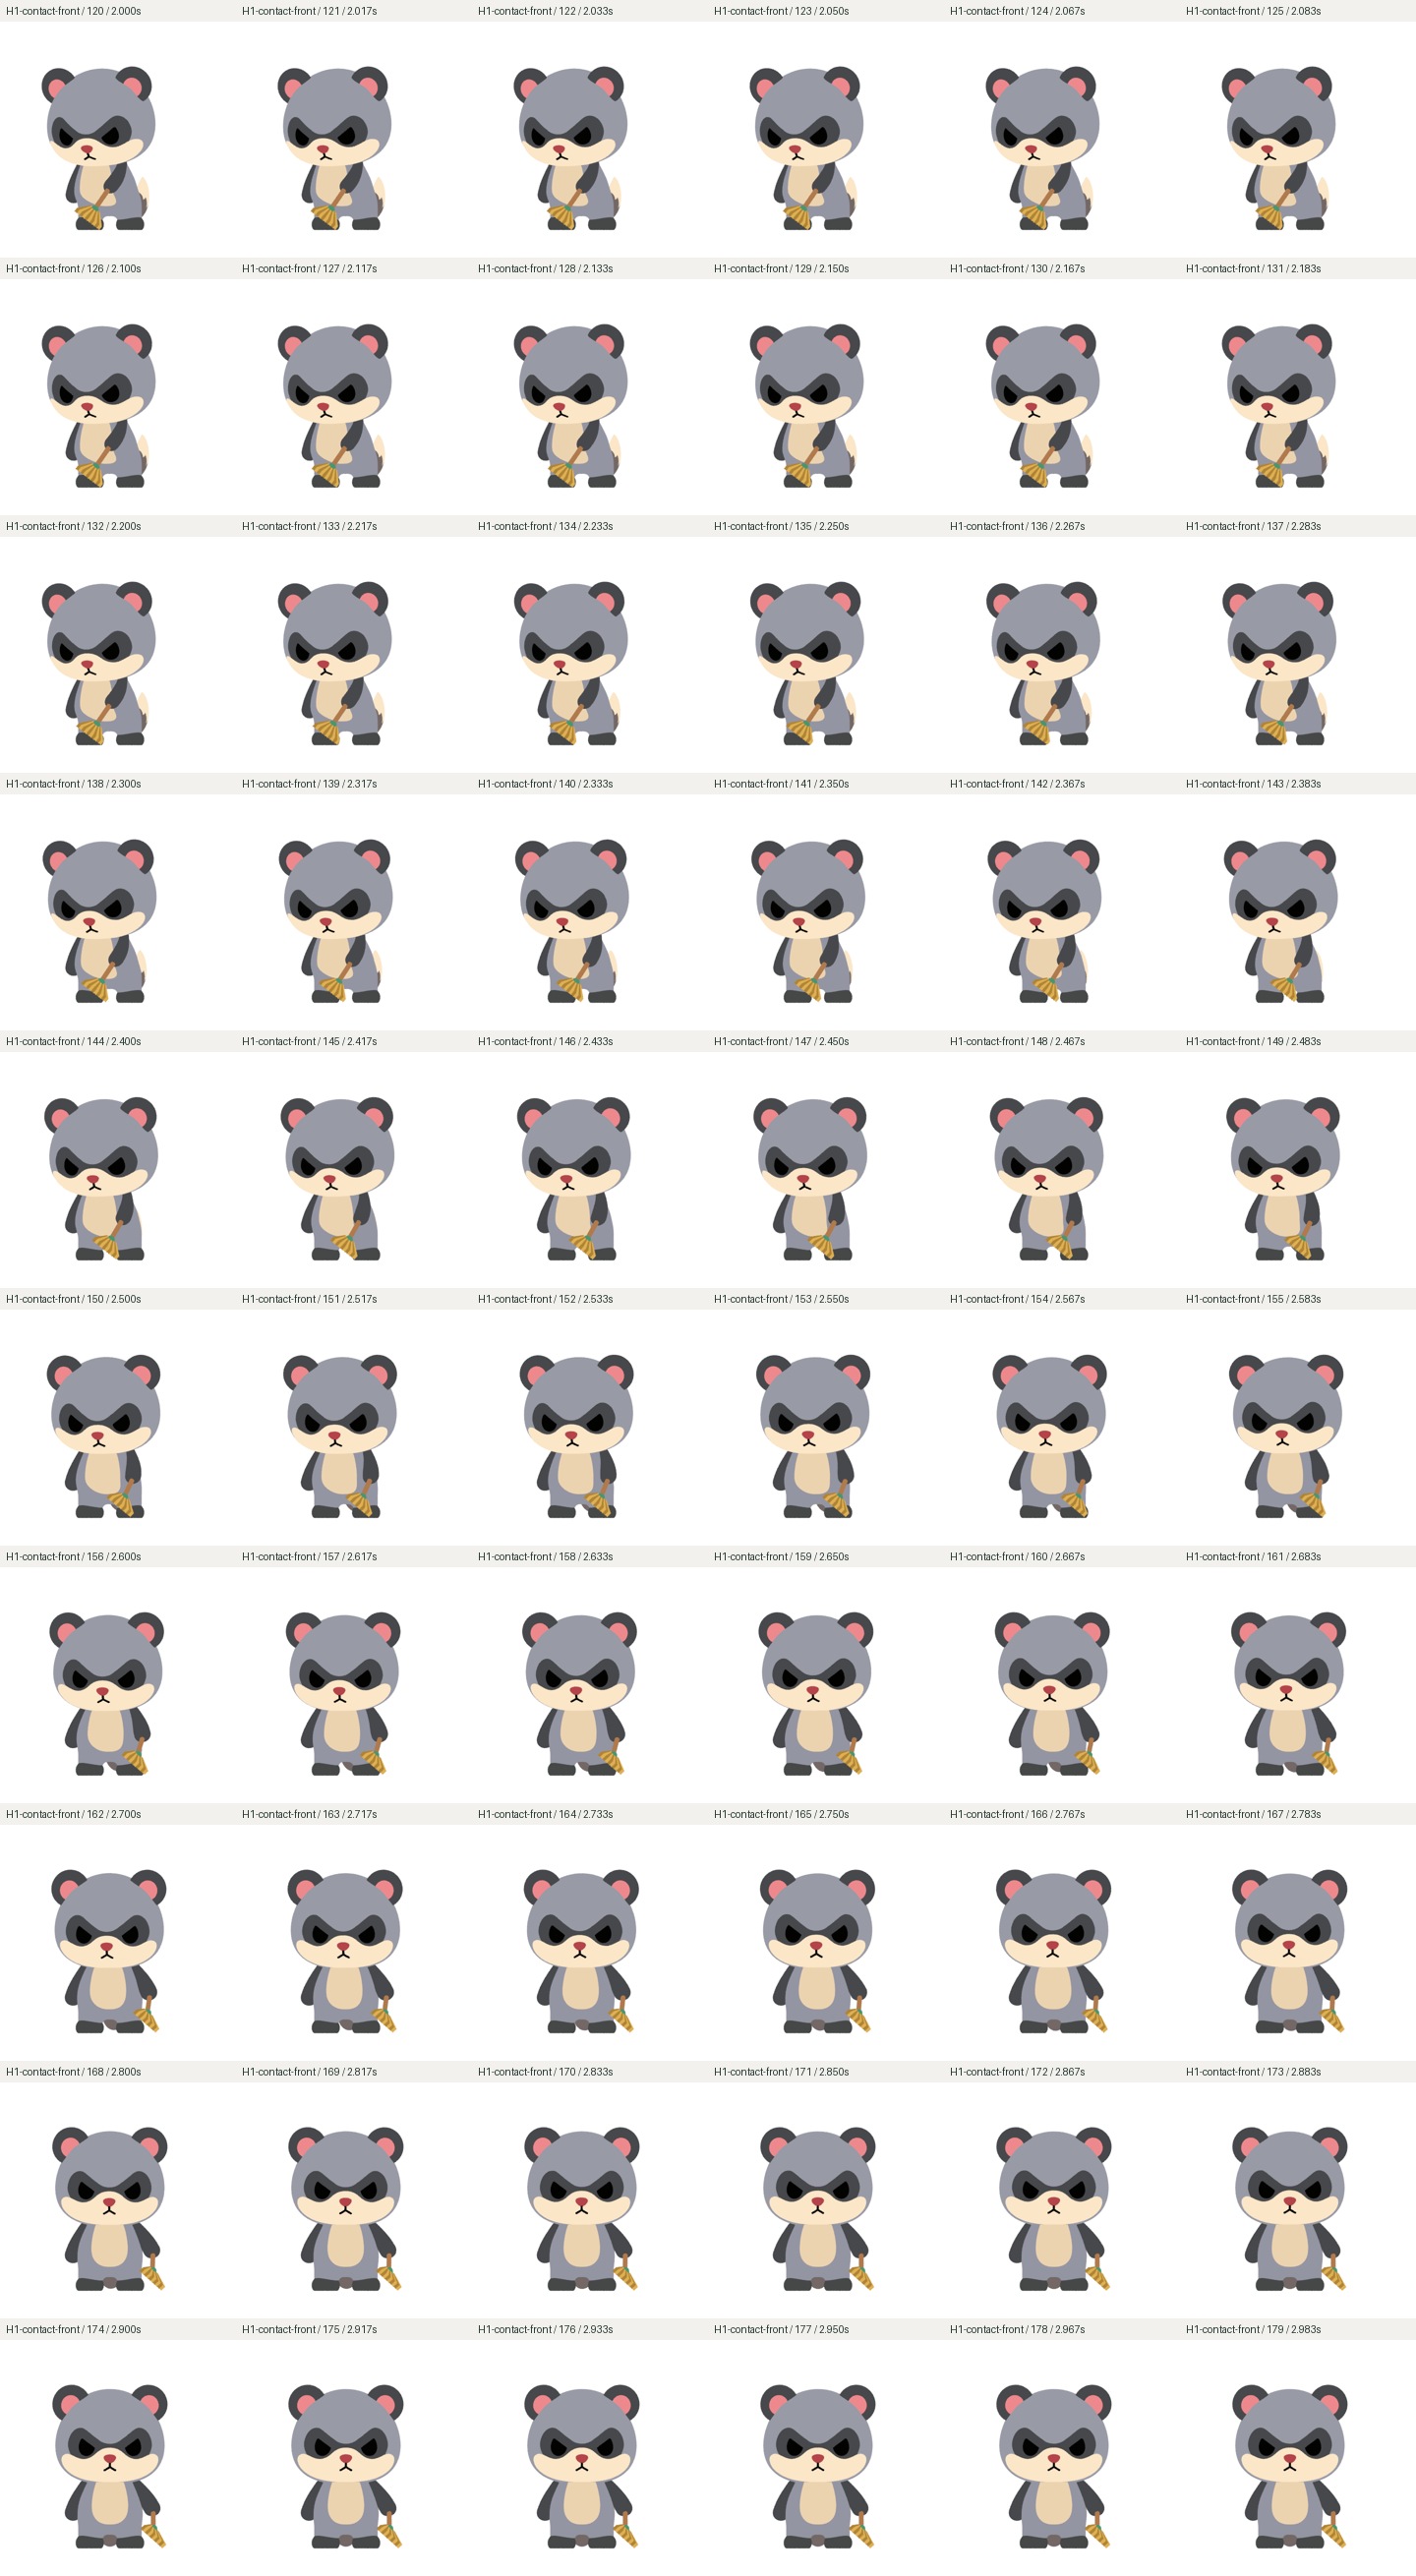 H1-contact · front · frames120–179
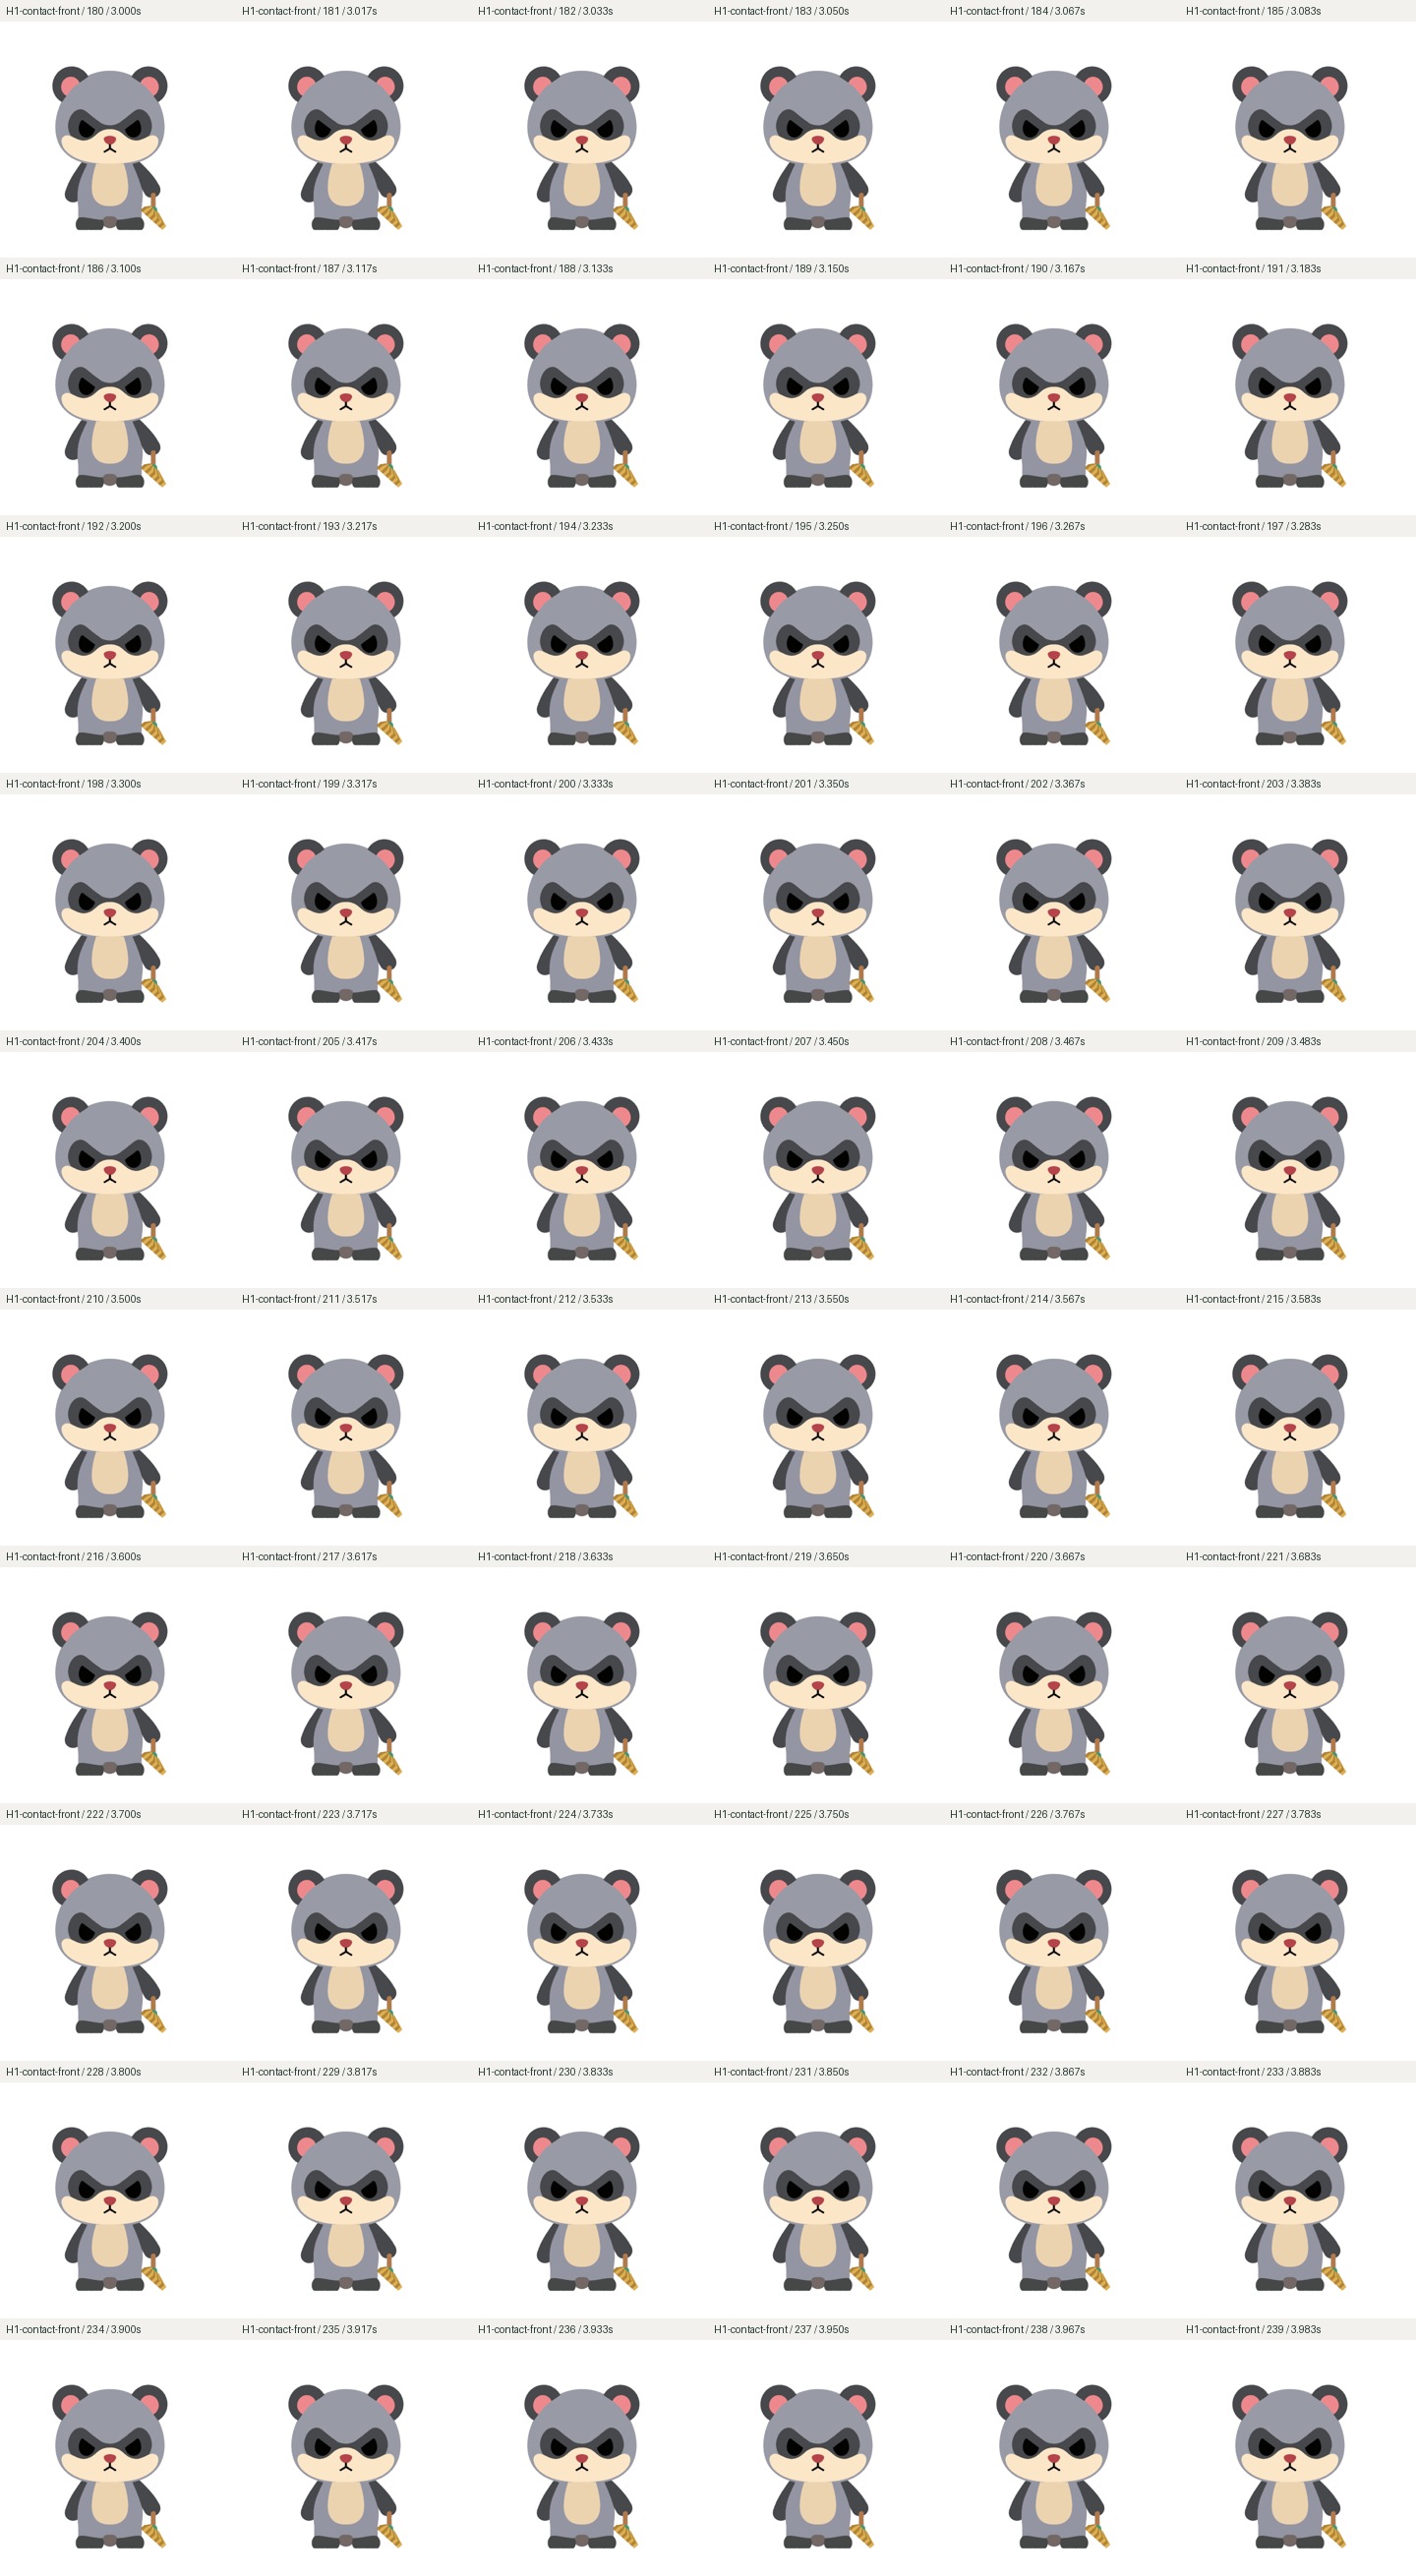 H1-contact · front · frames180–239
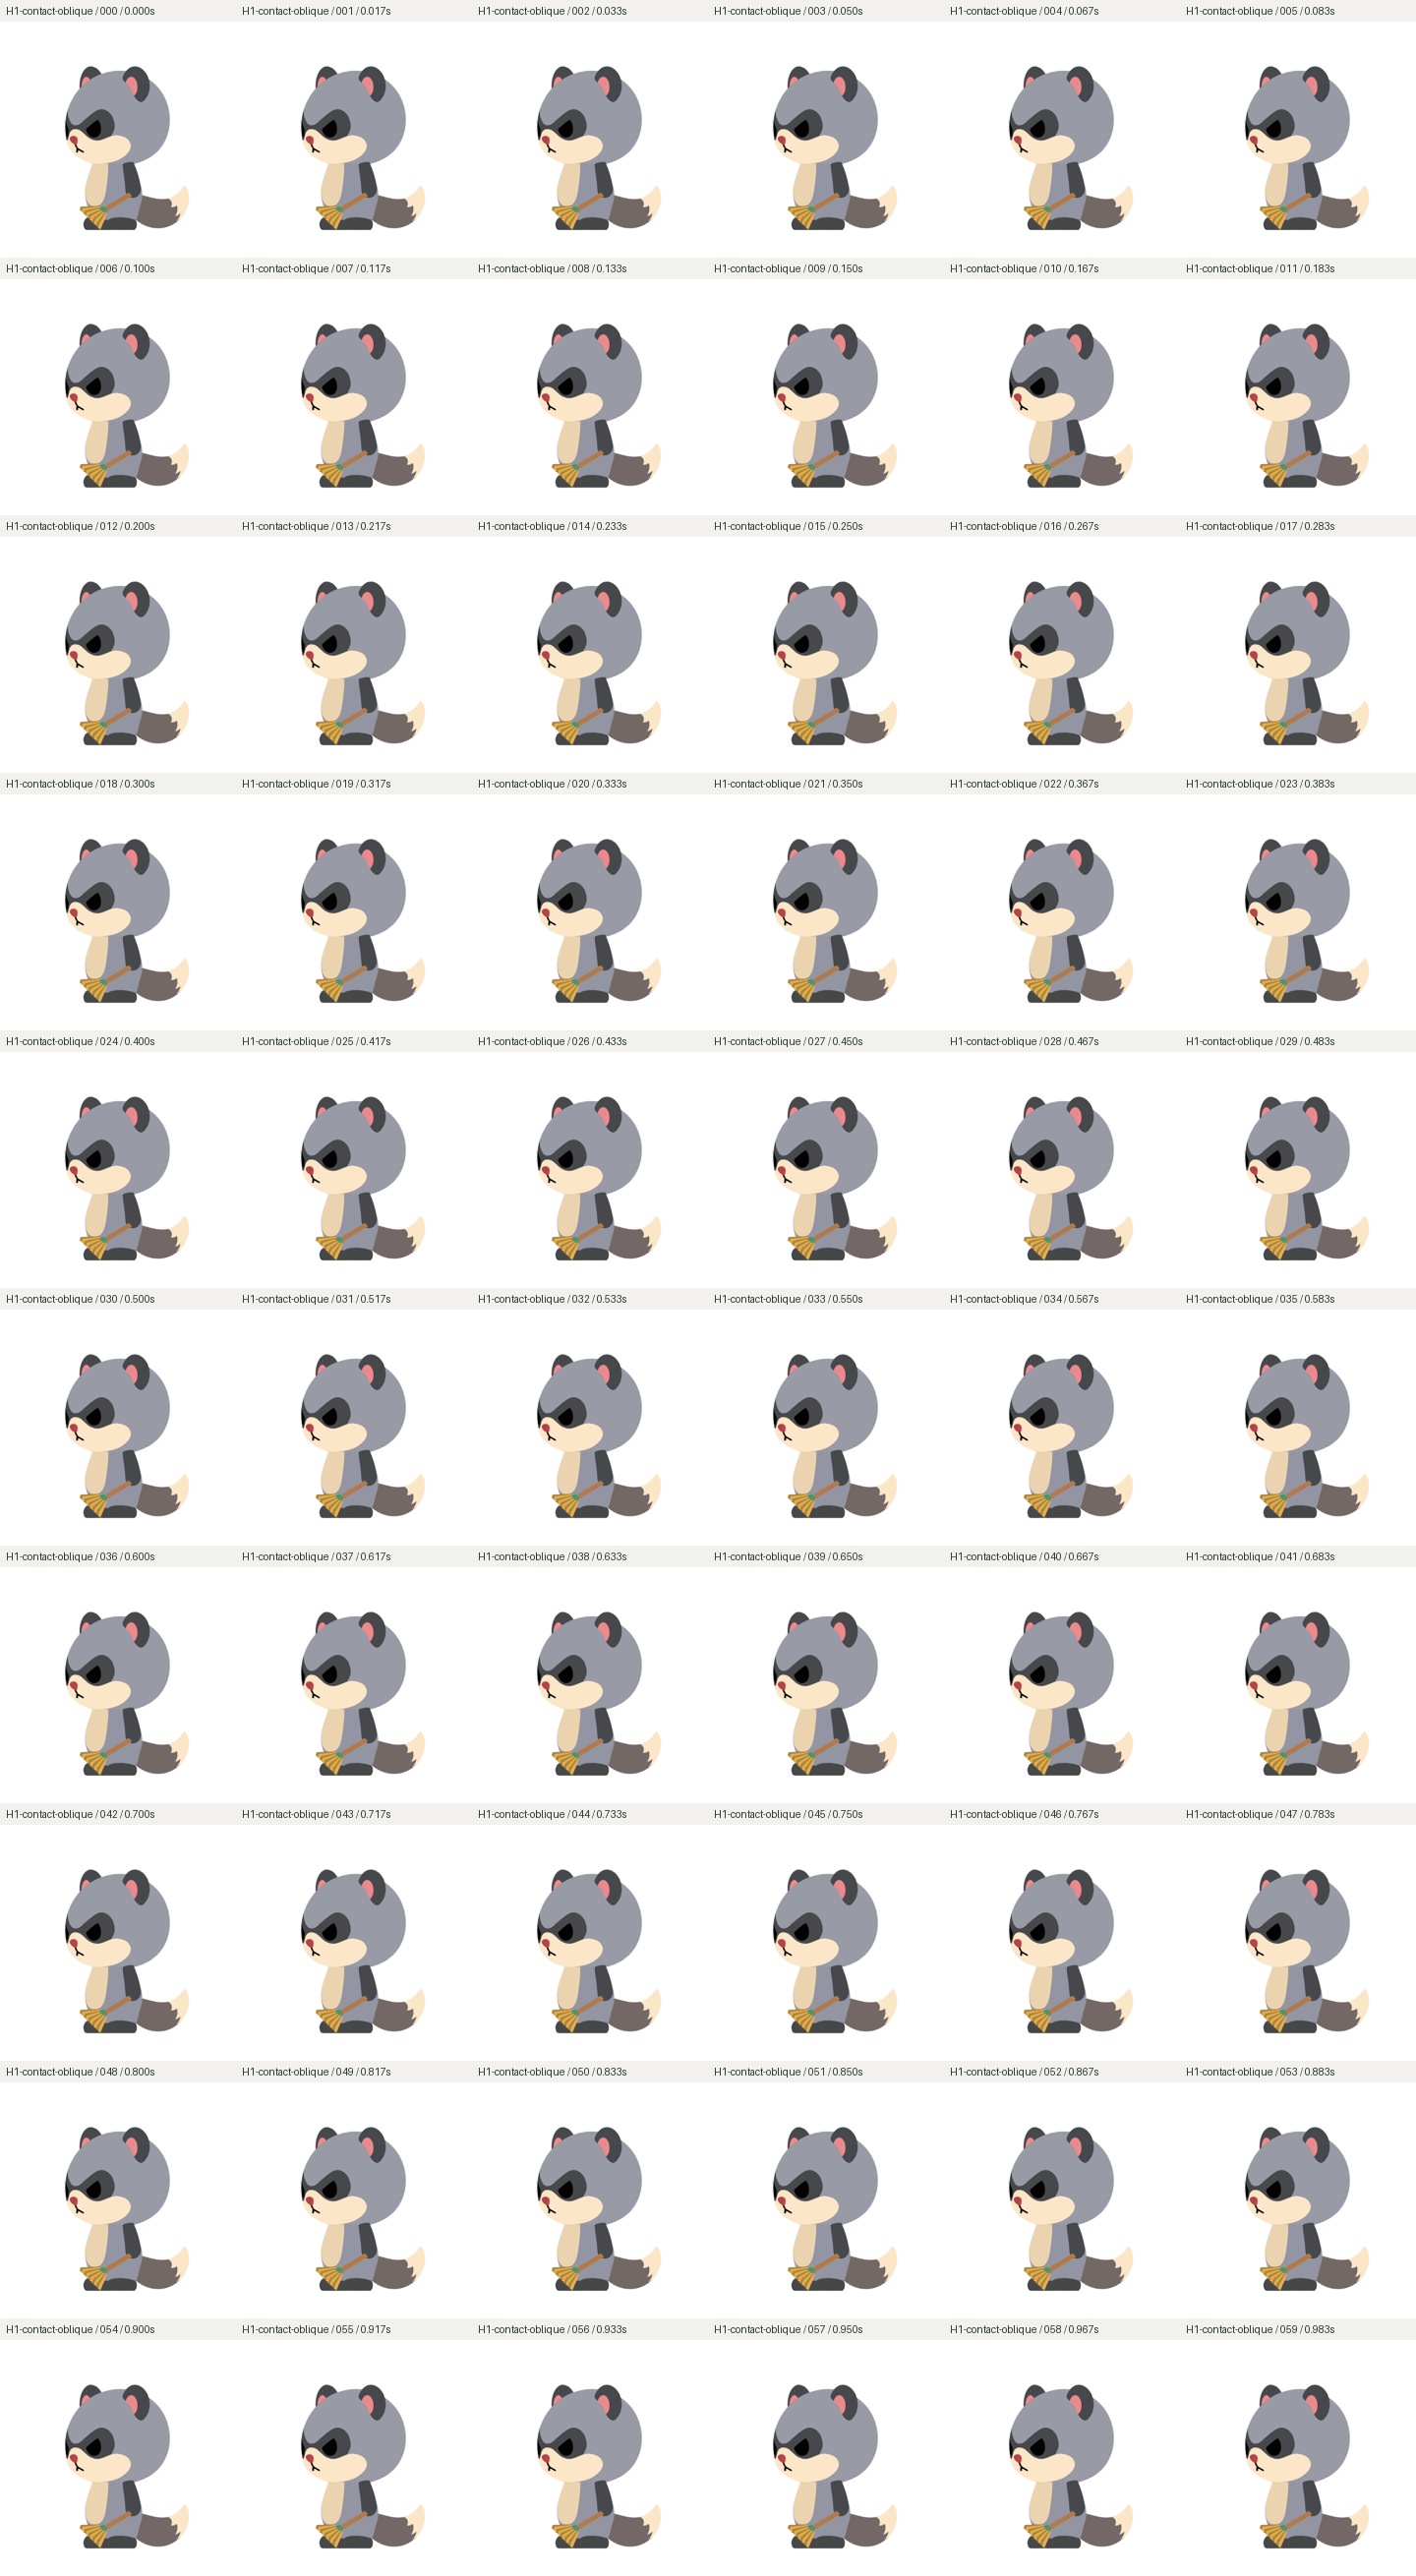 H1-contact · oblique · frames0–59
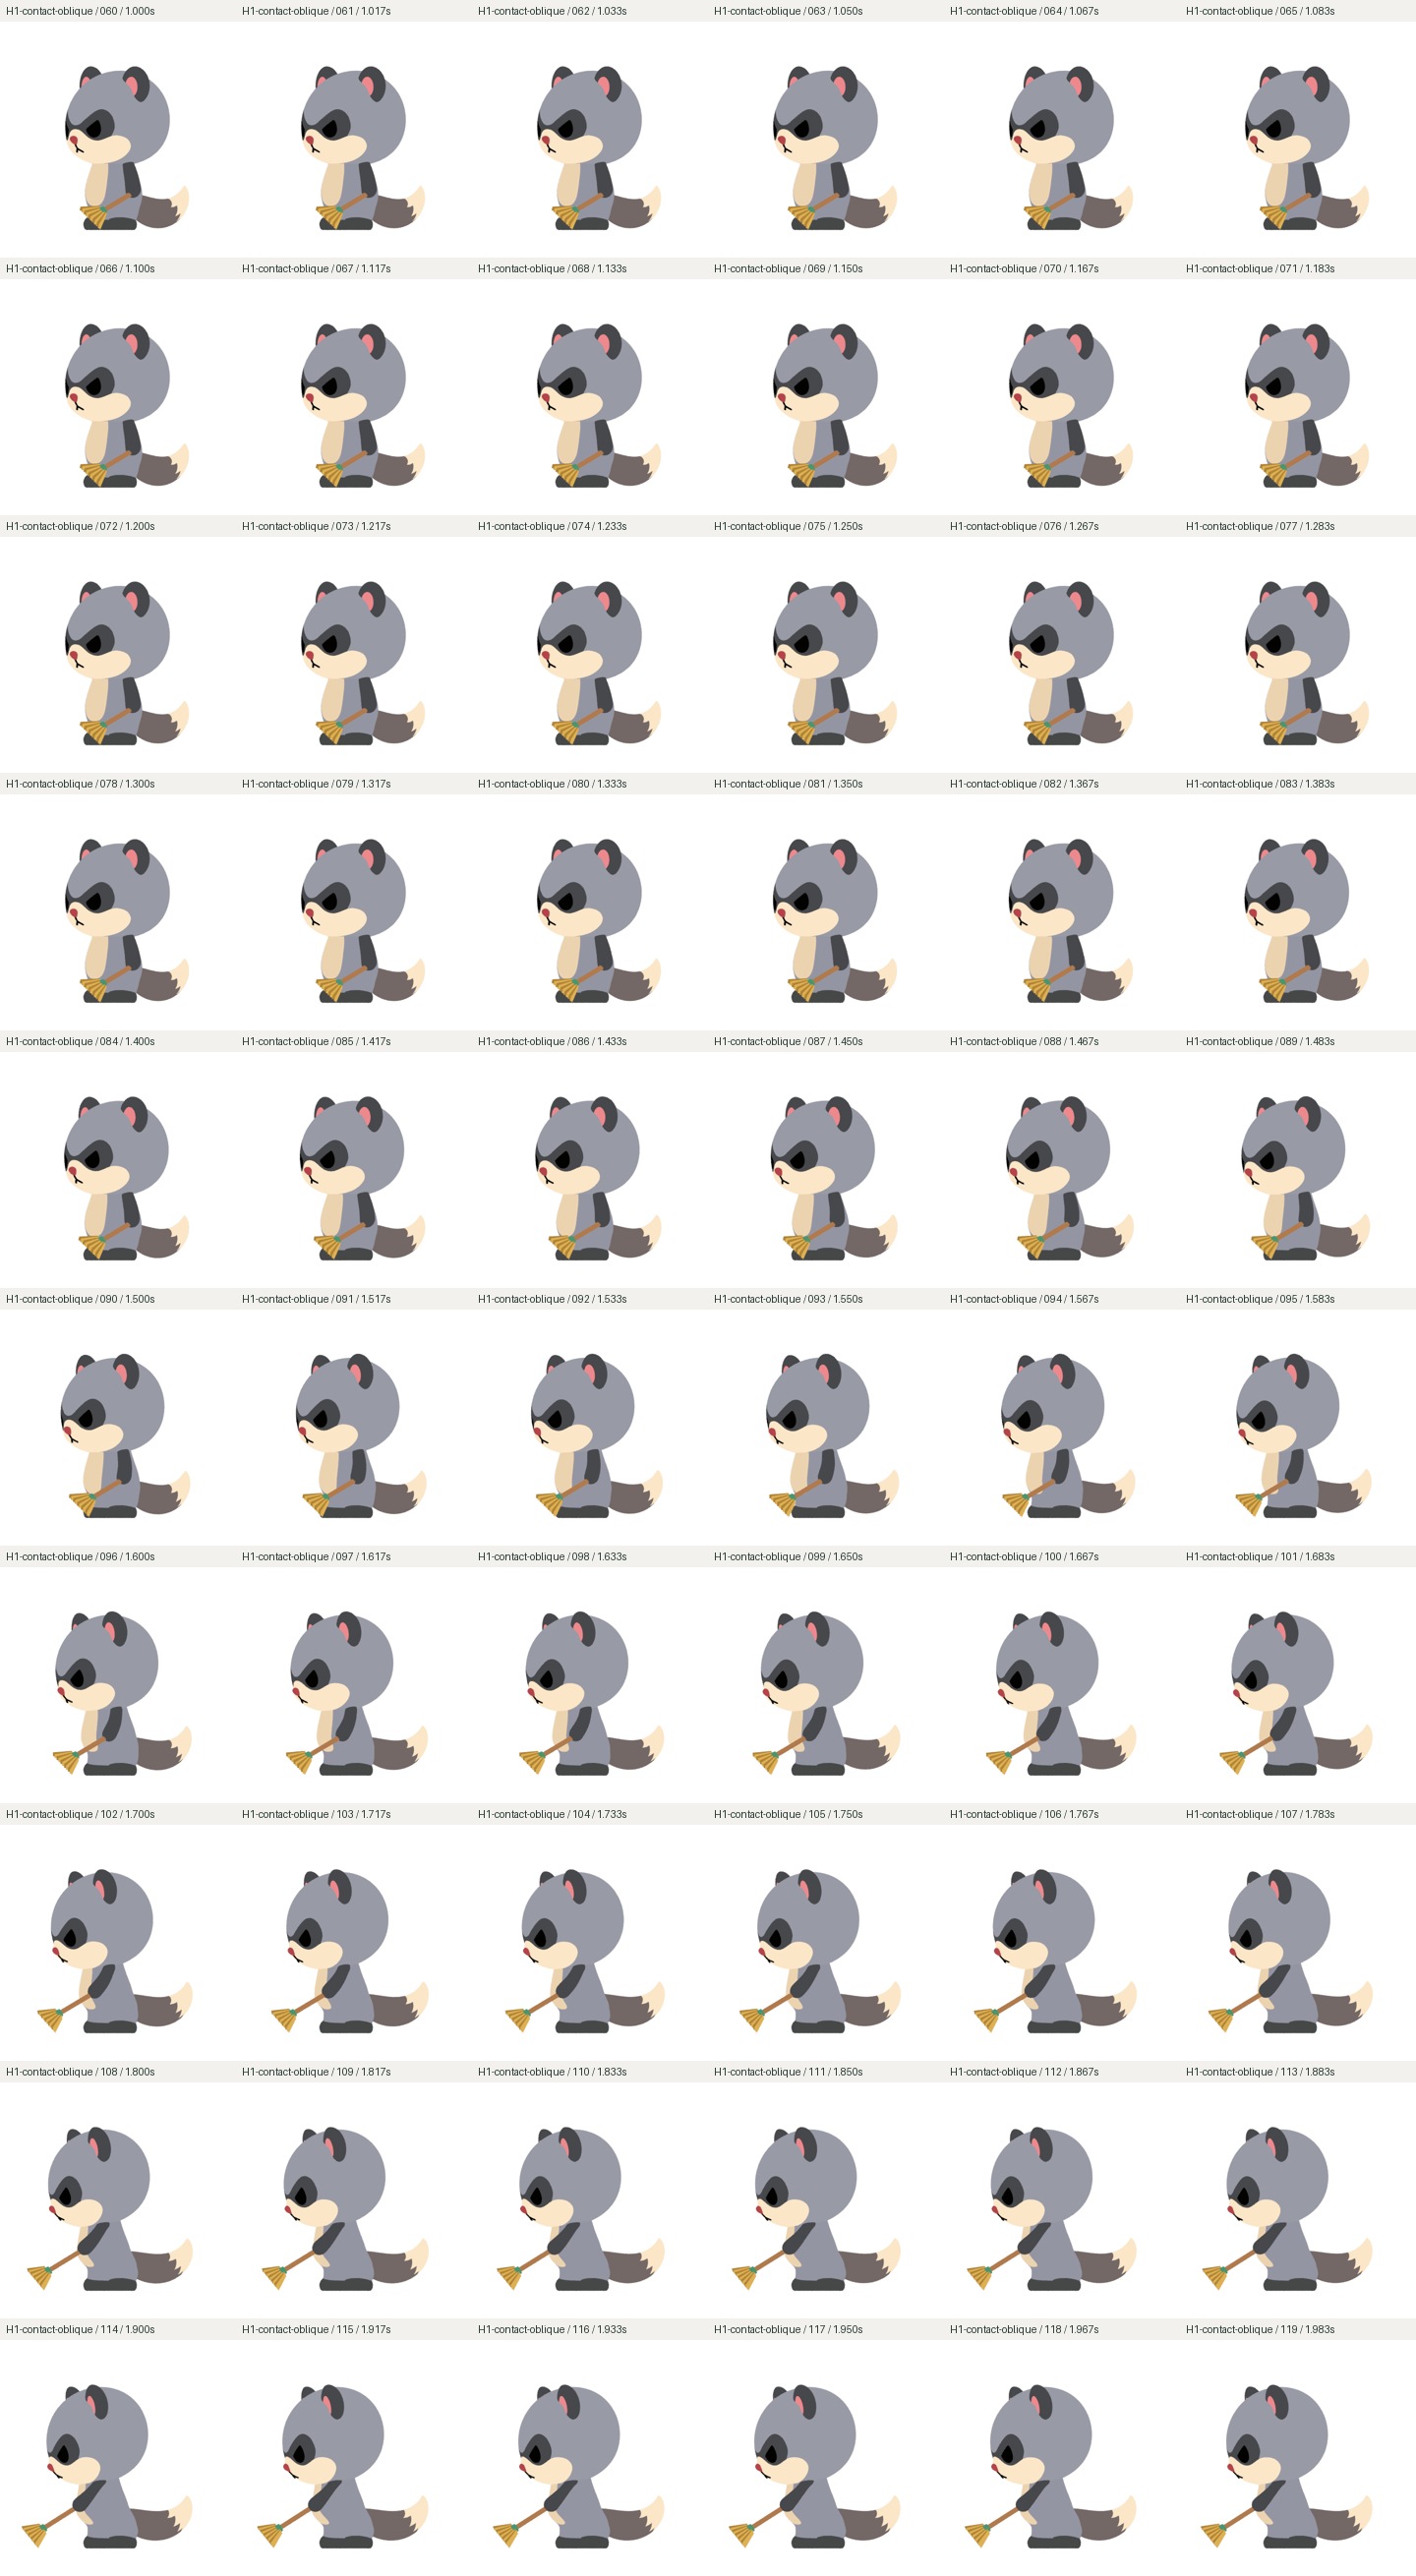 H1-contact · oblique · frames60–119
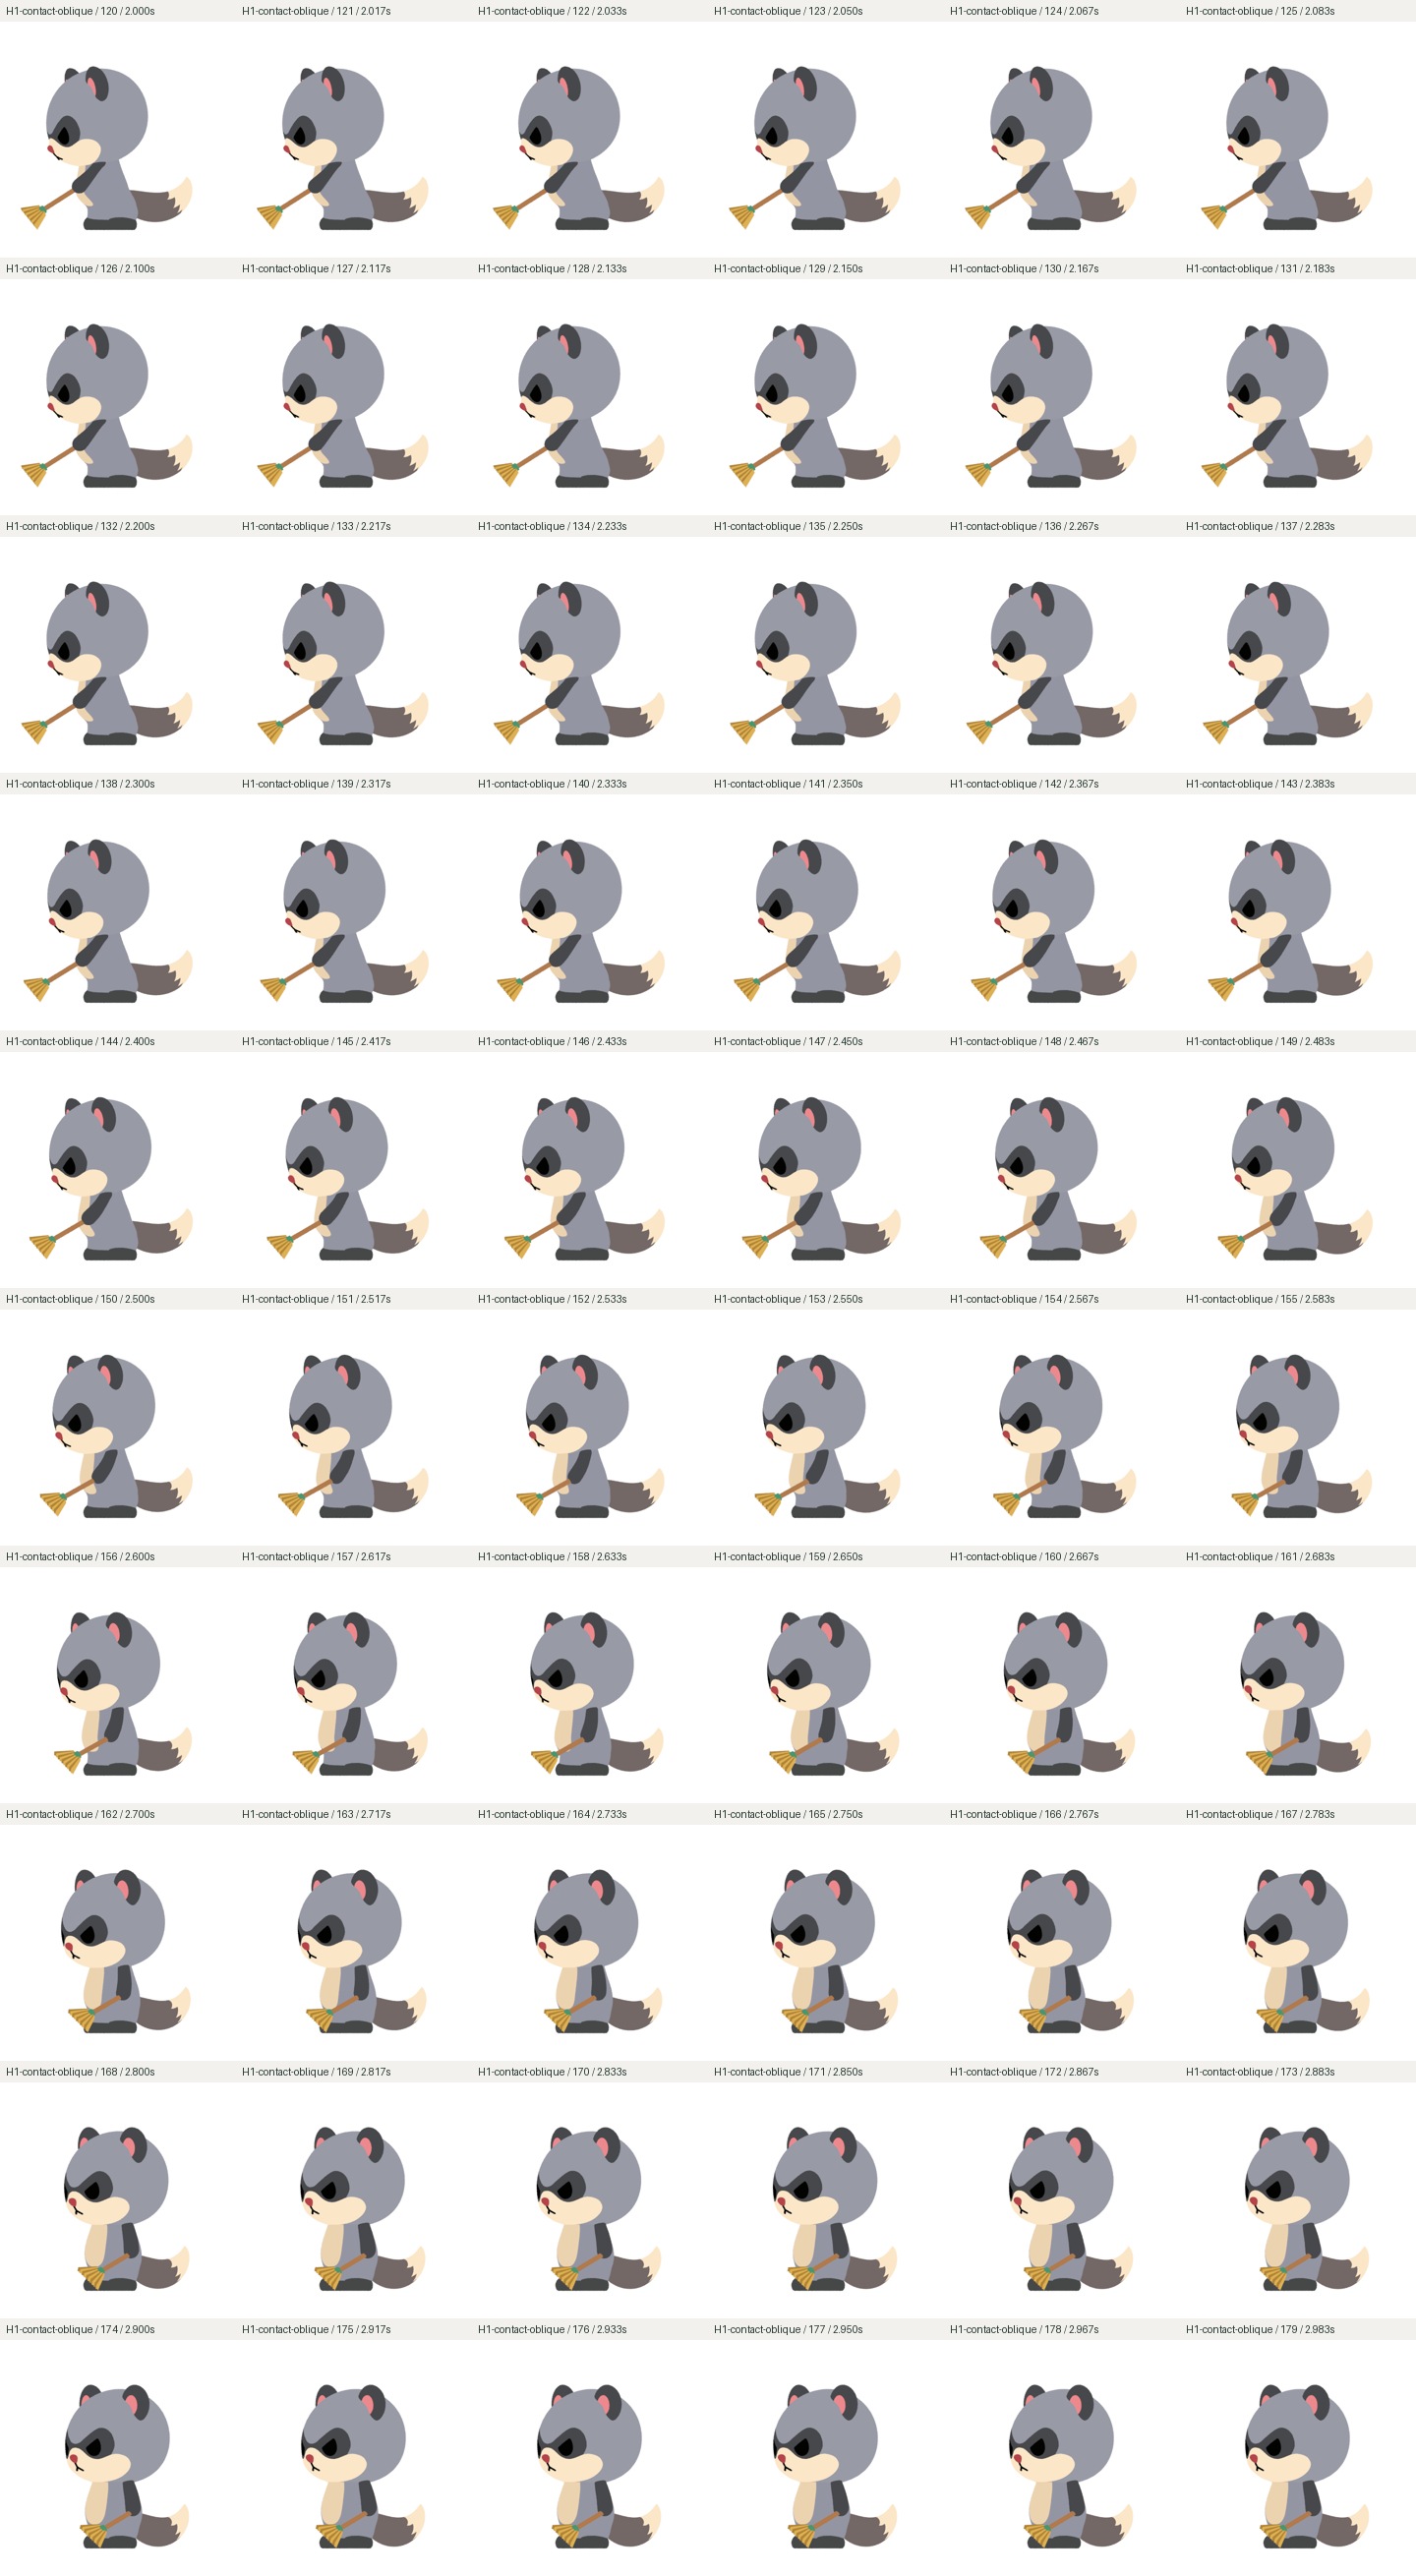 H1-contact · oblique · frames120–179
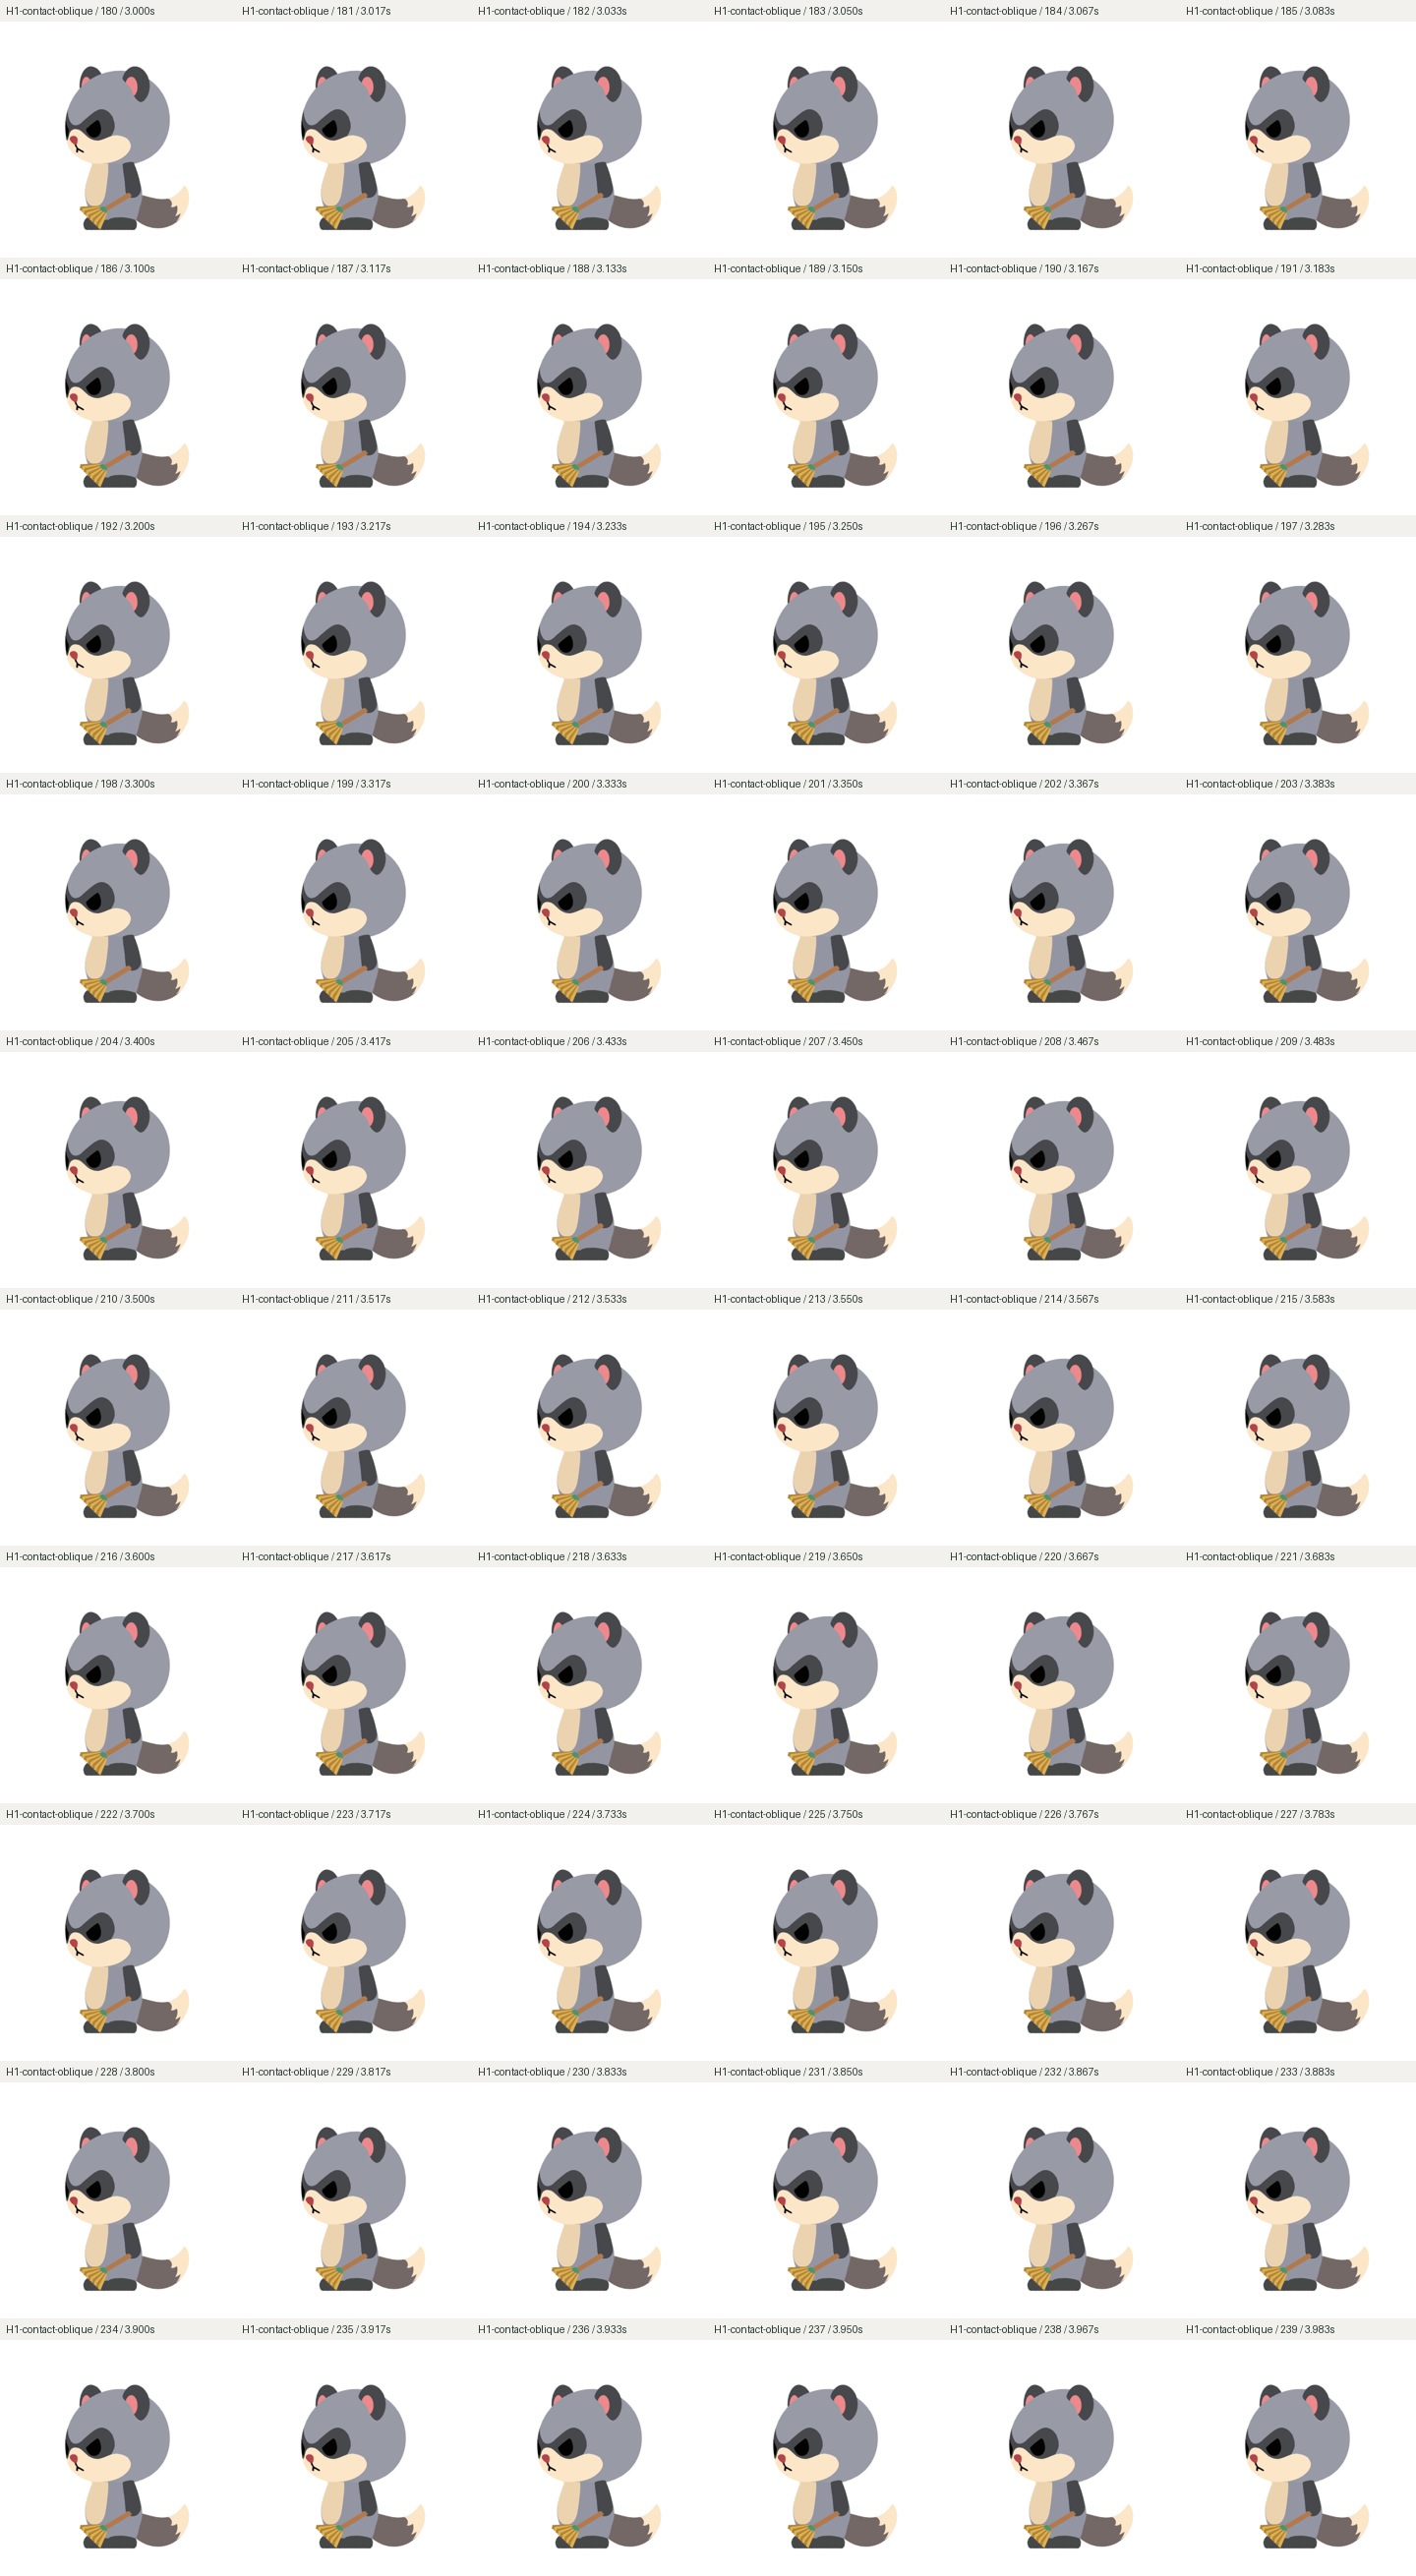 H1-contact · oblique · frames180–239
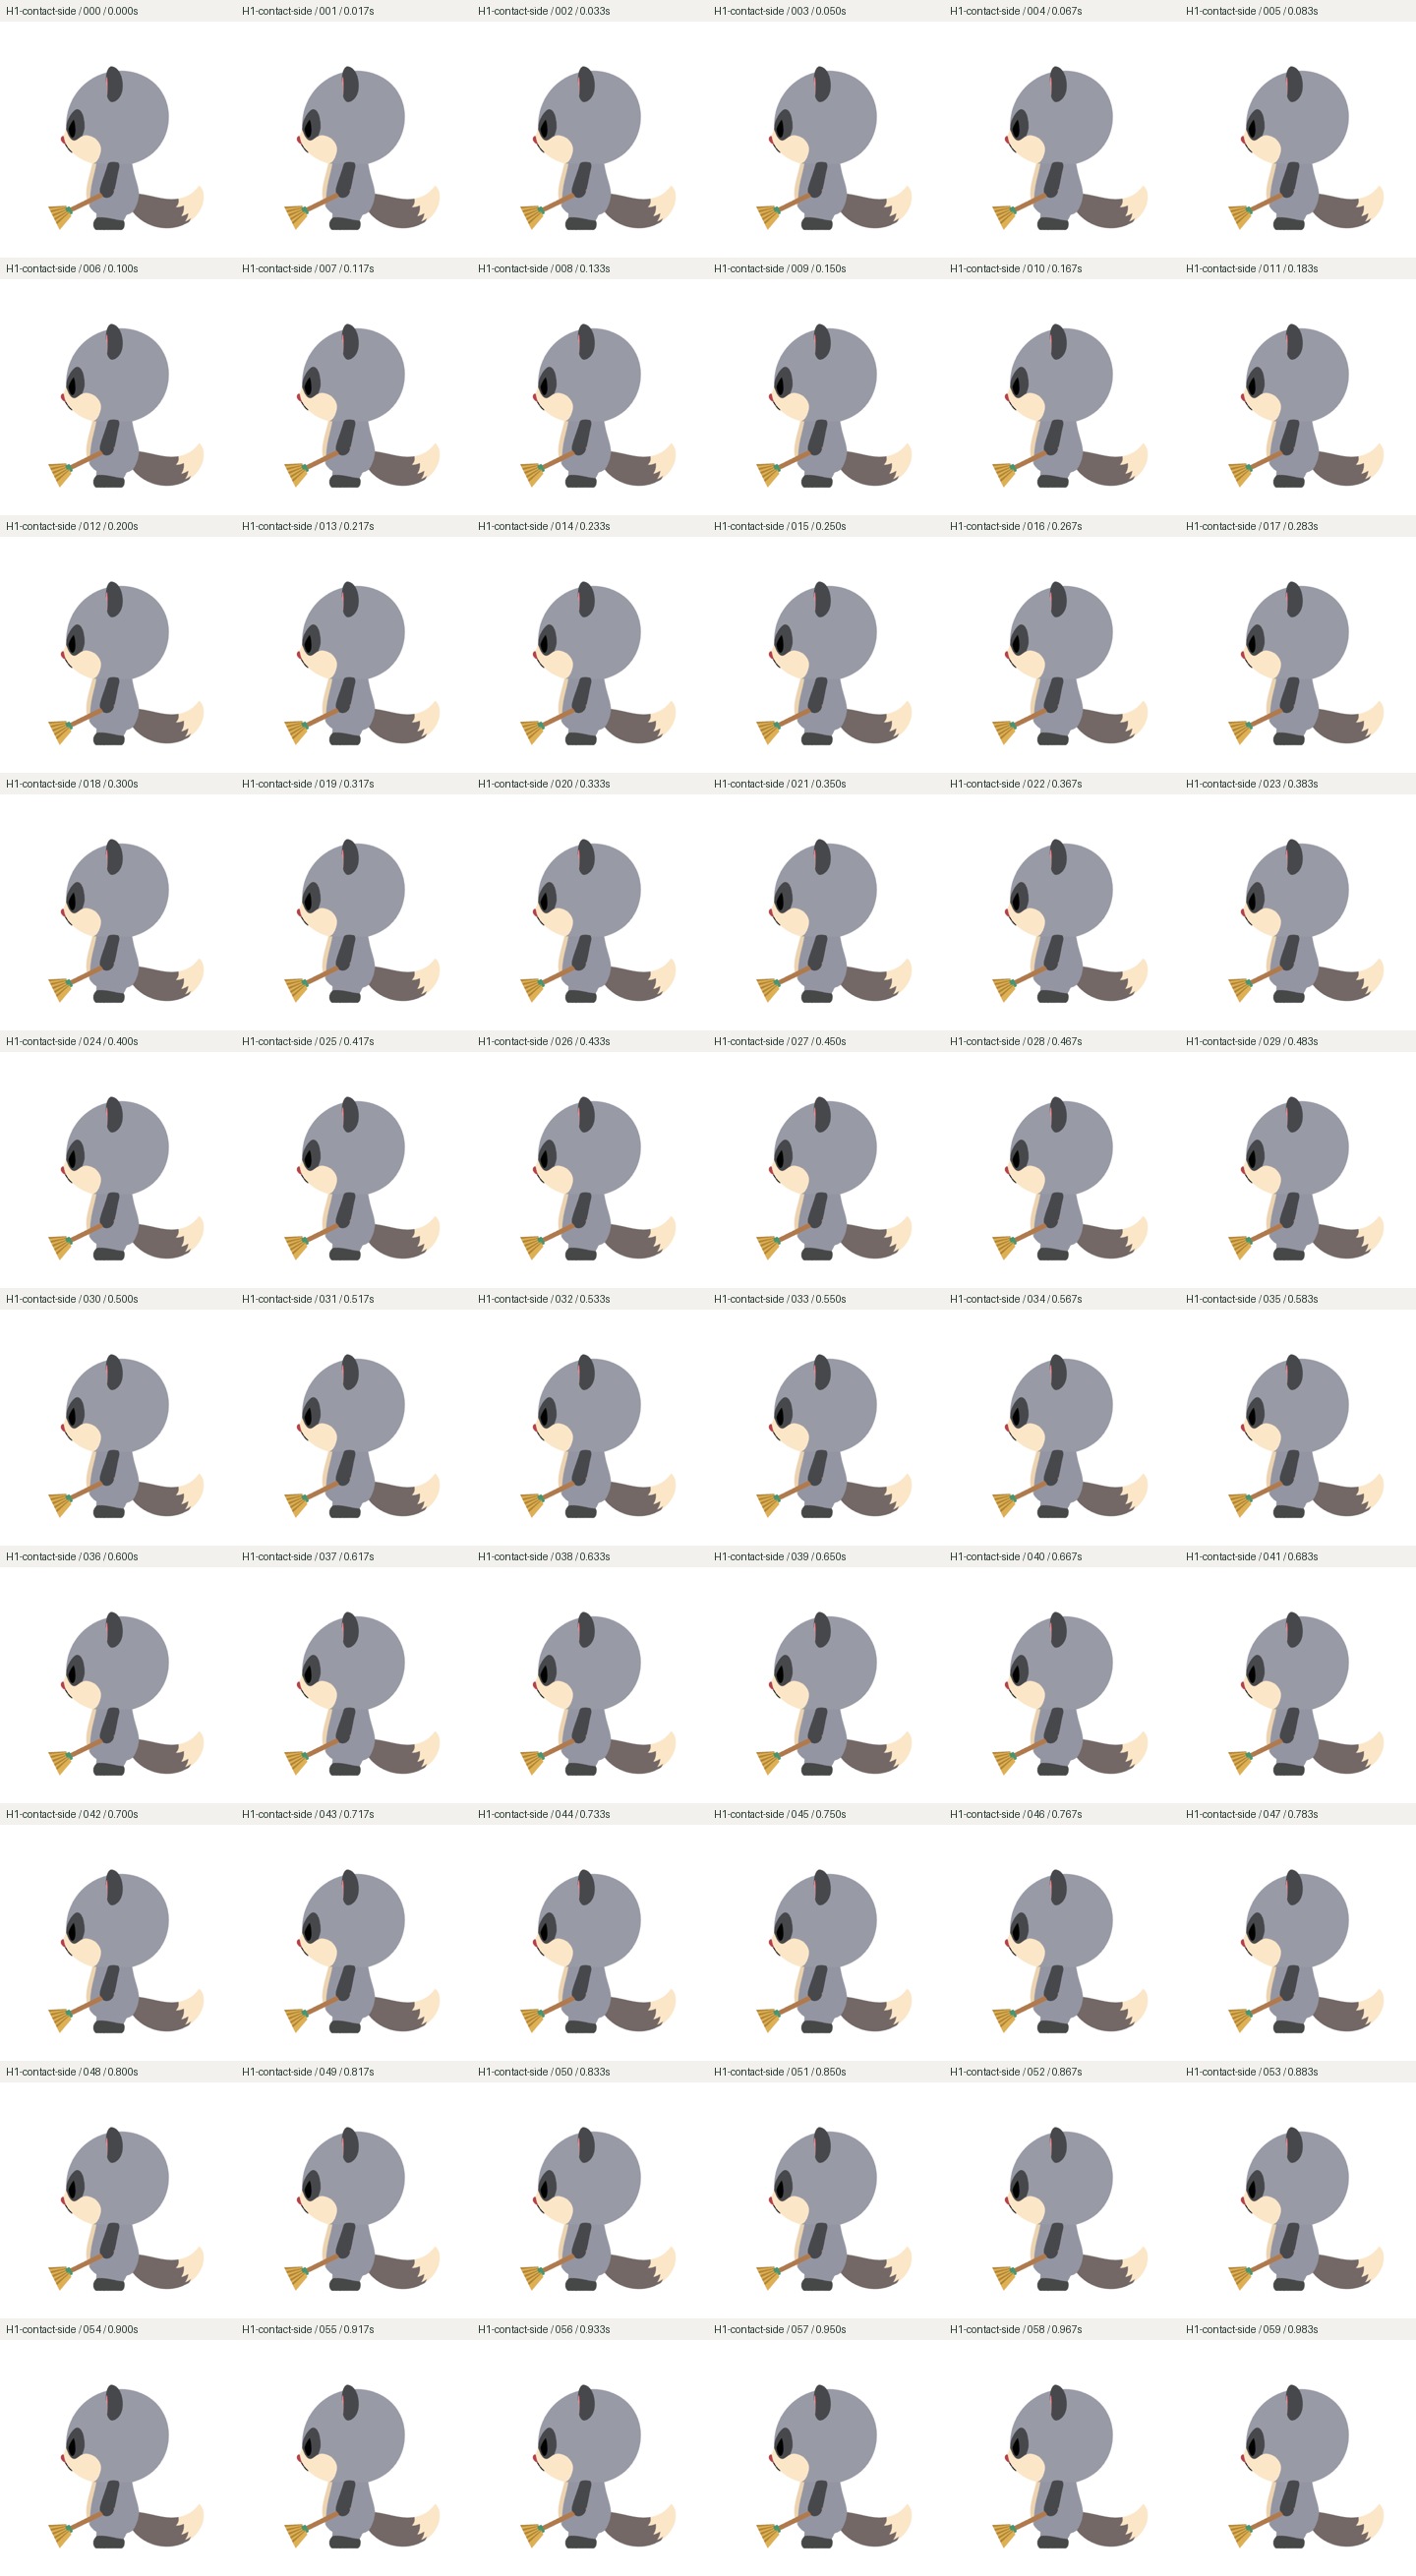 H1-contact · side · frames0–59
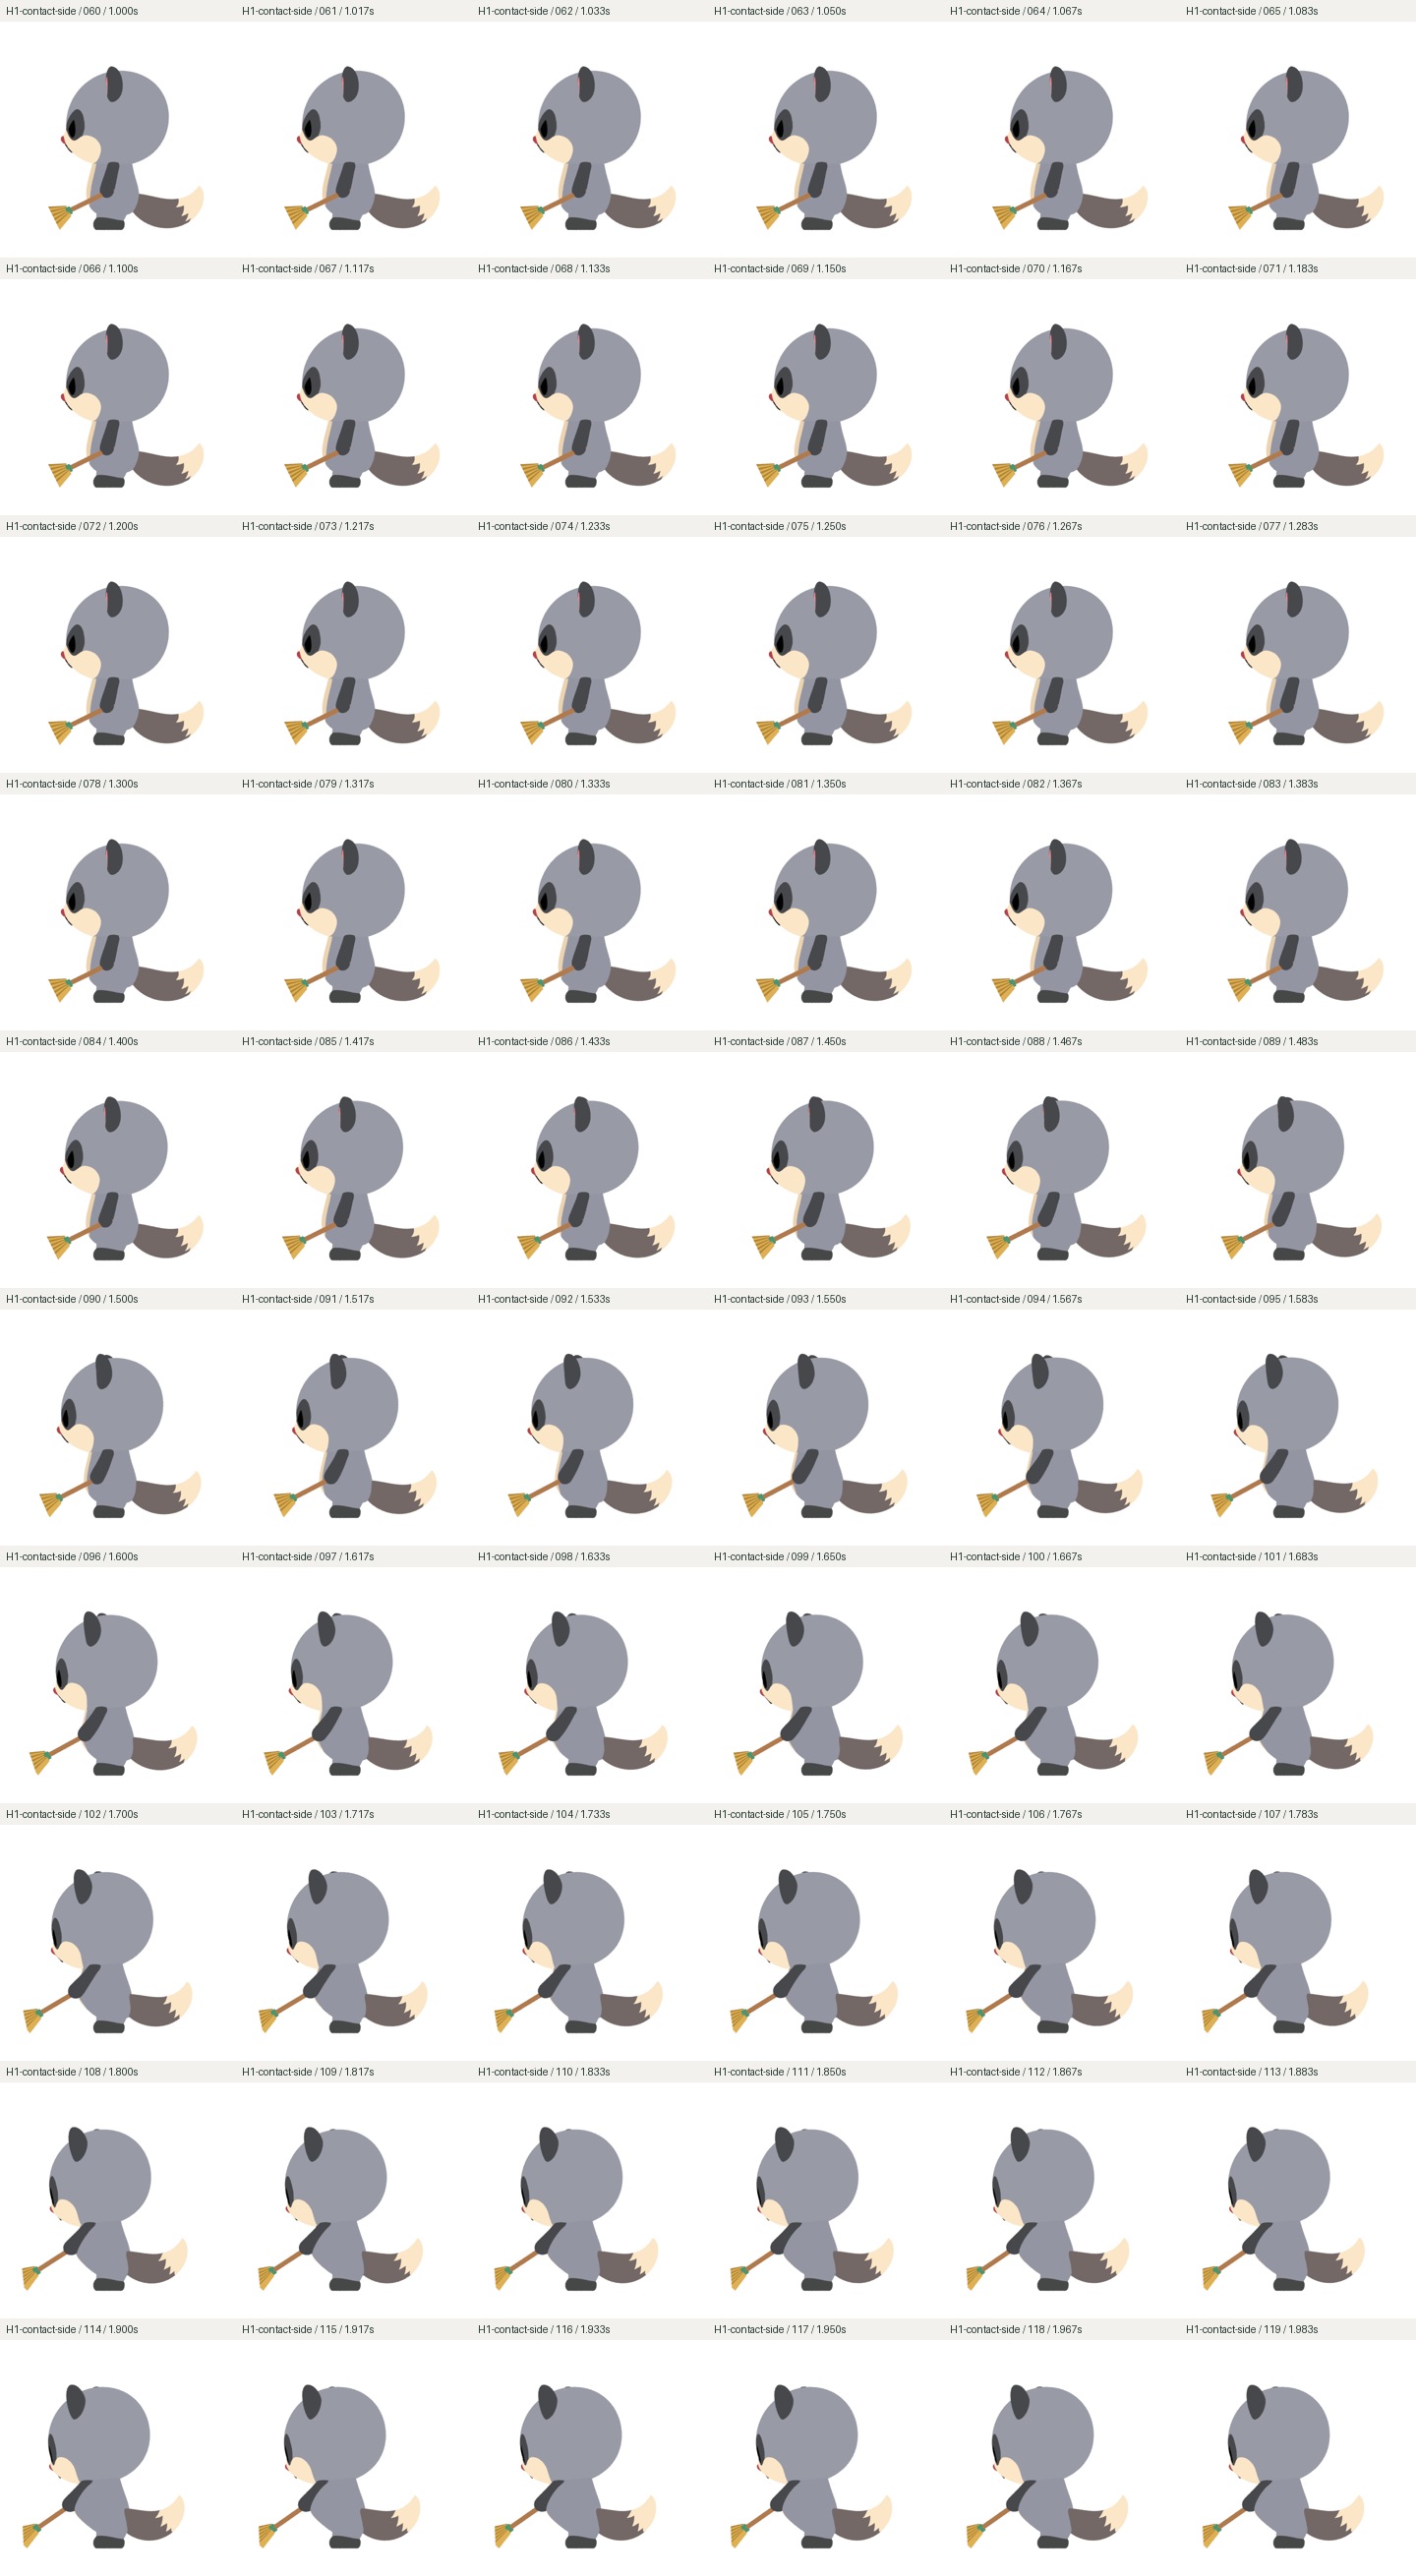 H1-contact · side · frames60–119
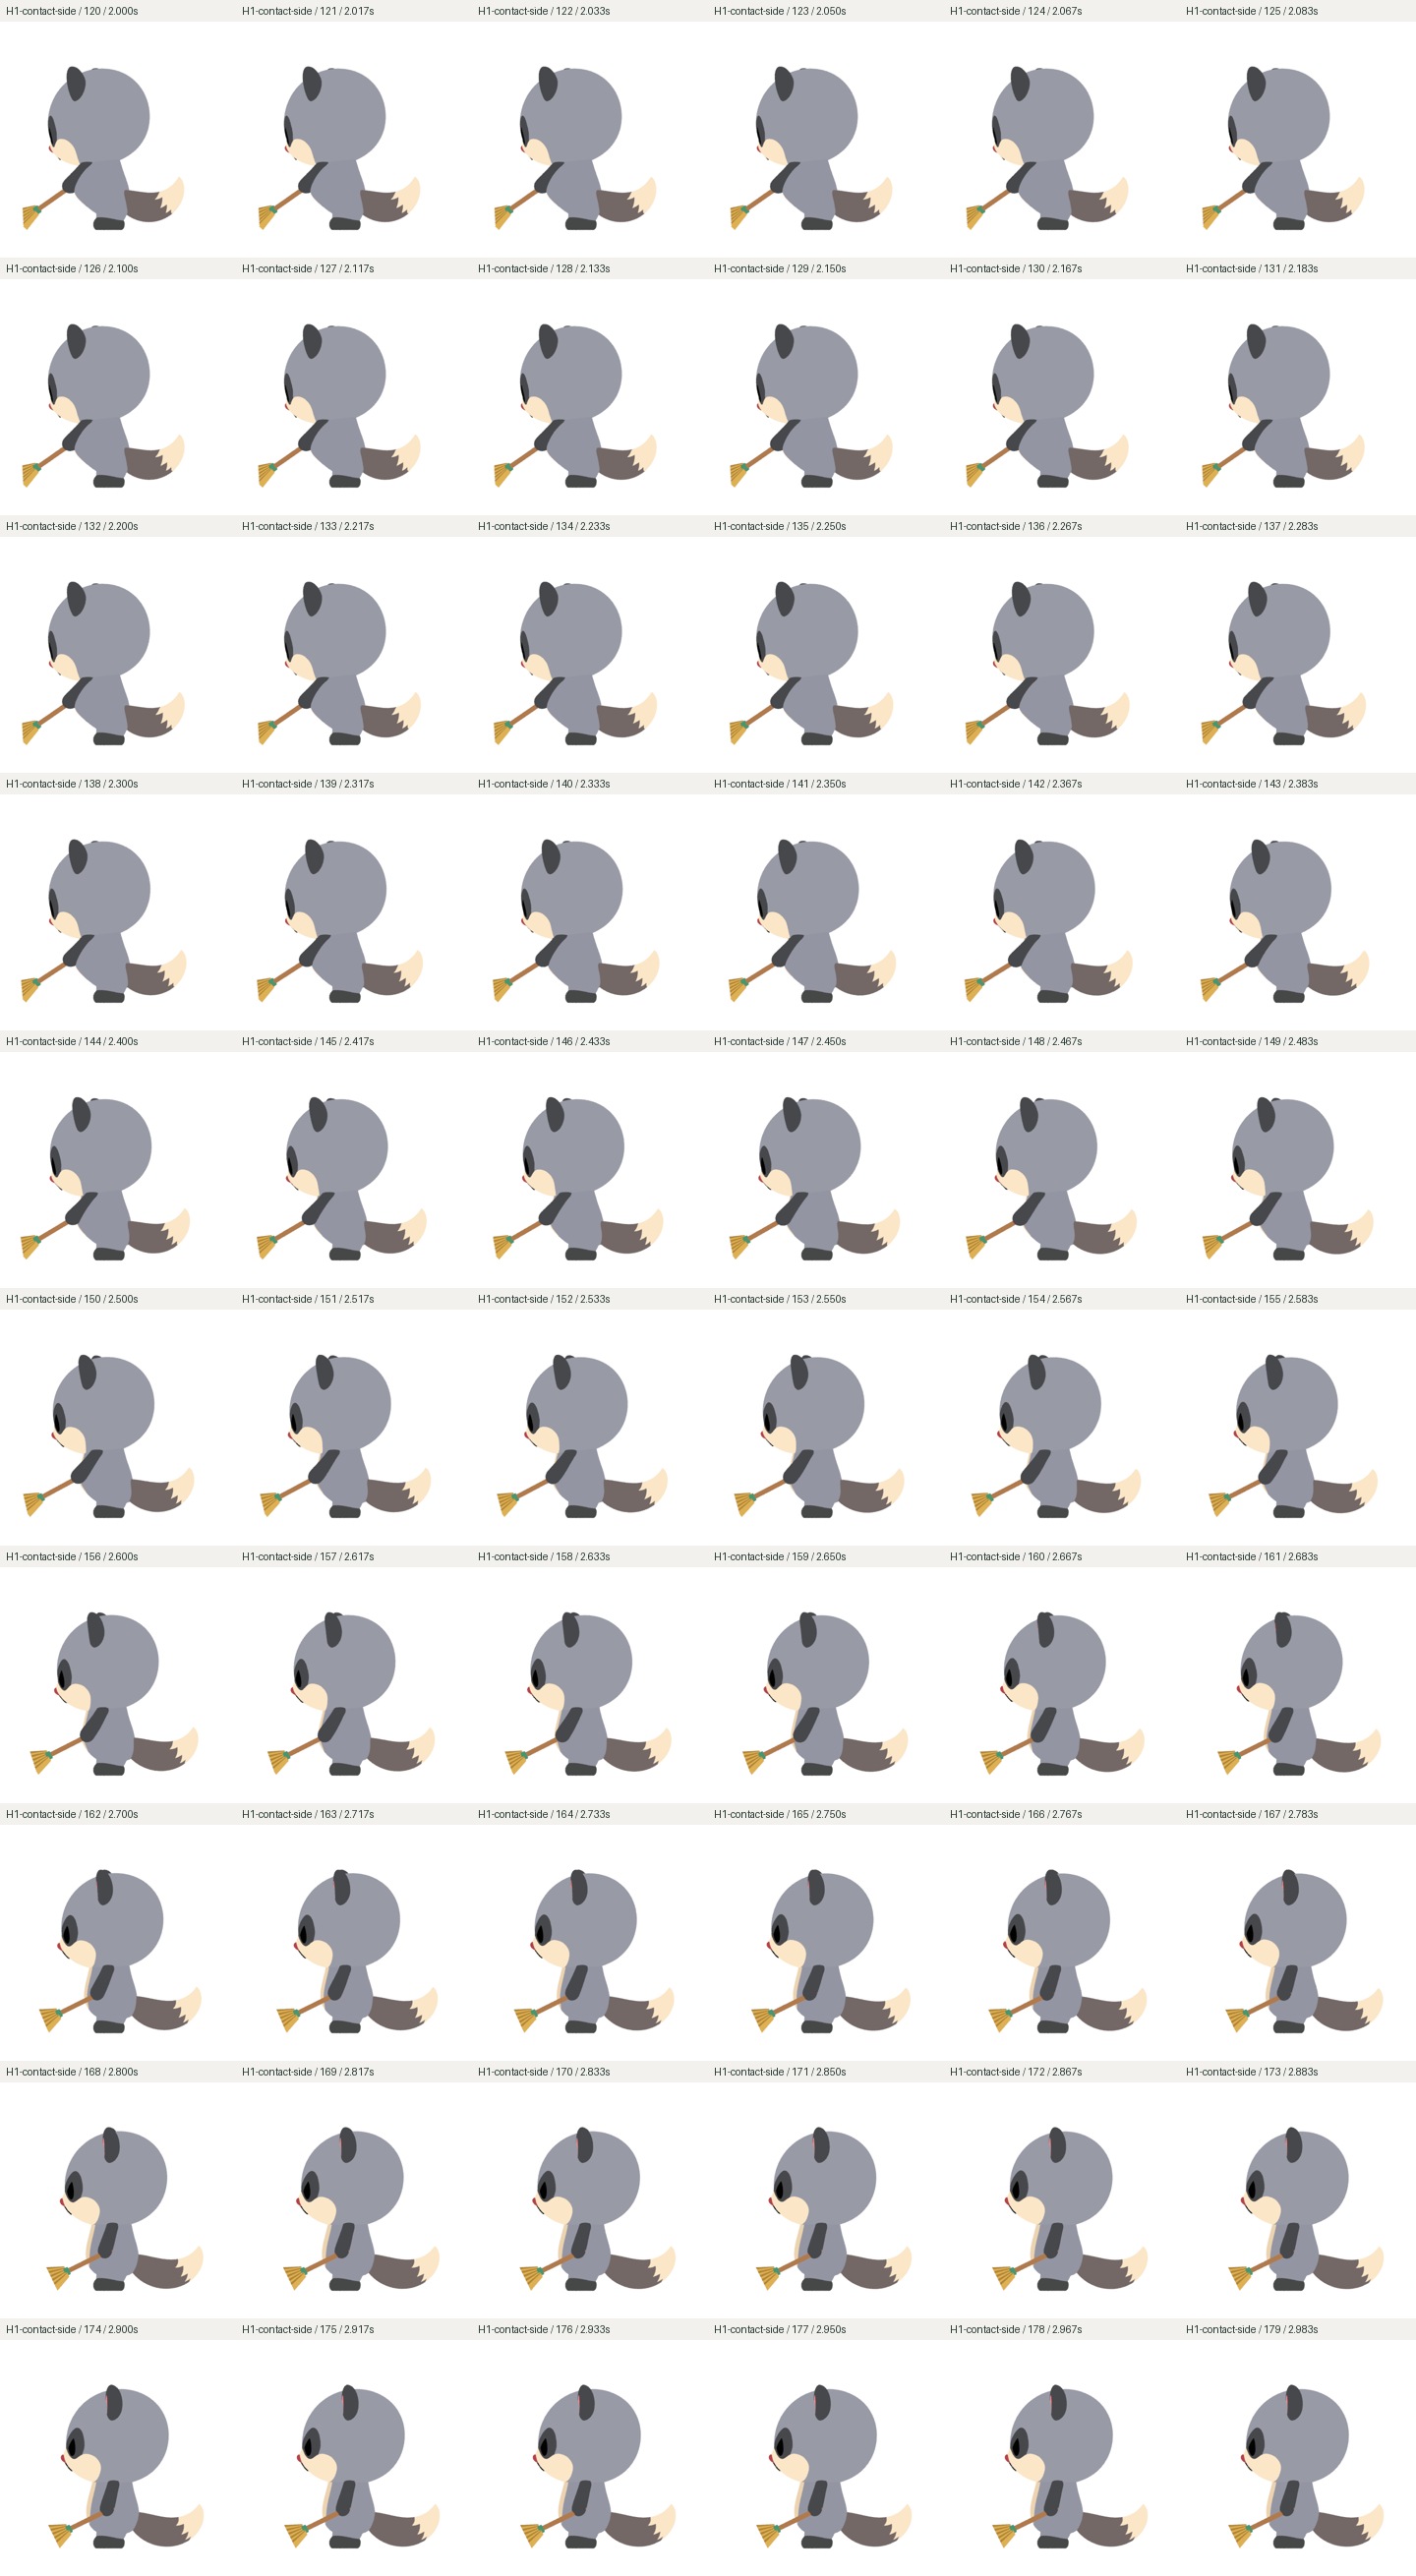 H1-contact · side · frames120–179
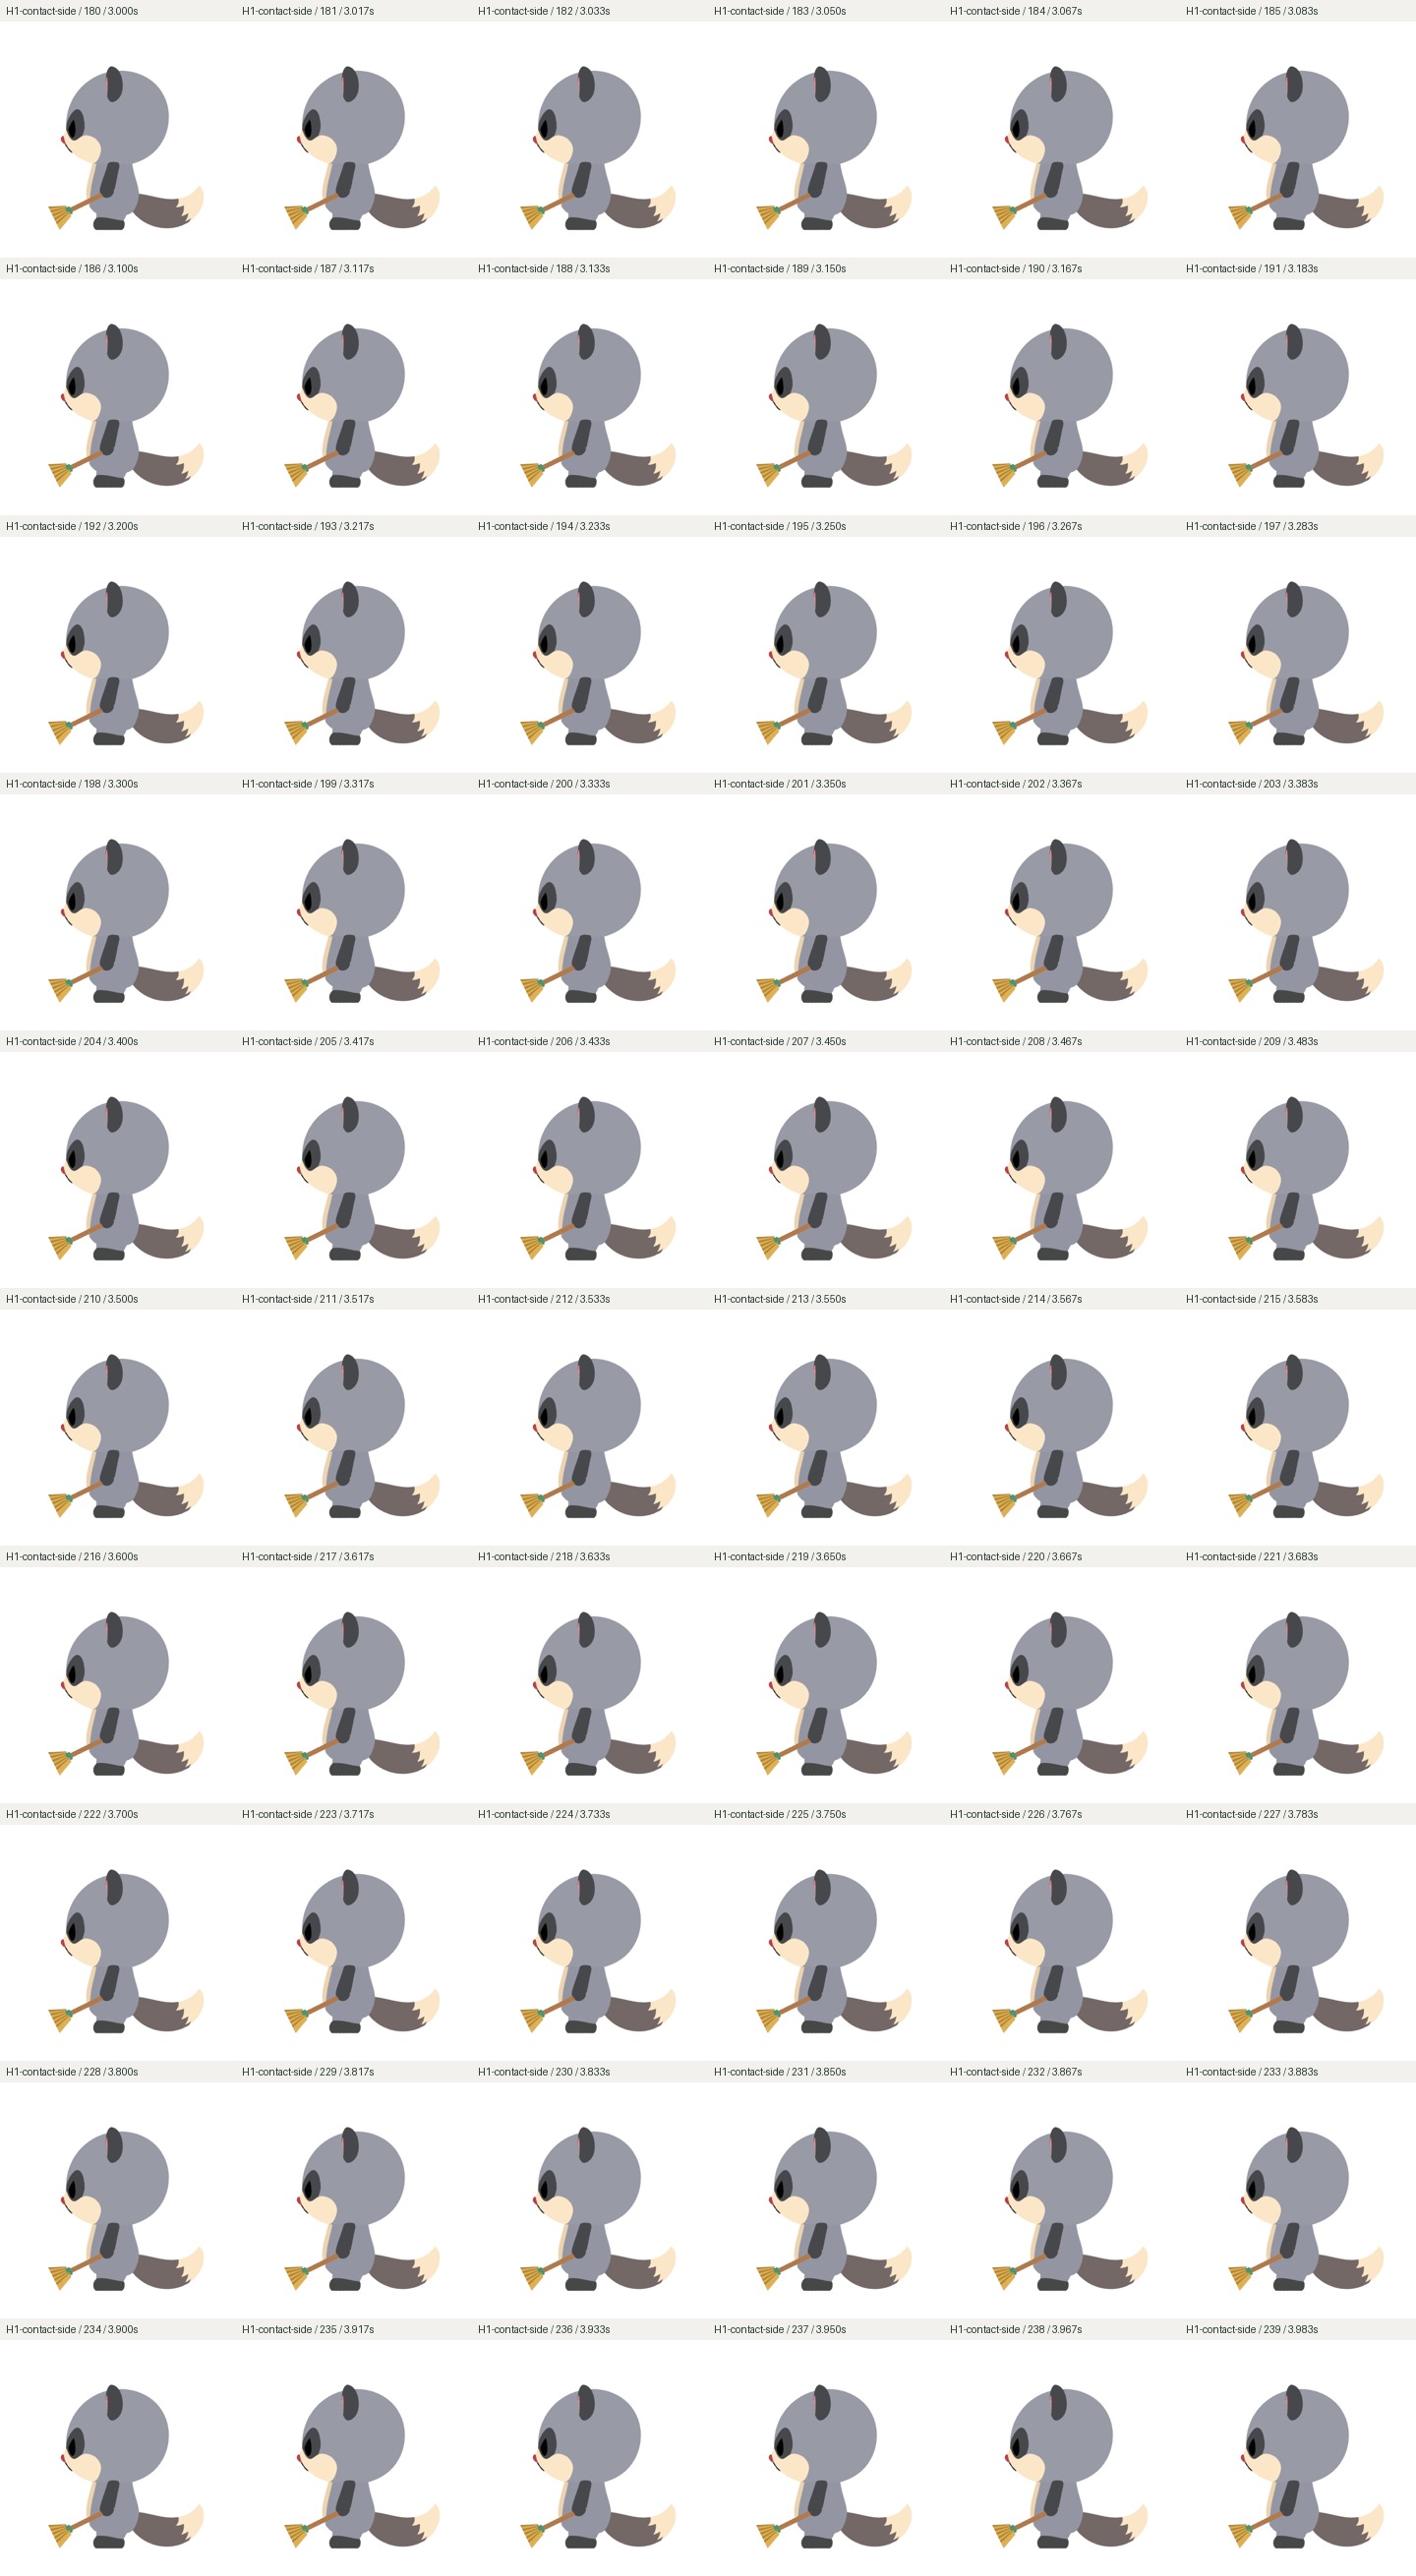 H1-contact · side · frames180–239
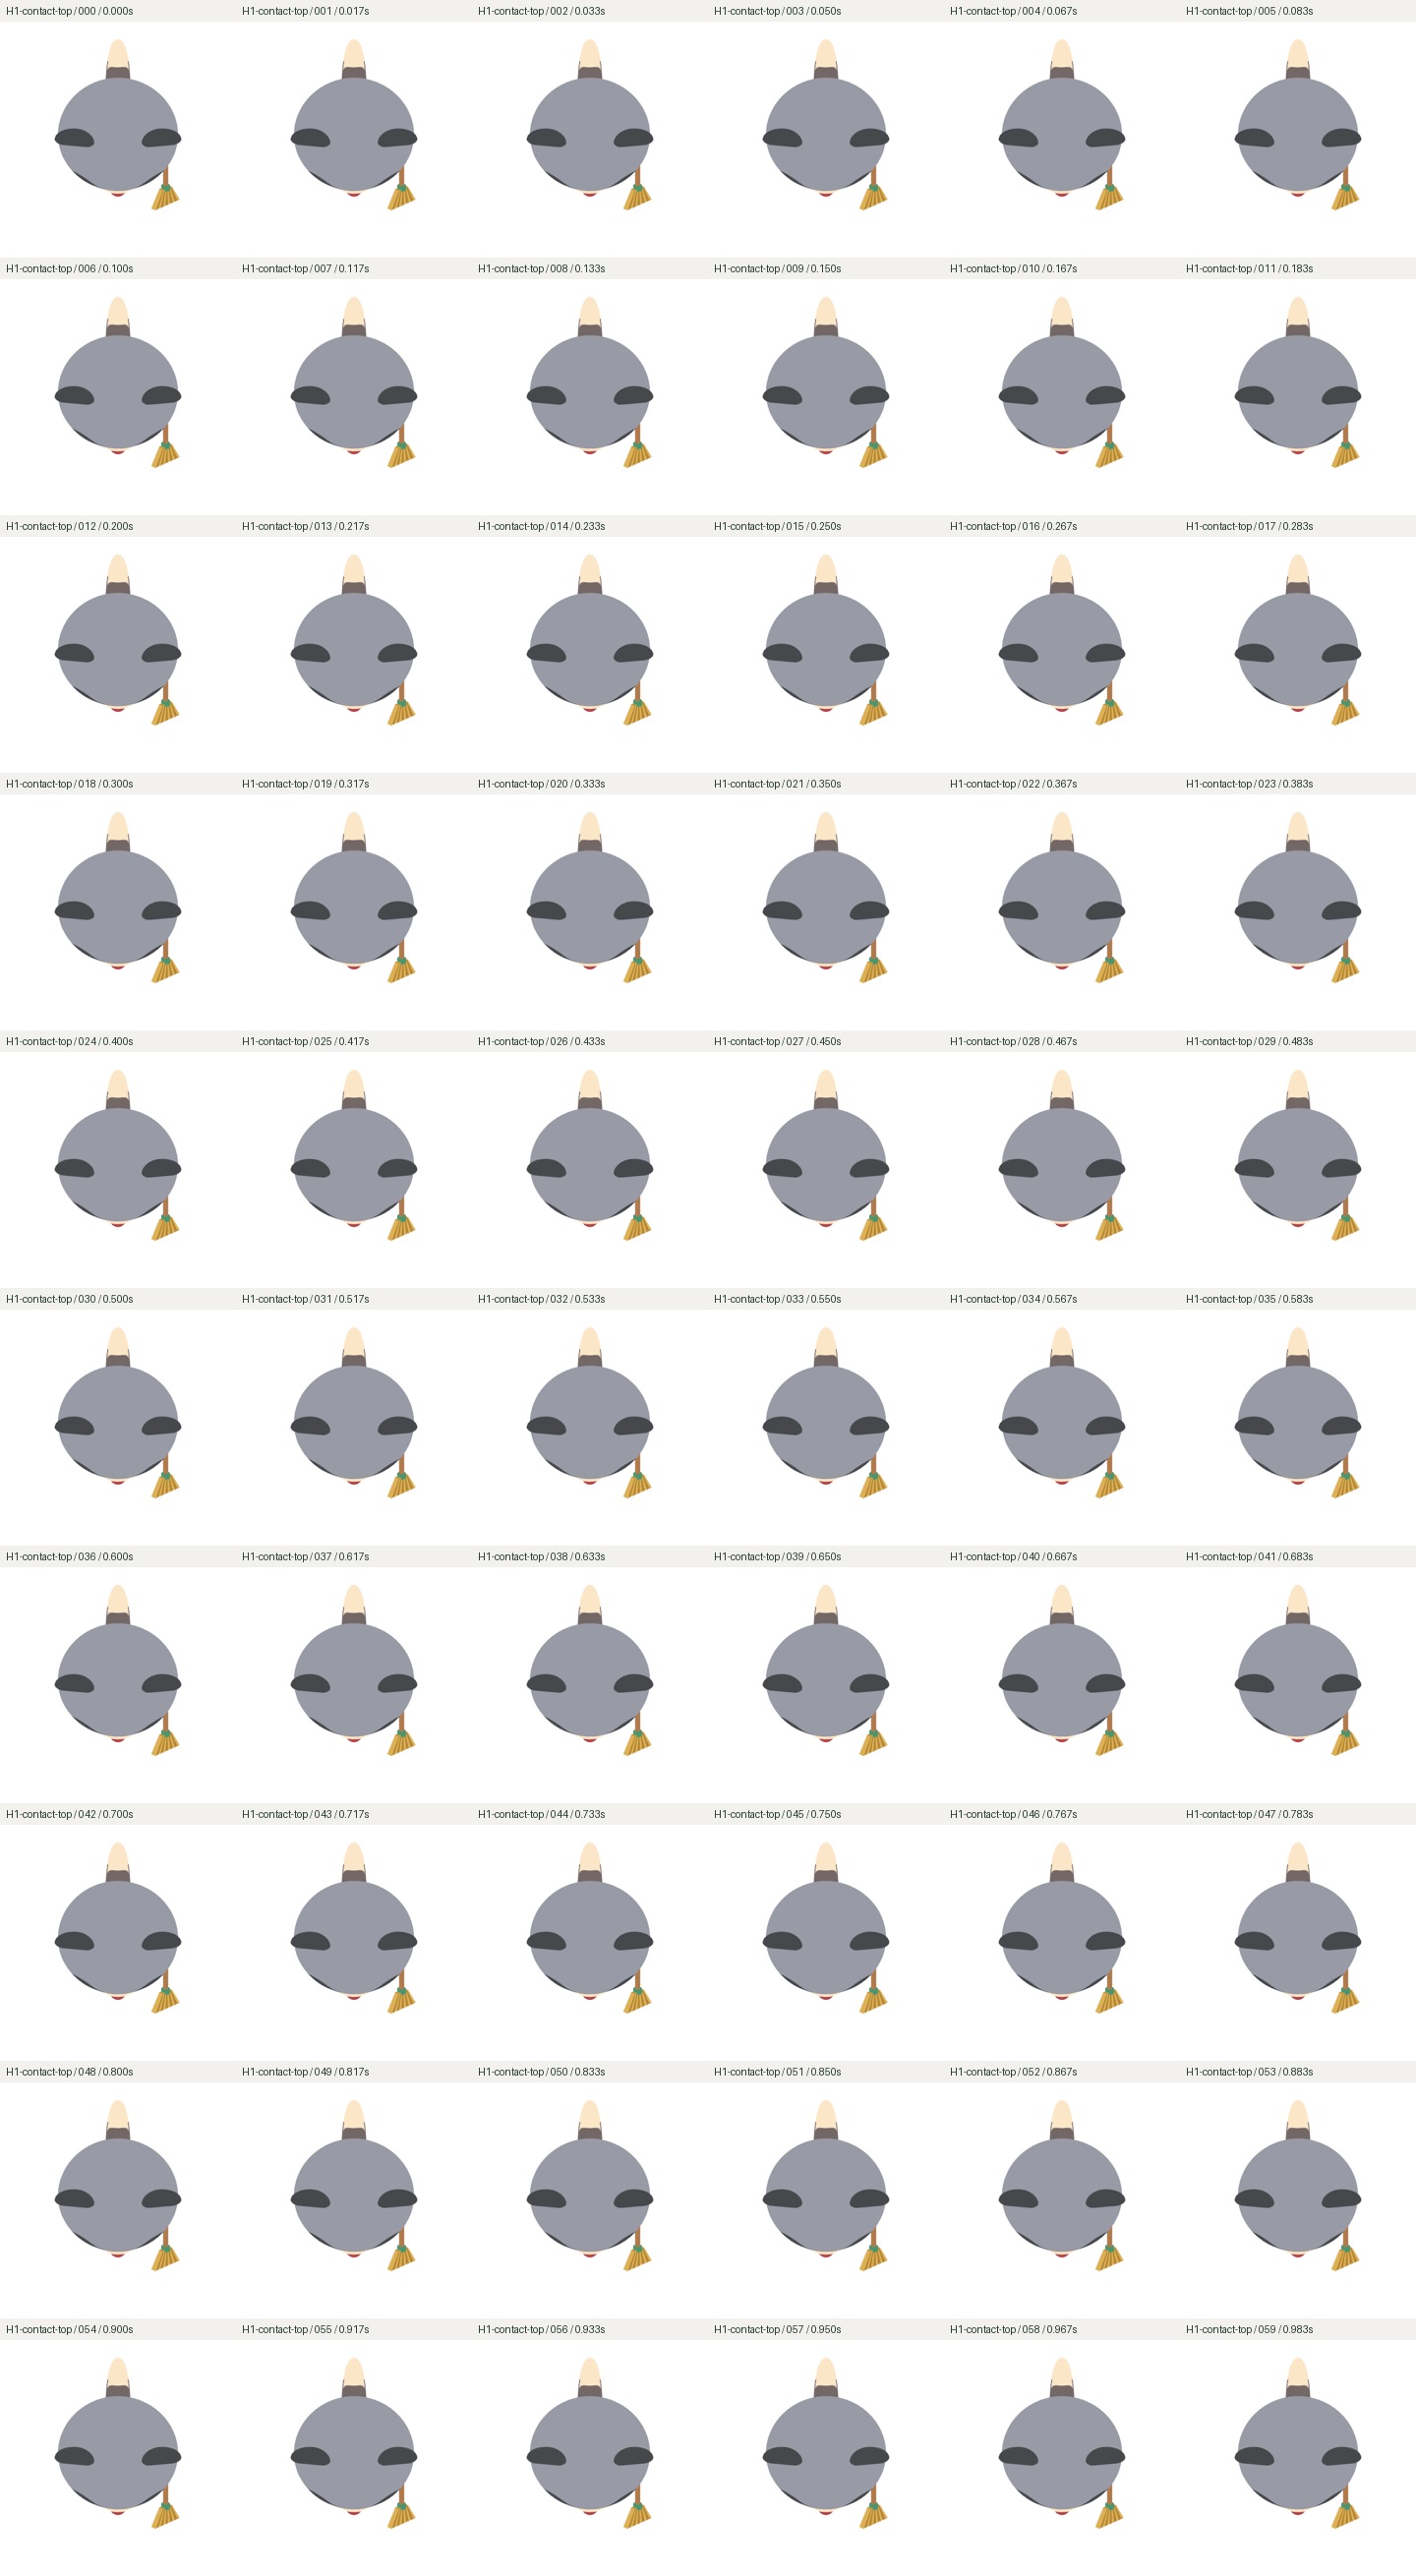 H1-contact · top · frames0–59
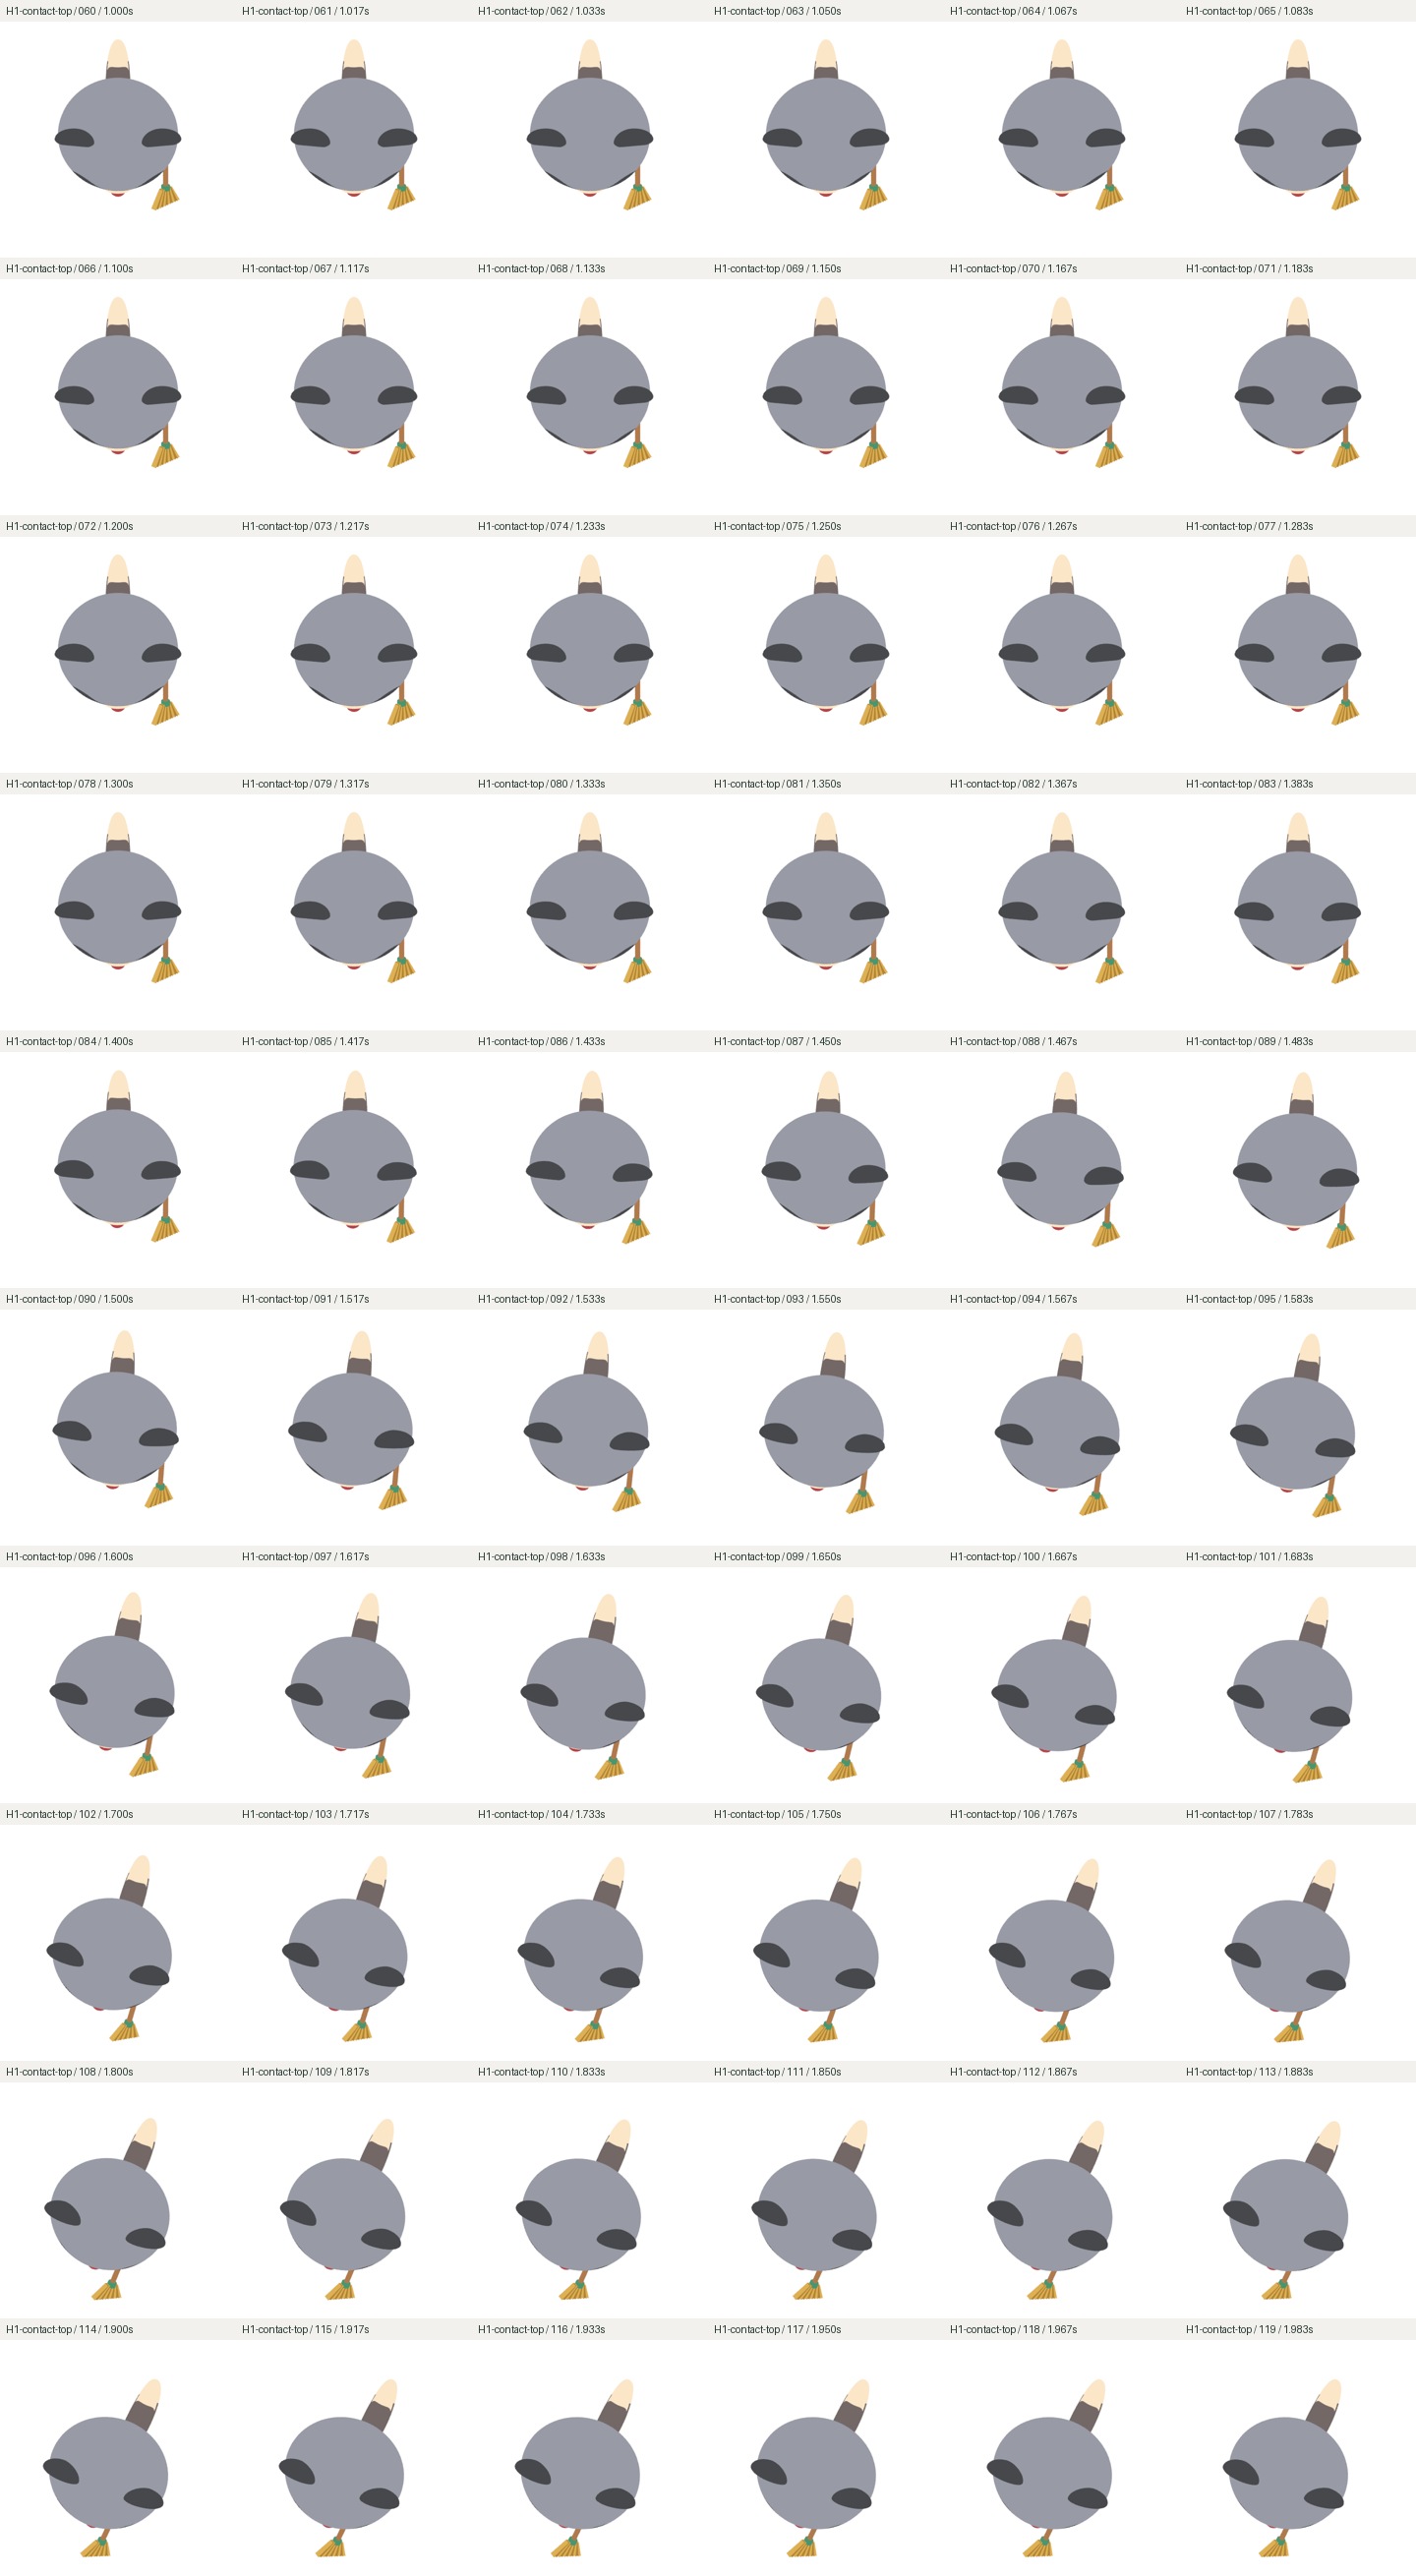 H1-contact · top · frames60–119
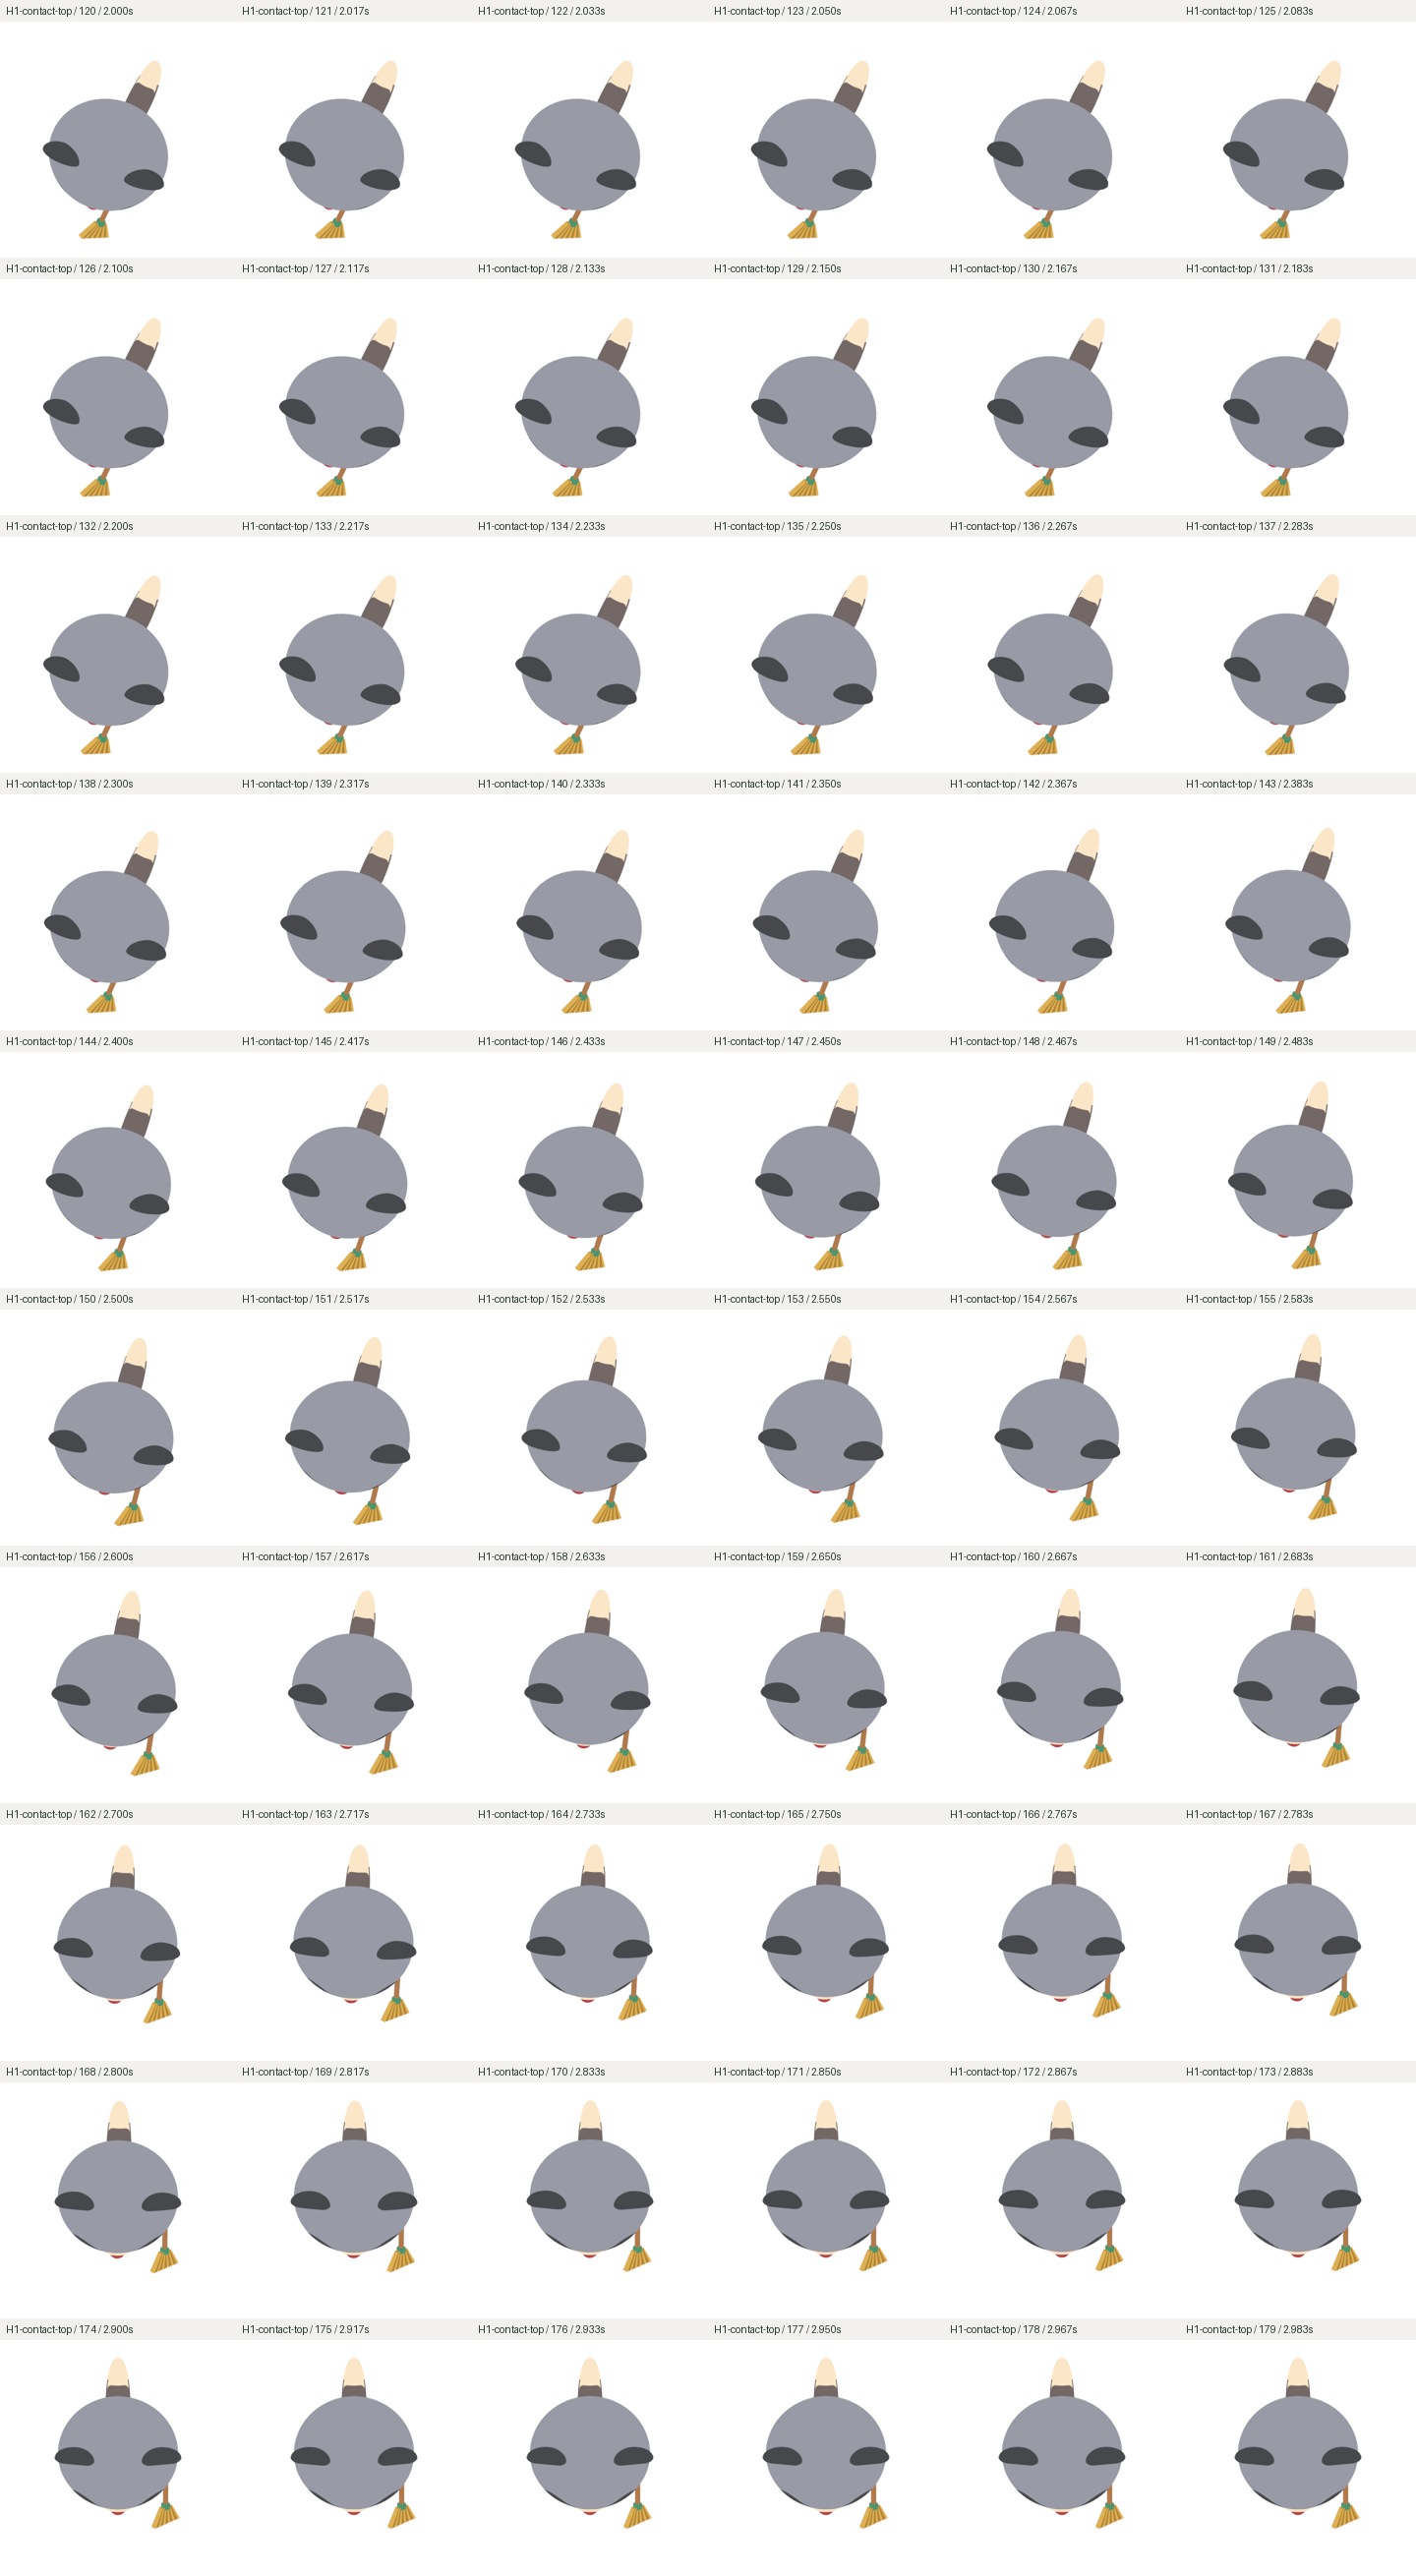 H1-contact · top · frames120–179
 H1-contact · top · frames180–239
Editable native and review evidence
Download editable rig ZIP · 222 MBEditing guideResults and limits · Why the rig changed · Experiment design · Native checks · Capture checks · Media checks · Qualification scope · File hashes